Related Experiment Video
Updated: Jun 12, 2025

An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
Published on: March 10, 2011
Time-optimal open-loop set stabilization of Boolean control networks
Shaoyu Dai1, Bowen Li2, Jianquan Lu3
1Department of Mathematics, Jinling Institute of Technology, Nanjing 211169, China.

Abstract:
We show that for stabilization of Boolean control networks (BCNs) with unobservable initial states, open-loop control and close-loop control are not equivalent. An example is given to illustrate the nonequivalence. Enlightened by the nonequivalence, we explore open-loop set stabilization of BCNs with unobservable initial states. More specifically, this issue is to investigate that for a given BCN, whether there exists a unified free control sequence that is effective for all initial states of the system to stabilize the system states to a given set. The criteria for open-loop set stabilization is derived and for any open-loop set stabilizable BCN, every time-optimal open-loop set stabilizer is proposed. Besides, we obtain the least upper bounds of two integers, which are respectively related to the global stabilization and partial stabilization of BCNs in the results of two literature articles. Using the methods in the two literature articles, the least upper bounds of the two integers cannot be obtained.


Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
 01:10
Control Systems
At the heart...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:13
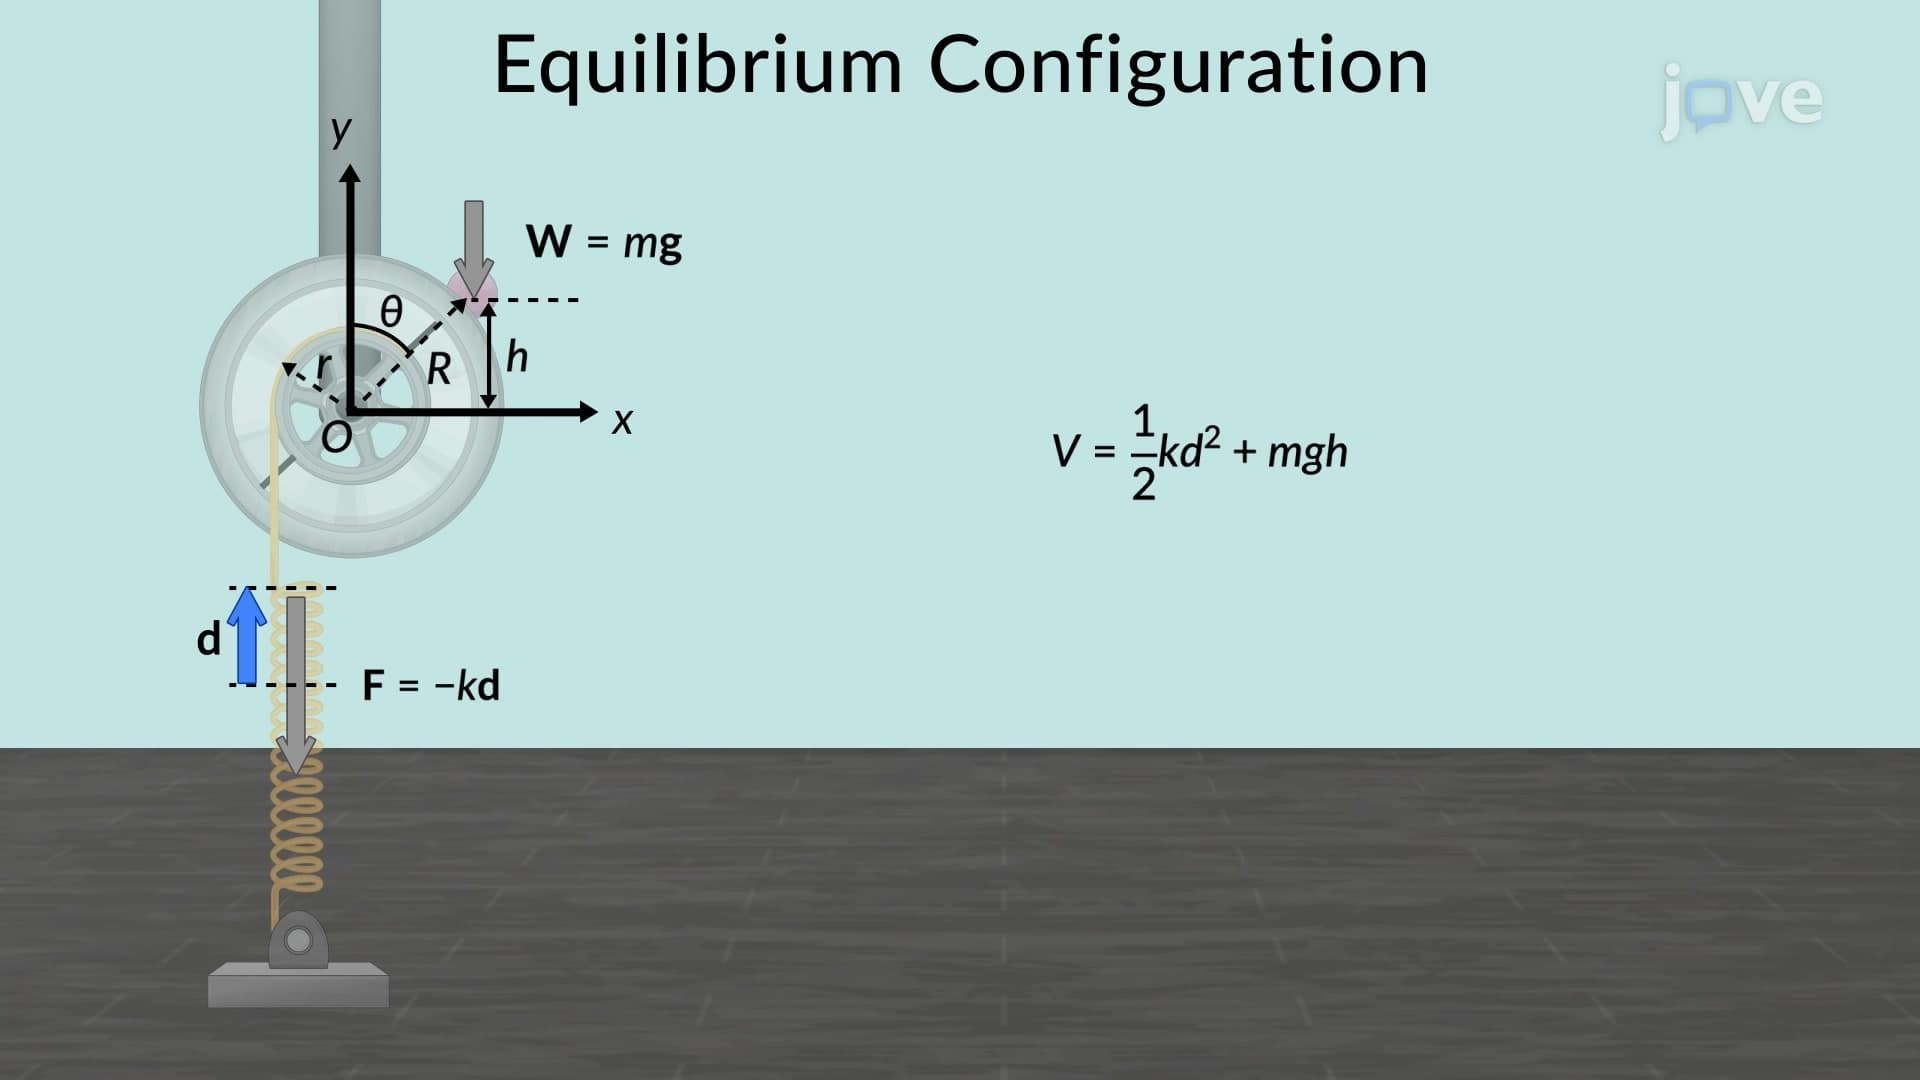
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...