Related Experiment Video
Updated: Jun 11, 2025

Fabrication of Three-Dimensional Graphene-Based Polyhedrons via Origami-Like Self-Folding
Published on: September 23, 2018
Lagrangian approach to origami vertex analysis: kinematics
Matthew Grasinger1, Andrew Gillman1, Philip R Buskohl1
1Air Force Research Laboratory, Wright-Patterson AFB, OH, USA.

Abstract:
The use of origami in engineering has significantly expanded in recent years, spanning deployable structures across scales, folding robotics and mechanical metamaterials. However, finding foldable paths can be a formidable task as the kinematics are determined by a nonlinear system of equations, often with several degrees of freedom. In this article, we leverage a Lagrangian approach to derive reduced-order compatibility conditions for rigid-facet origami vertices with reflection and rotational symmetries. Then, using the reduced-order conditions, we derive exact, multi-degree of freedom solutions for degree 6 and degree 8 vertices with prescribed symmetries. The exact kinematic solutions allow us to efficiently investigate the topology of allowable kinematics, including the consideration of a self-contact constraint, and then visually interpret the role of geometric design parameters on these admissible fold paths by monitoring the change in the kinematic topology. We then introduce a procedure to construct lower-symmetry kinematic solutions by breaking symmetry of higher-order kinematic solutions in a systematic way that preserves compatibility. The multi-degree of freedom solutions discovered here should assist with building intuition of the kinematic feasibility of higher-degree origami vertices and also facilitate the development of new algorithmic procedures for origami-engineering design.This article is part of the theme issue 'Origami/Kirigami-inspired structures: from fundamentals to applications'.
Related Concept Videos
 01:15
Kinematic Equations: Problem Solving
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:15
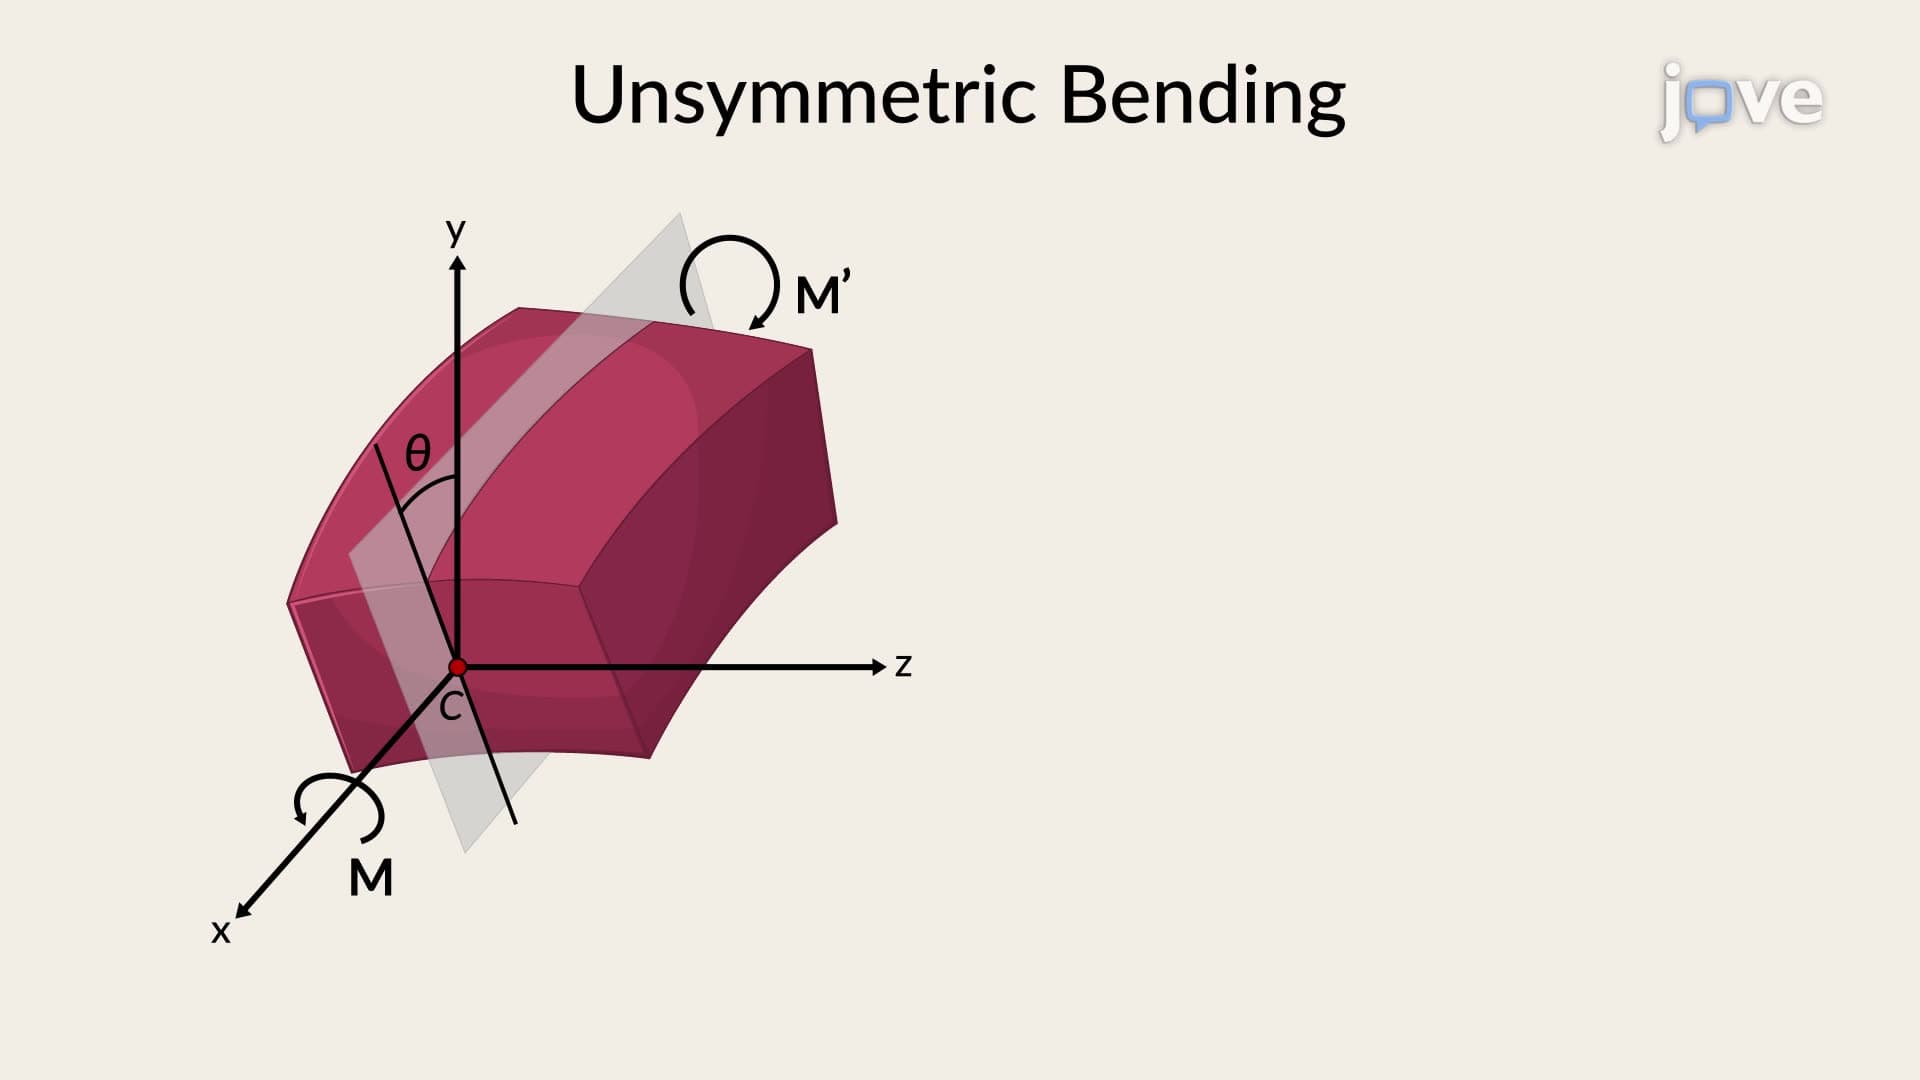
Unsymmetric Bending - Angle of Neutral Axis
When a bending moment is applied at an angle θ concerning the vertical axis of a symmetrical member, it can be resolved into components along the member's principal...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:22
Equation of Motion: General Plane motion
Moreover, the body's center of mass experiences a rotational effect as a result of these couple moments. This rotation can be articulated as the...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...