Related Experiment Video
Updated: Jun 10, 2025


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
UKF-Based Optimal Tracking Control for Uncertain Dynamic Systems With Asymmetric Input Constraints

Abstract:
To enhance system robustness in the face of uncertainty and achieve adaptive optimization of control strategies, a novel algorithm based on the unscented Kalman filter (UKF) is developed. This algorithm addresses the finite-horizon optimal tracking control problem (FHOTCP) for nonlinear discrete-time (DT) systems with uncertainty and asymmetric input constraints. An augmented system is constructed with asymmetric control constraints being considered. The augmented problem is addressed with a DT Hamilton-Jacobi-Bellman equation (DTHJBE). By analyzing convergence with regard to the cost function and control law, the UKF-based iterative adaptive dynamic programming (ADP) algorithm is proposed. This algorithm approximates the solution of the DTHJBE, ensuring that the cost function converges to its optimal value within a bounded range. To execute the UKF-based iterative ADP algorithm, the actor-estimator-critic framework is built, in which the estimator refers to system state estimation through the application of UKF. Ultimately, simulation examples are presented to show the performance of the proposed method.


Related Concept Videos
 01:10
Control Systems
At the heart...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:21
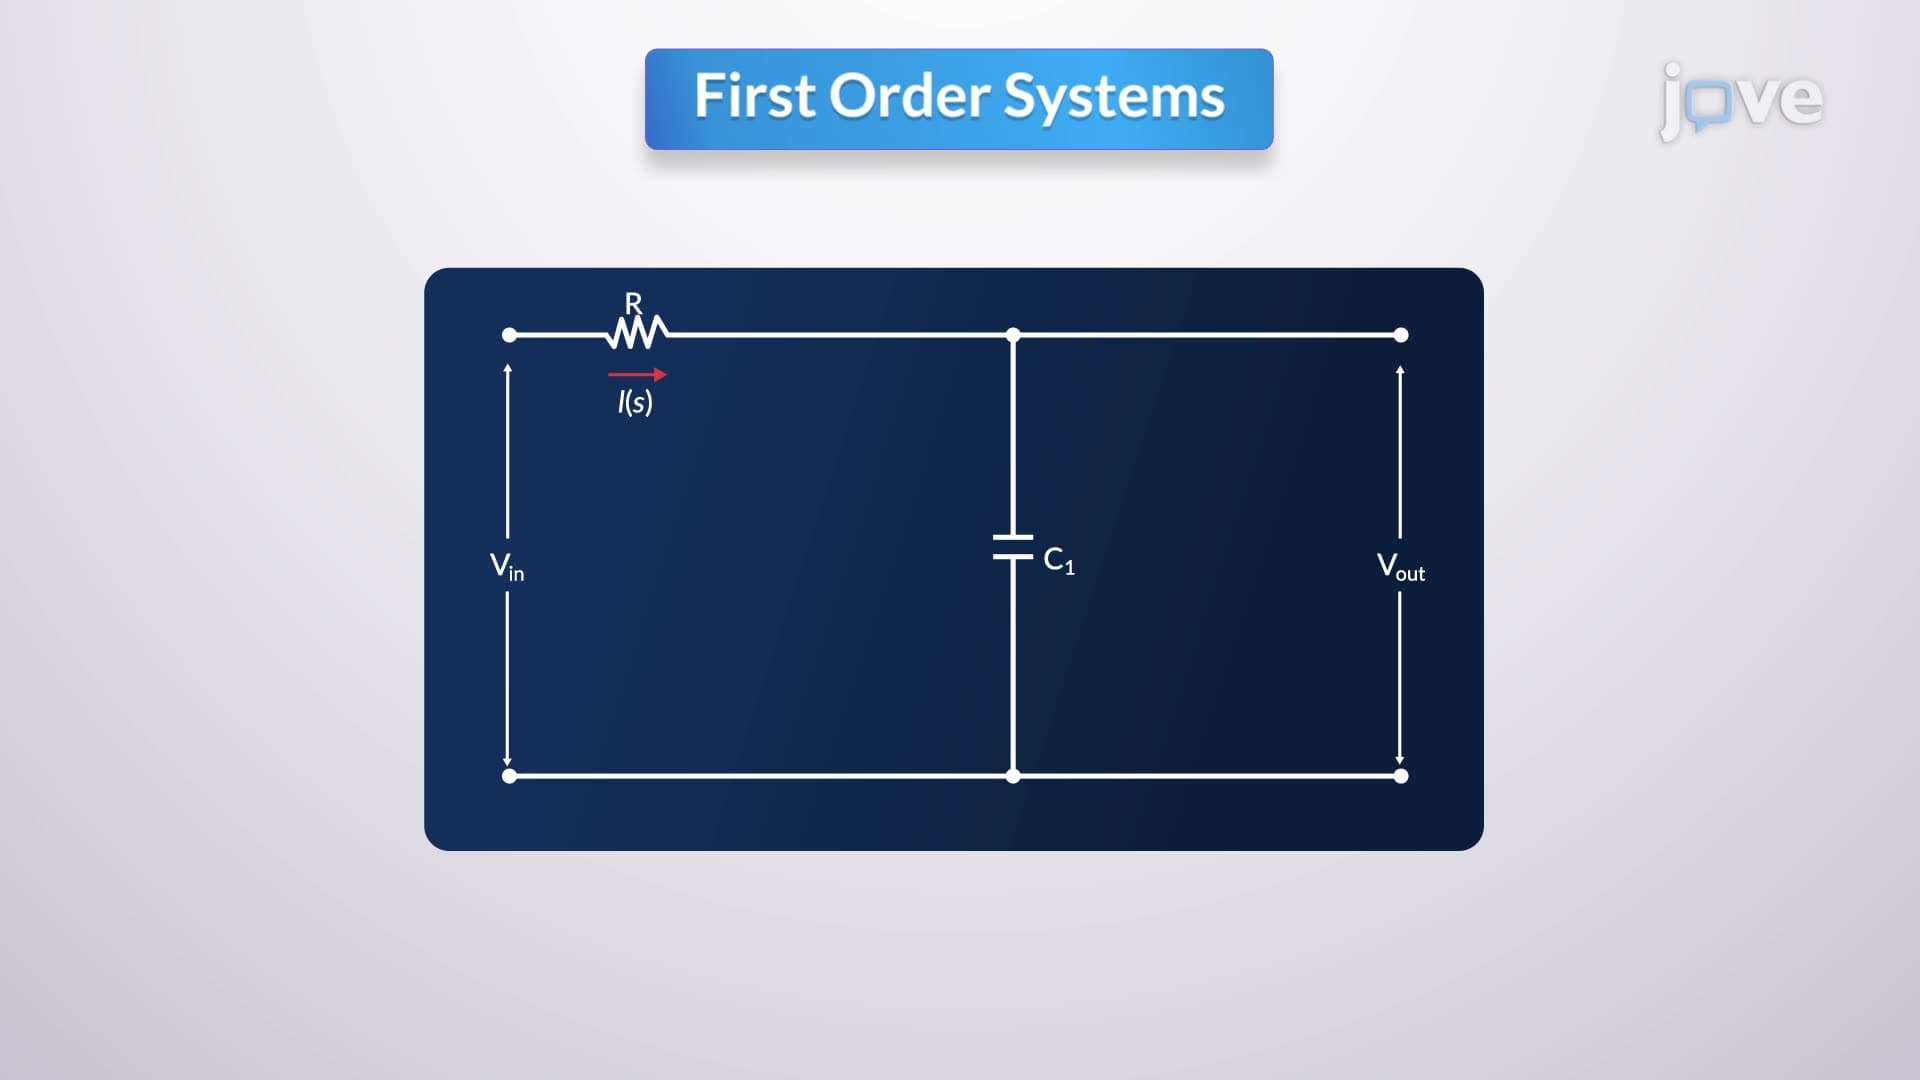
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:22
Multi-input and Multi-variable systems
In the absence...