Related Experiment Video
Updated: Jun 10, 2025
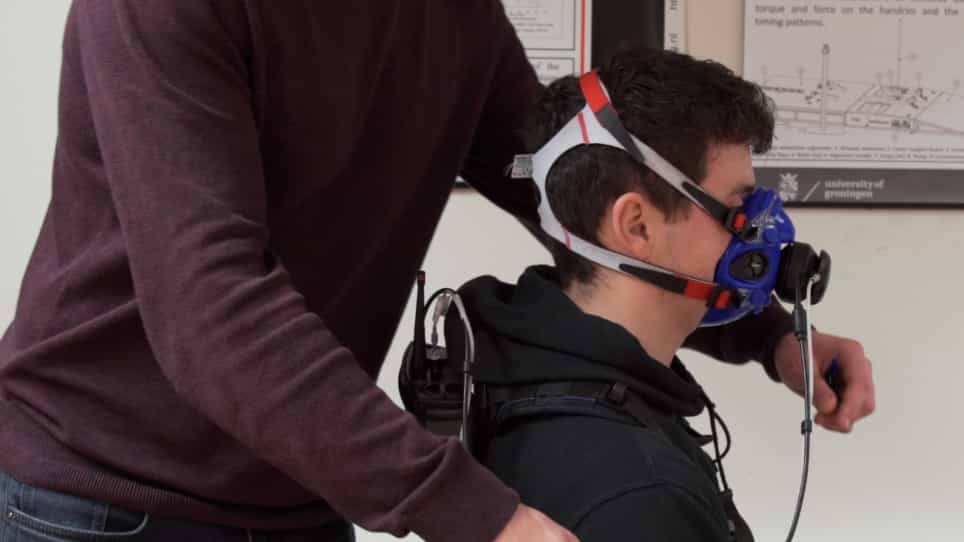

Determining and Controlling External Power Output During Regular Handrim Wheelchair Propulsion
Published on: February 5, 2020
Handrim Reaction Force and Moment Assessment Using a Minimal IMU Configuration and Non-Linear Modeling Approach
Rachid Aissaoui1,2,3,4, Amaury De Lutiis1,2, Aiman Feghoul1,2
1Laboratoire de Recherche en Innovation Ouverte en Technologie de la Santé, Centre de Recherche CRCHUM, Montreal, QC H2X 0A9, Canada.

Abstract:
Manual wheelchair propulsion represents a repetitive and constraining task, which leads mainly to the development of joint injury in spinal cord-injured people. One of the main reasons is the load sustained by the shoulder joint during the propulsion cycle. Moreover, the load at the shoulder joint is highly correlated with the force and moment acting at the handrim level. The main objective of this study is related to the estimation of handrim reactions forces and moments during wheelchair propulsion using only a single inertial measurement unit per hand. Two approaches are proposed here: Firstly, a method of identification of a non-linear transfer function based on the Hammerstein-Wiener (HW) modeling approach was used. The latter represents a typical multi-input single output in a system engineering modeling approach. Secondly, a specific variant of recurrent neural network called BiLSTM is proposed to predict the time-series data of force and moments at the handrim level. Eleven subjects participated in this study in a linear propulsion protocol, while the forces and moments were measured by a dynamic platform. The two input signals were the linear acceleration as well the angular velocity of the wrist joint. The horizontal, vertical and sagittal moments were estimated by the two approaches. The mean average error (MAE) shows a value of 6.10 N and 4.30 N for the horizontal force for BiLSTM and HW, respectively. The results for the vertical direction show a MAE of 5.91 N and 7.59 N for BiLSTM and HW, respectively. Finally, the MAE for the sagittal moment varies from 0.96 Nm (BiLSTM) to 1.09 Nm for the HW model. The approaches seem similar with respect to the MAE and can be considered accurate knowing that the order of magnitude of the uncertainties of the dynamic platform was reported to be 2.2 N for the horizontal and vertical forces and 2.24 Nm for the sagittal moments. However, it should be noted that HW necessitates the knowledge of the average force and patterns of each subject, whereas the BiLSTM method do not involve the average patterns, which shows its superiority for time-series data prediction. The results provided in this study show the possibility of measuring dynamic forces acting at the handrim level during wheelchair manual propulsion in ecological environments.
More Related Videos
 08:08
Oscillation and Reaction Board Techniques for Estimating Inertial Properties of a Below-knee Prosthesis
Published on: May 8, 2014
 11:06
A Human-machine-interface Integrating Low-cost Sensors with a Neuromuscular Electrical Stimulation System for Post-stroke Balance Rehabilitation
Published on: April 12, 2016
Related Concept Videos
 01:17
Rolling Resistance: Problem Solving
 01:23
Simplification of a Force and Couple System: II
 01:27
Support Reactions in Three Dimensions
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
 01:16
Equation of Motion: General Plane motion - Problem Solving
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
 01:24
Normal and Tangetial Components: Problem Solving