Related Experiment Video
Updated: Jun 9, 2025


Design and Analysis for Fall Detection System Simplification
Published on: April 6, 2020
Asynchronous Control for Interval Type-2 Fuzzy Nonhomogeneous Markov Jump Systems Against Successive DoS Attacks

Abstract:
This article is concerned with the problem of asynchronous control for Interval Type-2 (IT2) fuzzy nonhomogeneous Markov jump systems against successive denial-of-service (DoS) attacks. The system and the controller are assumed to be connected through a communication channel subject to malicious attacks. The maximum number and probability distribution of successive attacks are considered. Under the imperfect premise matching, a fuzzy asynchronous controller is constructed by the hidden Markov model. By means of the introduced transmission delay, a delay closed-loop system is constructed, where the stochastic description of the delay depends on the statistical characteristic of successive attacks. Then stability criteria together are derived in the form of linear matrix inequalities by the Lyapunov functional approach, as well as the condition on the existence of the fuzzy controller. Finally, the feasibility and effectiveness of the presented control scheme are demonstrated by simulation results.
Related Concept Videos
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:21
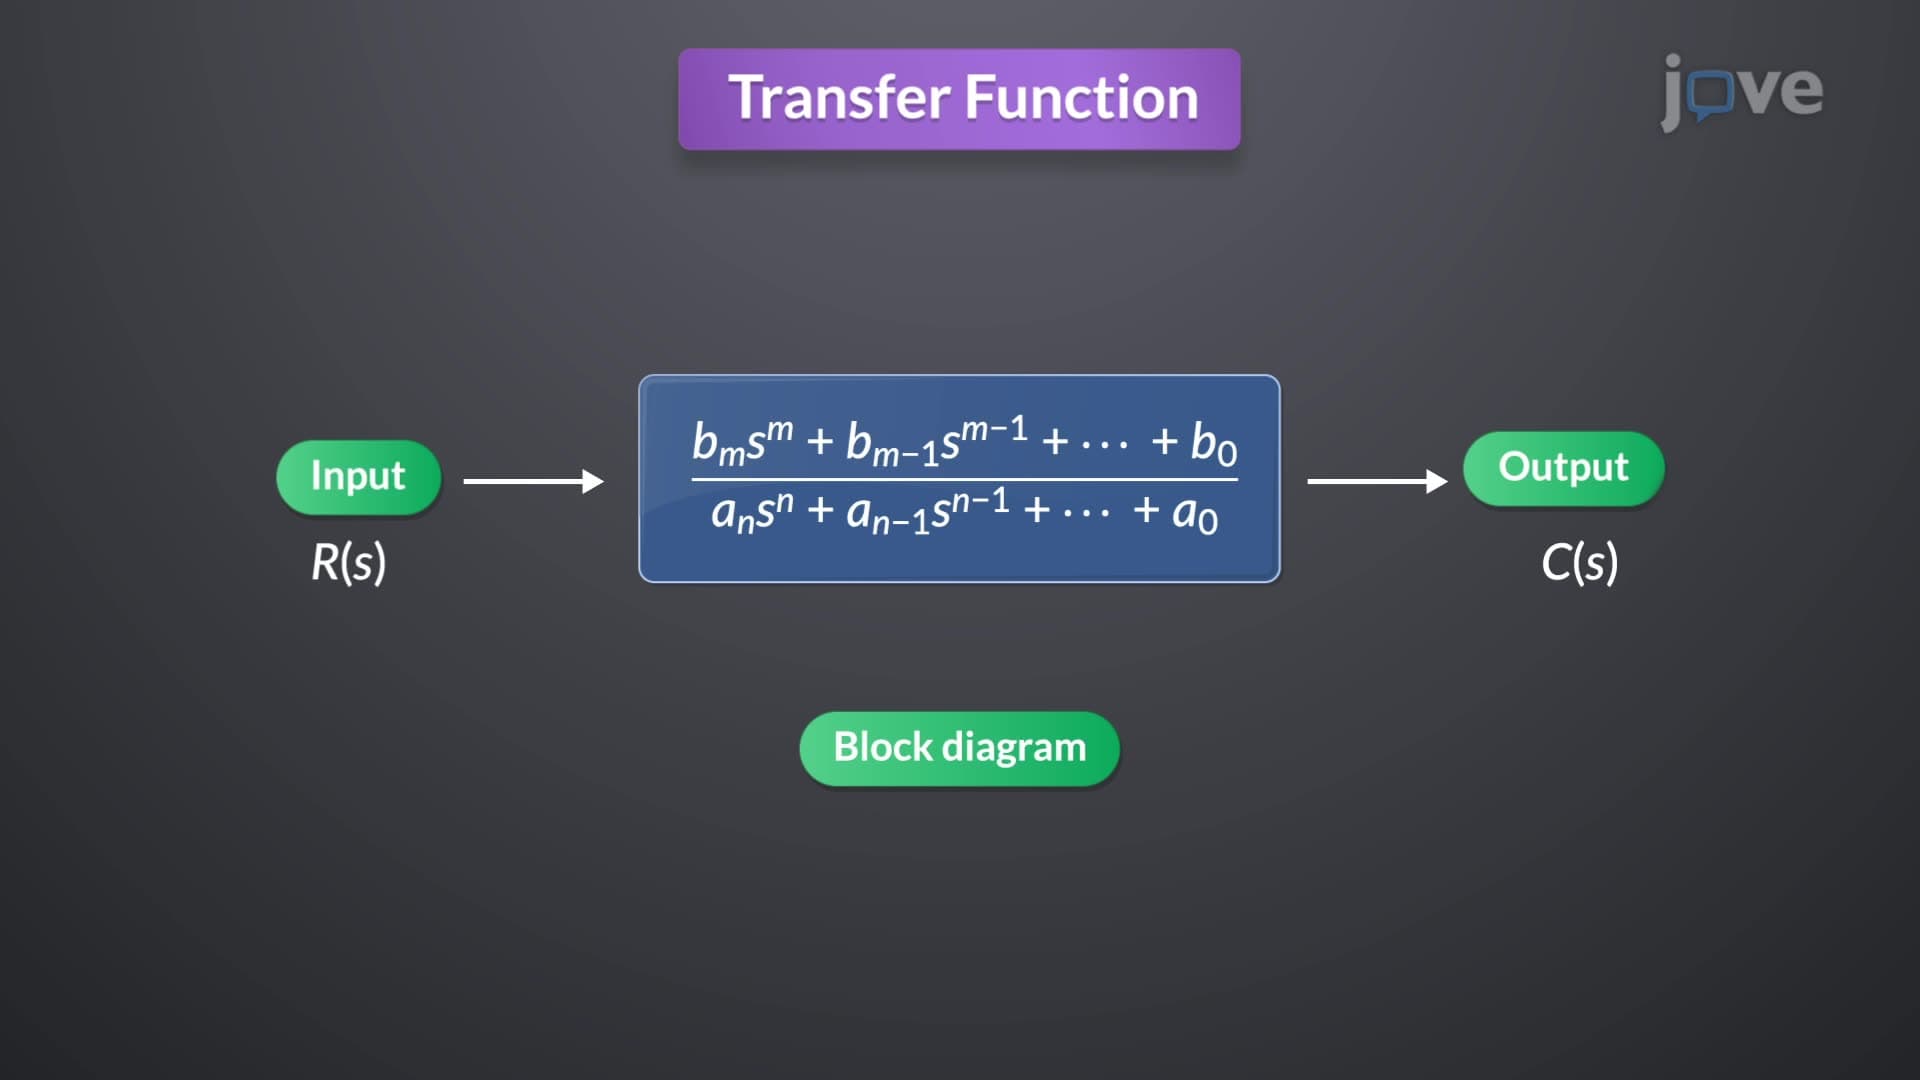
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...