Related Experiment Video
Updated: Jun 9, 2025
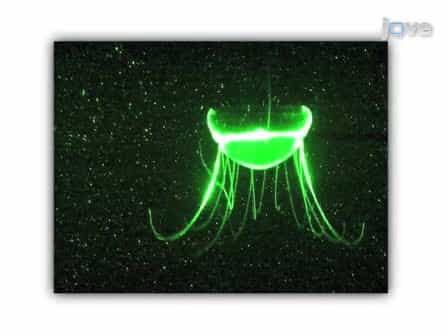

Quantitatively Measuring In situ Flows using a Self-Contained Underwater Velocimetry Apparatus SCUVA
Published on: October 31, 2011
Study on the Robust Filter Method of SINS/DVL Integrated Navigation Systems in a Complex Underwater Environment
Tianlong Zhu1, Jian Li1, Kun Duan1
1College of Information Science and Engineering, Hohai University, Changzhou 213001, China.

Abstract:
This paper proposes an improved adaptive filtering algorithm based on the Sage-Husa adaptive Kalman filtering algorithm to address the issue of measurement noise characteristics impacting the navigation accuracy in strapdown inertial navigation system (SINS)/Doppler Velocity Log (DVL) integrated navigation systems. Addressing the non-positive definite matrix problem prevalent in traditional adaptive filtering algorithms and aiming to enhance measurement noise estimation accuracy, this method incorporates upper and lower thresholds determined by a discrimination factor. In the presence of abnormal measurement data, these thresholds are utilized to adjust the covariance of the innovation, subsequently re-estimating the system's measurement noise through a decision factor based on the innovation. Simulation and experiment results demonstrate that the proposed improved adaptive filtering algorithm outperforms the classical Kalman filter (KF) in terms of navigation accuracy and stability. Furthermore, the filtering performance surpasses that of the Sage-Husa algorithm. The simulation results in this paper show that the relative position positioning error of the improved method is reduced by 49.44% compared with the Sage-Husa filtering method.
More Related Videos
 09:32
Development of New Methods for Quantifying Fish Density Using Underwater Stereo-video Tools
Published on: November 20, 2017
 07:43
Methods for Image-based Surveys of Benthic Macroinvertebrates and Their Habitat Exemplified by the Drop Camera Survey for the Atlantic Sea Scallop
Published on: July 2, 2018
