Related Experiment Video
Updated: Jun 7, 2025


Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023
MPCTrans: Multi-Perspective Cue-Aware Joint Relationship Representation for 3D Hand Pose Estimation via Swin
Xiangan Wan1, Jianping Ju1, Jianying Tang1
1School of Computer Science and Technology, Hubei Business College, Wuhan 430079, China.

Abstract:
The objective of 3D hand pose estimation (HPE) based on depth images is to accurately locate and predict keypoints of the hand. However, this task remains challenging because of the variations in hand appearance from different viewpoints and severe occlusions. To effectively address these challenges, this study introduces a novel approach, called the multi-perspective cue-aware joint relationship representation for 3D HPE via the Swin Transformer (MPCTrans, for short). This approach is designed to learn multi-perspective cues and essential information from hand depth images. To achieve this goal, three novel modules are proposed to utilize features from multiple virtual views of the hand, namely, the adaptive virtual multi-viewpoint (AVM), hierarchy feature estimation (HFE), and virtual viewpoint evaluation (VVE) modules. The AVM module adaptively adjusts the angles of the virtual viewpoint and learns the ideal virtual viewpoint to generate informative multiple virtual views. The HFE module estimates hand keypoints through hierarchical feature extraction. The VVE module evaluates virtual viewpoints by using chained high-level functions from the HFE module. Transformer is used as a backbone to extract the long-range semantic joint relationships in hand depth images. Extensive experiments demonstrate that the MPCTrans model achieves state-of-the-art performance on four challenging benchmark datasets.
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:20
Structural Classification of Joints
A fibrous joint is where the adjacent bones are united by fibrous connective...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:09
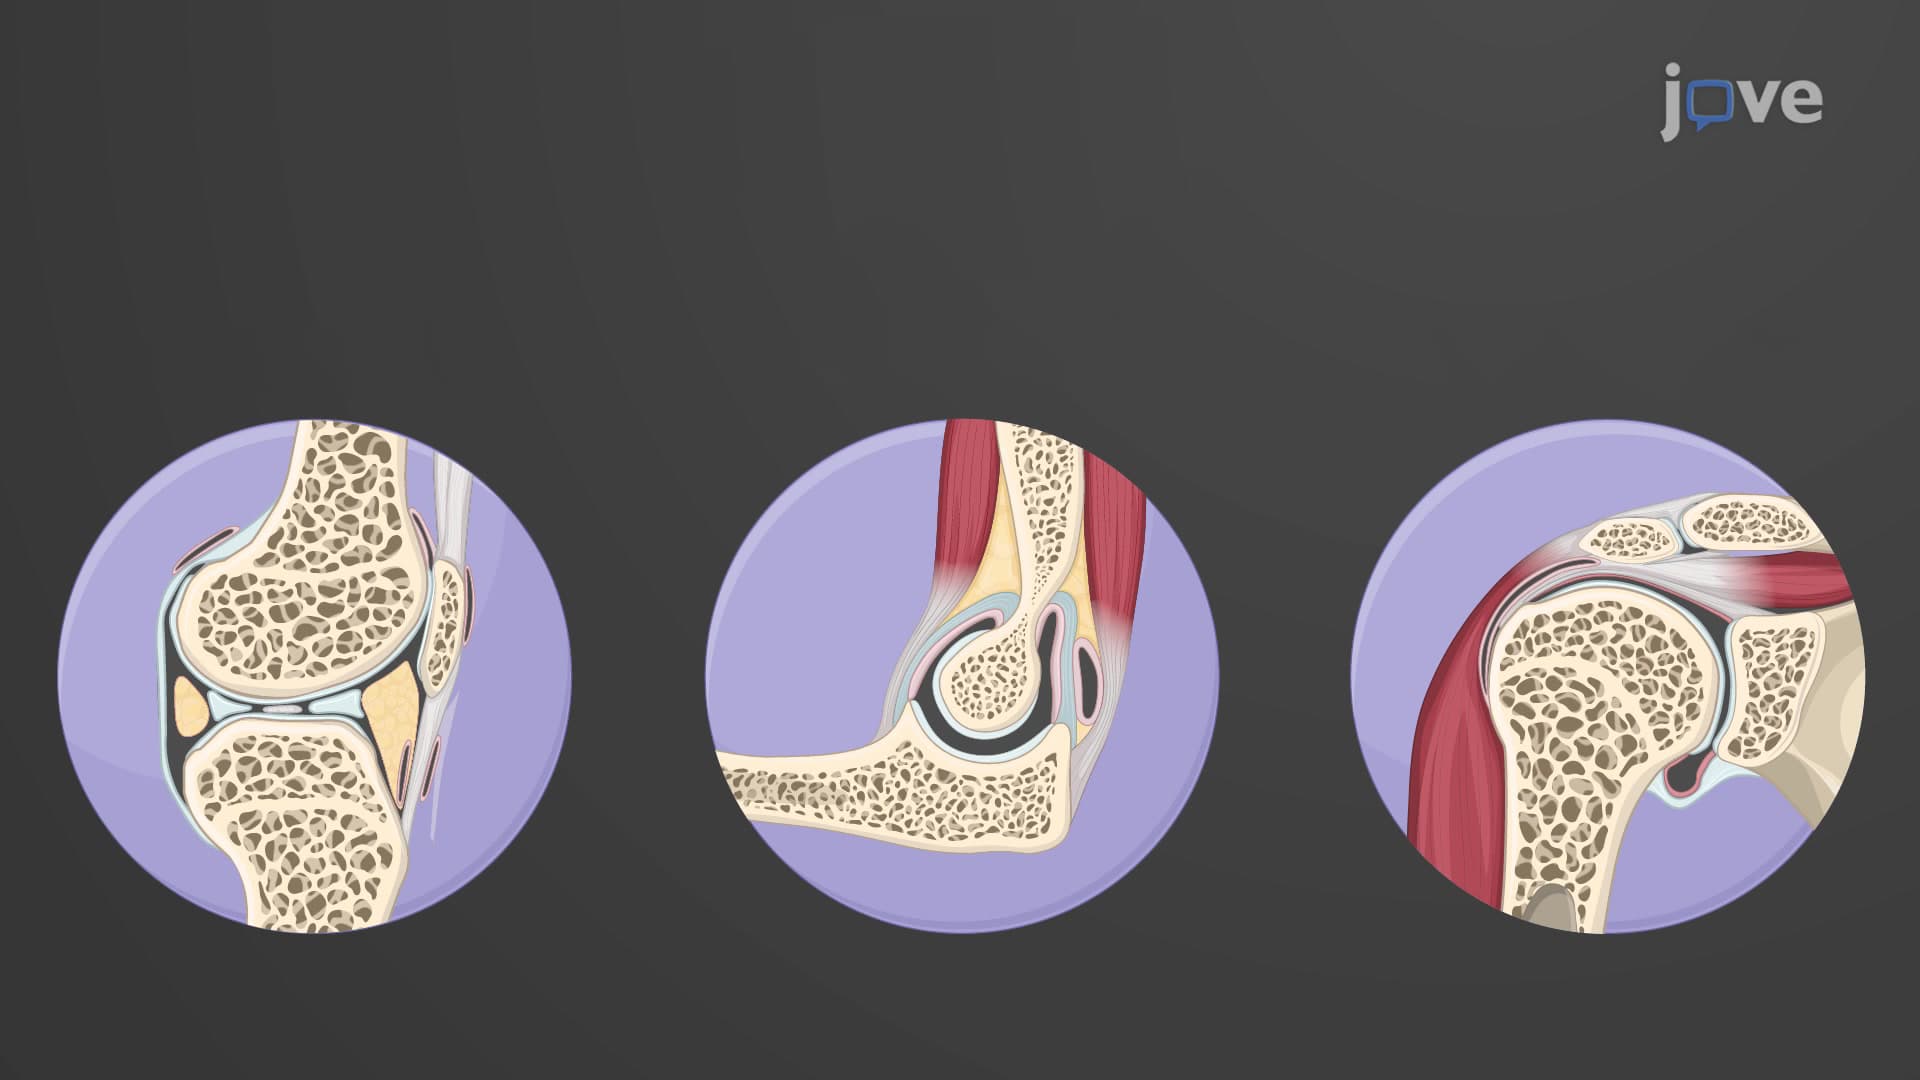
Functional Classification of Joints
The functional classification of joints is determined by the amount of mobility between the adjacent bones. Joints are functionally classified as a synarthrosis or immobile joint, an amphiarthrosis or slightly moveable joint, or as a diarthrosis, a freely moveable joint. Fibrous and cartilaginous joints can be functionally classified as either synarthroses or amphiarthroses, whereas all synovial joints are classified as diarthroses.
Synarthrosis
An...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...