Related Experiment Video
Updated: Jun 6, 2025

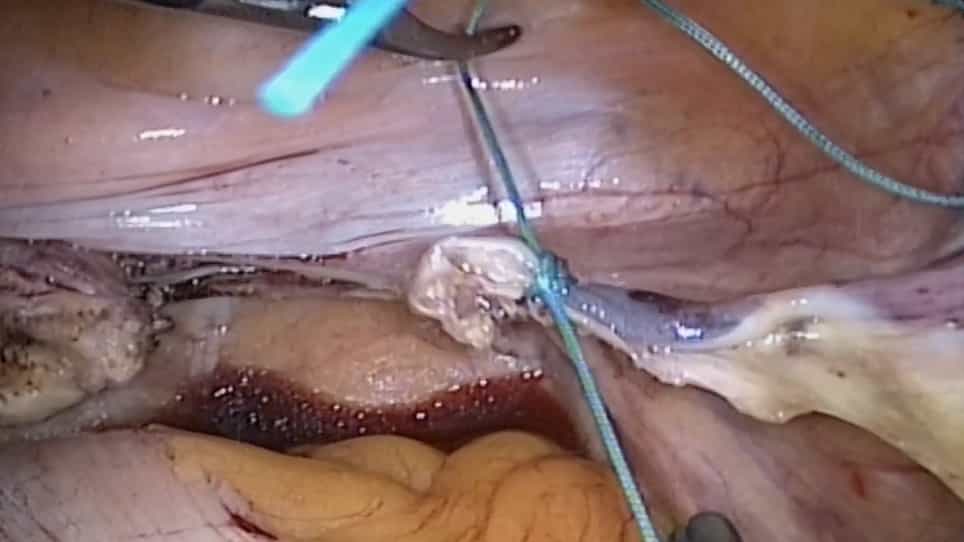
Transvaginal Mesh Insertion in the Ovine Model
Published on: July 27, 2017
Innovative vaginal manipulator technique vs. traditional method for vaginal fornix deployment in robotic
Yoshiaki Ota1, Kuniaki Ota1,2, Toshifumi Takahashi2
1Department of Obstetrics and Gynecology, Kawasaki Medical School, Okayama, Japan.

Introduction And Hypothesis:
Pelvic organ prolapse (POP) affects approximately 30% of middle-aged and older women, with 11%-19% requiring surgical intervention. Laparoscopic sacrocolpopexy preserves the vaginal axis and length but involves a steep learning curve and longer operation times. Robotic sacrocolpopexy (RSC) addresses these issues, offering enhanced surgical precision. This study aimed to evaluate the feasibility and effectiveness of a novel vaginal manipulator (Hoyte Sacro Tip®; Cooper Surgical, Trumbull, CT, USA) compared with the traditional spatula in RSC.
Methods:
This retrospective cohort study included 88 females undergoing RSC at Kawasaki Medical School Hospital between January 2021 and December 2023. Patients were divided into two groups: spatula (n = 50) and vaginal manipulator (n = 38). Data on patient demographics, operative outcomes, and postoperative POP quantification (POP-Q) scores were collected.
Results:
Baseline characteristics were similar between the groups, except for gravidity and hypertension, which were higher in the spatula group than that in the vaginal manipulator group. No significant differences were found in operative time, console time, estimated blood loss, or complication rates between the groups (p = 0.08, 0.12, 0.19, and NA, respectively). Hospital stays were shorter in the vaginal manipulator group (median 6.5 vs. 7.0 days, p = 0.03) than in the spatula group. Both groups showed improved POP-Q scores postoperatively. However, the vaginal manipulator group had significantly lower ΔC scores than that of the spatula group (6.26 ± 3.88 vs. 8.53 ± 3.25, p = 0.02).
Conclusions:
The vaginal manipulator proved to be a safe and feasible alternative to the traditional spatula, with comparable perioperative outcomes and shorter hospital stays. The manipulator's design facilitated better tissue dissection, potentially improving surgical efficiency.