Related Experiment Video
Updated: Jun 29, 2026

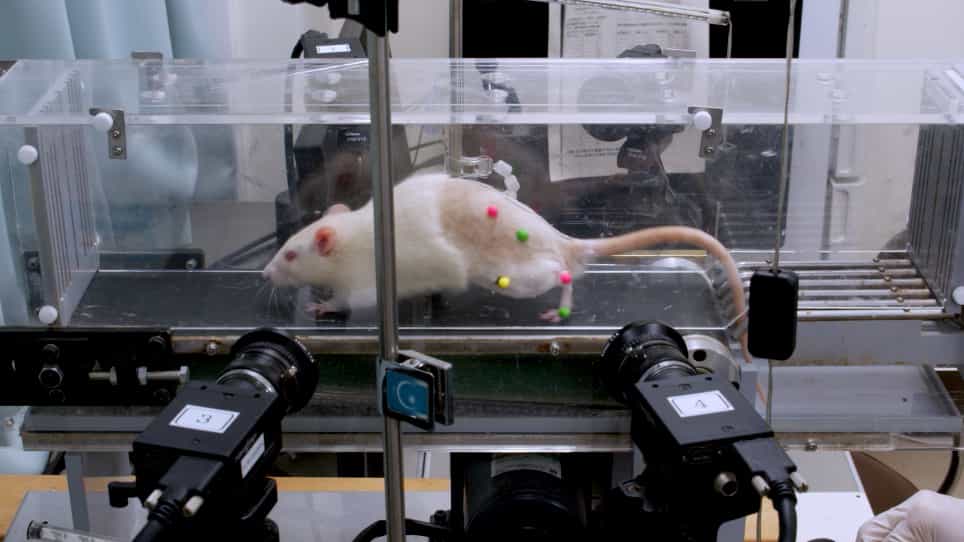
3D Kinematic Gait Analysis for Preclinical Studies in Rodents
Published on: August 3, 2019
Simultaneous Localization and Mapping Methods for Snake-like Robots Based on Gait Adjustment
Chaoquan Tang1, Zhipeng Zhang1, Meng Sun1
1Jiangsu Key Laboratory of Mine Mechanical and Electrical Equipment, School of Mechatronic Engineering, China University of Mining and Technology, Xuzhou 221116, China.

Abstract:
Snake robots require autonomous localization and mapping capabilities for field applications. However, the characteristics of their motion, such as large turning angles and fast rotation speeds, can lead to issues like drift or even failure in positioning and map building. In response to this situation, this paper starts from the gait motion characteristics of the snake robot itself, proposing an improved gait motion method and a tightly coupled method based on IMU and visual information to solve the problem of poor algorithm convergence caused by head-shaking in snake robot SLAM. Firstly, the adaptability of several typical gaits of the snake robot to SLAM methods was evaluated. Secondly, the serpentine gait was selected as the object of gait improvement, and a head stability control method for the snake robot was proposed, thereby reducing the interference of the snake robot's motion on the sensors. Thirdly, a visual-inertial tightly coupled SLAM method for the snake robot's serpentine gait and Arc-Rolling gait was proposed, and the method was verified to enhance the robustness of the visual SLAM algorithm and improve the positioning and mapping accuracy of the snake robot. Finally, experiments proved that the methods proposed in this paper can effectively improve the accuracy of positioning and map building for snake robots.

Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:30
Vector Functions and Motion: Problem Solving