Related Experiment Video
Updated: Jun 4, 2025
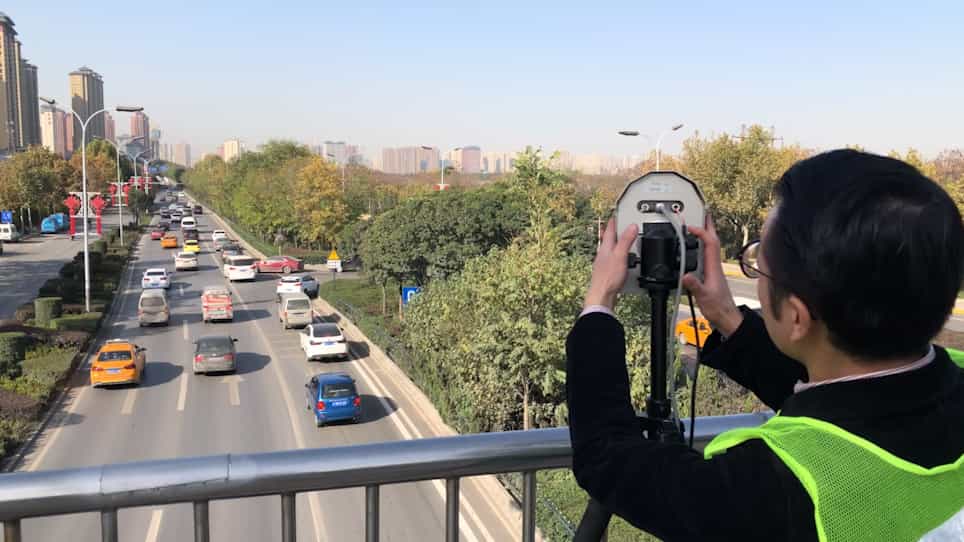
Evaluation of an Exclusive Spur Dike U-Turn Design with Radar-Collected Data and Simulation
Published on: February 1, 2020
Conflict resolution behavior of autonomous vehicles at intersections under mixed traffic environment
1Department of Civil and Environmental Engineering, Michigan State University, Lansing, MI 48910, USA.

Abstract:
Navigating intersections is a major challenge for autonomous vehicles (AVs) because of the complex interactions between different roadway user types, conflicting movements, and diverse operational and geometric features. This study investigated intersection-related AV-involved traffic conflicts by analyzing the Arogoverse-2 motion forecasting dataset to understand the driving behavior of AVs at intersections. The conflict scenarios were categorized into AV-involved and no AV conflict scenarios. Depending on whether AVs passed the conflict region first or second in AV-involved scenarios, AV-involved scenarios were further classified into AV-first and AV-second scenarios. An agglomerative hierarchical clustering with t-SNE dimension reduction technique was applied to categorize the driving styles, and a three-layer Bayesian hierarchical model was applied to analyze the effect of driving volatility measures and traffic characteristics on relative crash risks. The clustering result showed that about 29% of the conflict events in the AV-first scenario (human-driven vehicle (HDV) was the following vehicle in passing the conflict region) exhibited high-risk of conflicts. In contrast, all conflicts events in the AV-second category were either low-risk or medium-risk conflicts. Parameter estimates showed that AVs had safer interactions with the other roadway users (i.e., HDVs, pedestrians/cyclists) while maintaining higher speeds and uniform driving profiles. AV's interaction with vulnerable road users (i.e., pedestrians and cyclists) showed lower crash risk compared to HDVs, indicating AV's safer driving behavior. AVs also demonstrated safer conflict resolution behavior in performing unprotected left turns compared to HDVs. This study discovered some unique insights into the challenges of introducing AVs in diverse intersection types (i.e., signalized, unsignalized, stop-controlled), which can be used to identify AV technology's improvement need to better adapt to the mixed traffic driving environment.
Related Concept Videos
 01:14
Frustration and Conflict: Avoidance-Avoidance, Double-Approach Avoidance
 01:20
Frustration and Conflict: Approach-Approach, Approach-Avoidance
One common type of conflict is the Approach–Approach Conflict. In this case, a person faces two desirable...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:41
Social Traps
 01:42
Schemas
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...