Related Experiment Video
Updated: Jan 8, 2026
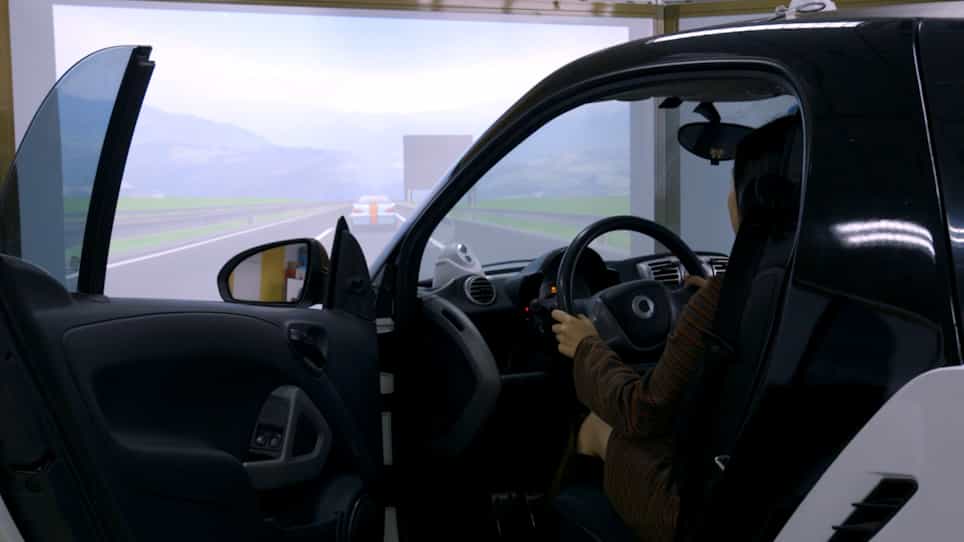
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Analysis of AV merging behavior in mixed traffic using large-scale AV driving datasets
1Department of Civil and Environmental Engineering, Michigan State University, Lansing, MI 48910, United States.

Abstract:
Merging is one of the key maneuvers where autonomous vehicles (AVs) can perform significantly better in decision-making and execution than human-driven vehicles (HDVs). However, past studies have investigated AV merging in simulation environments but have not comprehensively analyzed the interactions between AVs and HDVs during merging events using real-world merging event datasets. This study examines AV merging behavior in mixed traffic environments by extracting and analyzing merging events from the Argoverse-2 and Waymo AV testing datasets. A Weibull random parameter hazard-based duration model was developed to examine the effect of different driving volatilities and traffic measures (i.e., relative speed, velocity standard deviation, and merging location) on merging Gap Time (GT), representing the aggressiveness and merging event crash risk. Descriptive analysis of the AV and HDV merging events showed that the merging GT distributions for AVs and HDVs were similar. Higher GT reduced the following vehicle's speed variation at the target lane for both AV and HDV merging events. Merging crash risk was estimated using the extreme value theory (EVT) approach. The crash risk analysis revealed similar crash risks irrespective of the presence of AVs in merging events. However, AVs were associated with a reduced severity of crashes/conflicts, suggesting that the programmed behavior of AVs, such as smoother acceleration and adherence to traffic rules, contributed to safer merging in the mixed traffic environment. This study's findings identified a need for improvement in AV technology to ensure safer and more efficient operations in mixed traffic. Merging event safety improvements can be achieved by optimizing AV algorithms for dynamic and human-centric traffic conditions during complex driving scenarios.
Related Concept Videos
 01:28
Automatic Processing and Automatic Social Behavior
 01:21
Distributed Loads: Problem Solving