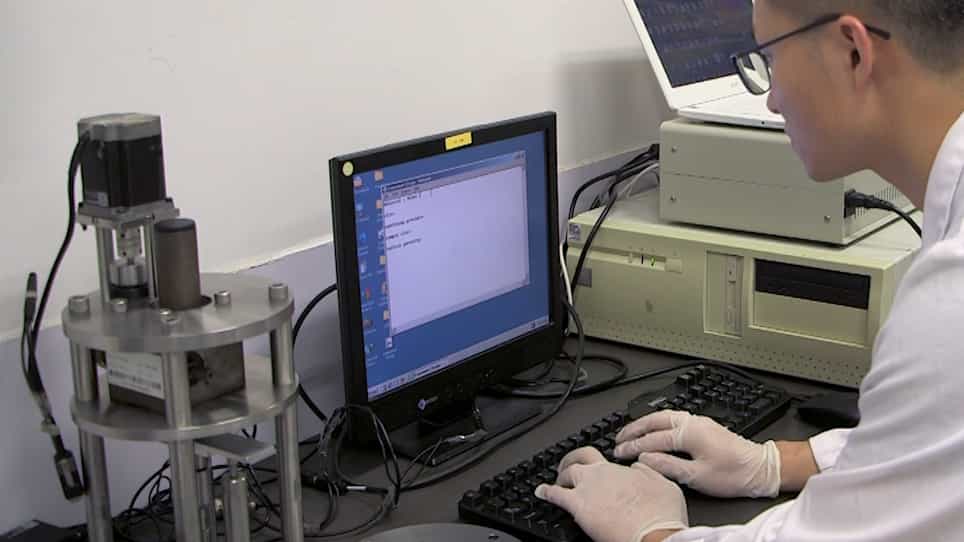

A Framework of State Estimation on Laminar Grinding Based on the CT Image-Force Model
Jihao Liu1, Guoyan Zheng2, Weixin Yan3
1State Key Laboratory of Ocean Engineering, School of Ocean and Civil Engineering, Shanghai Jiao Tong University, Shanghai 200240, China.

Abstract:
It is a great challenge for a safe surgery to localize the cutting tip during laminar grinding. To address this problem, we develop a framework of state estimation based on the CT image-force model. For the proposed framework, the pre-operative CT image and intra-operative milling force signal work as source inputs. In the framework, a bone milling force prediction model is built, and the surgical planned paths can be transformed into the prediction sequences of milling force. The intra-operative milling force signal is segmented by the tumbling window algorithm. Then, the similarity between the prediction sequences and the segmented milling signal is derived by the dynamic time warping (DTW) algorithm. The derived similarity indicates the position of the cutting tip. Finally, to overcome influences of some factors, we used the random sample consensus (RANSAC). The code of the functional simulations has be opened.
Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:30
Three-Dimensional Force System