Modified inverted pendulum on a cart system with four-bar mechanism
Related Experiment Video
Updated: May 27, 2025
Author Spotlight: Enhancing Engineering Education via WebVR-Based Online Laboratories
Published on: February 23, 2024
1Bilecik Seyh Edebali University, Faculty of Engineering, Department of Mechanical Engineering, TR, Bilecik 11210, Türkiye.

Abstract:
In this study, the inverted pendulum on cart system, classic problem of control theory has been modified and an experimental control design has been proposed to maintain balance of a four-bar mechanism instead of a traditional pendulum rod system. Both the inverted pendulum on cart system and the four-bar mechanism are commonly used systems that have been the subject of many control theory problems. Therefore, the combination of these two widely studied systems, which is the focus of this research paper, could very well be integrated for various practical problems such as Segway transportation systems, robotic applications, and rocket guidance systems. With this motivation the modified system has been designated as the "four-bar on a cart system", and dynamic equations of motion have been obtained using the Lagrange method. Furthermore, the performance of the system has been validated through an established experimental setup, and the experimental results for a Lyapunov type backstepping controller are presented. The utilization of a four-bar mechanism instead of a pendulum rod has led to greater challenges in the derivation of the motion of equation due to the additional link position variables in the system. However, despite the modifications on the system, the total degrees of freedom remain unchanged, and the system continues to exhibit dynamic behavior similar to inverted pendulum on cart system. For the completeness of the proposed topic, the inverted pendulum on cart system was initially investigated in this study, and its experimental results were presented. Subsequently, the focus shifted to the four-bar on a cart system.
More Related Videos
 08:08
Oscillation and Reaction Board Techniques for Estimating Inertial Properties of a Below-knee Prosthesis
Published on: May 8, 2014
 07:15
A Testing Platform for Durability Studies of Polymers and Fiber-reinforced Polymer Composites under Concurrent Hygrothermo-mechanical Stimuli
Published on: December 11, 2014
Related Concept Videos
 01:06
Physical Pendulum
When dealing with complicated systems, the mass moment of inertia is an important parameter, as it...
 01:10
Simple Pendulum
The period of a simple pendulum depends on two factors: its length and the acceleration due to gravity. The period is completely independent of any other factors, such as mass or maximum displacement. For small displacements, a pendulum...
 01:09
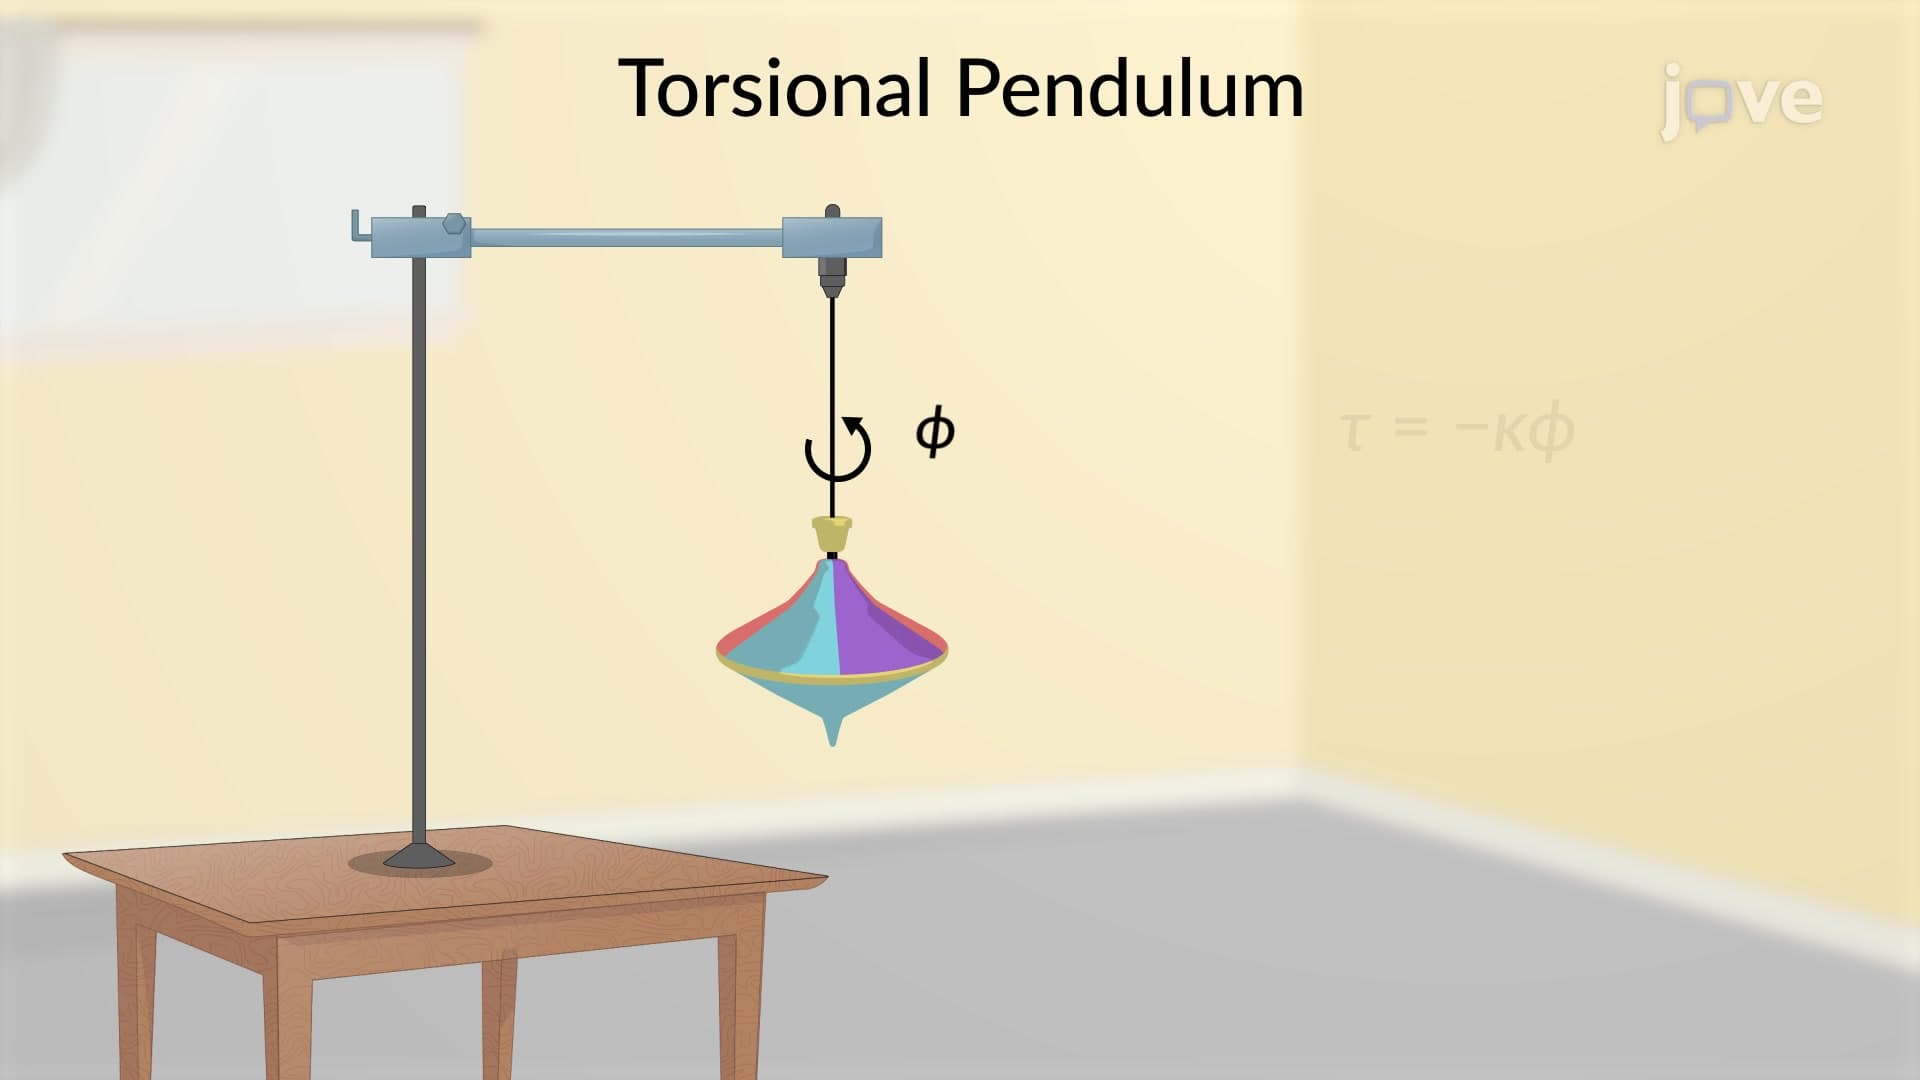
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played...
 01:06
Forced Oscillations
 01:12
Measuring Acceleration Due to Gravity
A simple pendulum can be described as a point mass and a string. Meanwhile, a physical pendulum is any object whose oscillations are similar to a simple pendulum, but cannot be modeled as a point mass on a string because its mass is distributed over a larger area. The behavior of a physical pendulum can be modeled using the principles of...
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?