Related Experiment Video
Updated: May 26, 2025
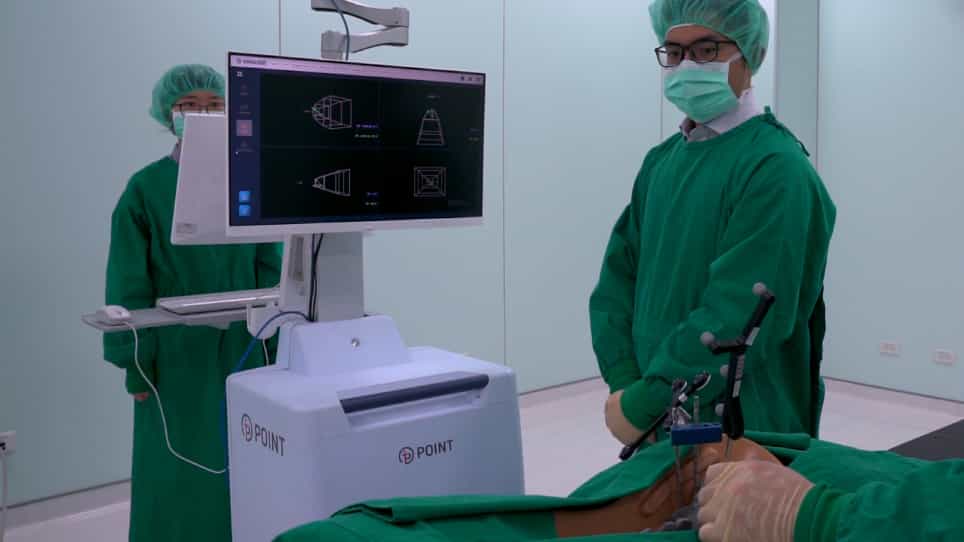
A Spine Robotic-Assisted Navigation System for Pedicle Screw Placement
Published on: May 11, 2020
Vision Module for Automatic Tracking on Bedside Intelligent Scope-Holding Surgical Robot System
Tingting Wang1, Mingyu Yin1, Shunkai Shi2
1Department of Mechanical and Electrical Engineering, Hohai University, Changzhou, China.

Background:
This study aims to develop an active following technology of the mirror-holding arm of a bedside intelligent surgical robot that enables real-time automatic tracking of surgical instruments.
Methods:
The semantic segmentation network was adaptively enhanced, and new datasets were collected with surgical clamps as the target, incorporating scenarios commonly encountered during surgical procedures. In addition, the position of the clamp was determined, and the range and mode of motion of the robot arm were set. Based on the above premise, the control rate was designed and verified using an endoscopic surgery simulation platform.
Results:
The average time for the collaborative arm to reach the centre of the field of view was 2.51 s, with a variance of 0.32.
Conclusions:
The results of this study validate the effectiveness of replacing manual endoscope holding with a robotic arm, which has great potential to facilitate more efficient endoscopic surgical procedures.
More Related Videos
 07:46
Author Spotlight: Revolutionizing Remote Surgery with Augmented Reality and Robotics for Enhanced Precision and Accessibility
Published on: August 9, 2024
 05:12
Robotized Testing of Camera Positions to Determine Ideal Configuration for Stereo 3D Visualization of Open-Heart Surgery
Published on: August 12, 2021