Related Experiment Video
Updated: May 24, 2025
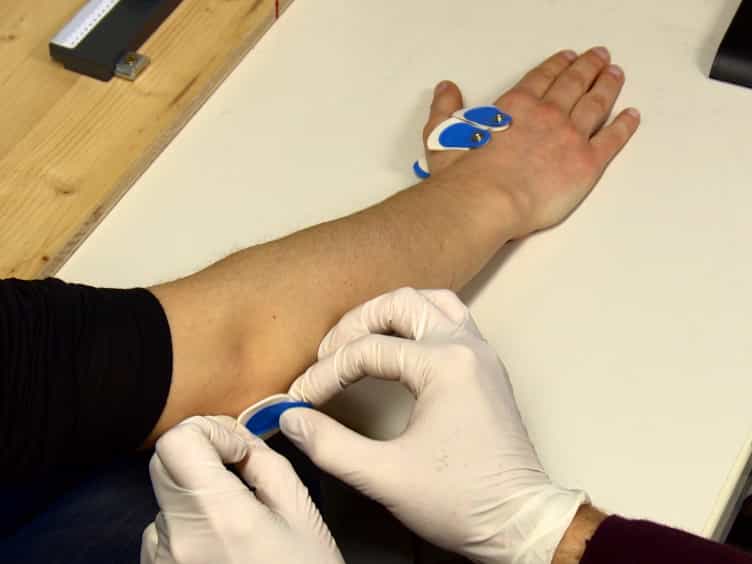

Force and Position Control in Humans - The Role of Augmented Feedback
Published on: June 19, 2016
Calibration and Closed-Loop Control Improve Performance of a Force Feedback Device

Abstract:
Interaction accuracy and transparency of force feedback devices (FFDs) are crucial in applications like remote surgery, where high force feedback accuracy (FFA) ensures the safety of delicate procedures. However, few studies have introduced the force calibration of FFDs, especially addressing the low FFA issue in high dynamic motions. This paper proposes a calibration method and a closed-loop control (CLC) strategy for an FFD to enhance its FFA. Tailored calibration models were developed by decoupling factors causing feedback force errors. The CLC was achieved by modeling the FFD's kinematics, statics, and dynamics and integrating force and current information. Experimental results show that the integration of the models and CLC significantly improved FFA, evidenced by a reduction in mean absolute error (MAE) from 0.843 N to 0.054 N and a mean relative absolute error (MRAE) from 18.89% to 1.52% in static conditions. In dynamic motions, the MAE reduced from 3.10 N to 0.370 N, and the MRAE declined from 117.66% to 22.57%. With human-in-the-loop, the CLC reduced the MAE by about 93% and the MRAE by about 92%. The ablation study showed the effectiveness of each calibration model. Our methodology can be applied to similar motor-driven FFDs.


Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:24
Effects of feedback
Feedback significantly modifies the gain of a control system. The gain of a system without feedback is altered by a factor of one plus GH, where G represents...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:10
Control Systems
At the heart...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...