Cross-Camera Pedestrian Trajectory Retrieval Based on Linear Trajectory Manifolds
Related Experiment Video
Updated: May 24, 2025

Trajectory Data Analyses for Pedestrian Space-time Activity Study
Published on: February 25, 2013

Abstract:
The goal of pedestrian trajectory retrieval is to infer the multi-camera path of a targeted pedestrian using images or videos from a camera network, which is crucial for passenger flow analytics and individual pedestrian retrieval. Conventional approaches hinge on spatiotemporal modeling, necessitating the gathering of positional information for each camera and trajectory data between every camera pair for the training phase. To mitigate these stringent requirements, our proposed methodology employs solely temporal information for modeling. Specifically, we introduce an Implicit Trajectory Encoding scheme, dubbed Temporal Rotary Position Embedding (T-RoPE), which integrates the temporal aspects of within-camera tracklets directly into their visual representations, thereby shaping a novel feature space. Our analysis reveals that, within this refined feature space, the challenge of inter-camera trajectory extraction can be effectively addressed by delineating a linear trajectory manifold. The visual characteristics gleaned from each candidate trajectory are utilized to compare and rank against the query feature, culminating in the ultimate trajectory retrieval outcome. To validate our method, we collected a new pedestrian trajectory dataset from a multi-storey shopping mall, namely the Mall Trajectory Dataset. Extensive experimentation across diverse datasets has demonstrated the versatility of our T-RoPE module as a plug-and-play enhancement to various network architectures, significantly enhancing the precision of pedestrian trajectory retrieval tasks. The dataset and code are released at https://github.com/zhangxin1995/MTD.
Related Concept Videos
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:15
Kinematic Equations: Problem Solving
 01:27
Curvilinear Motion: Normal and Tangential Components
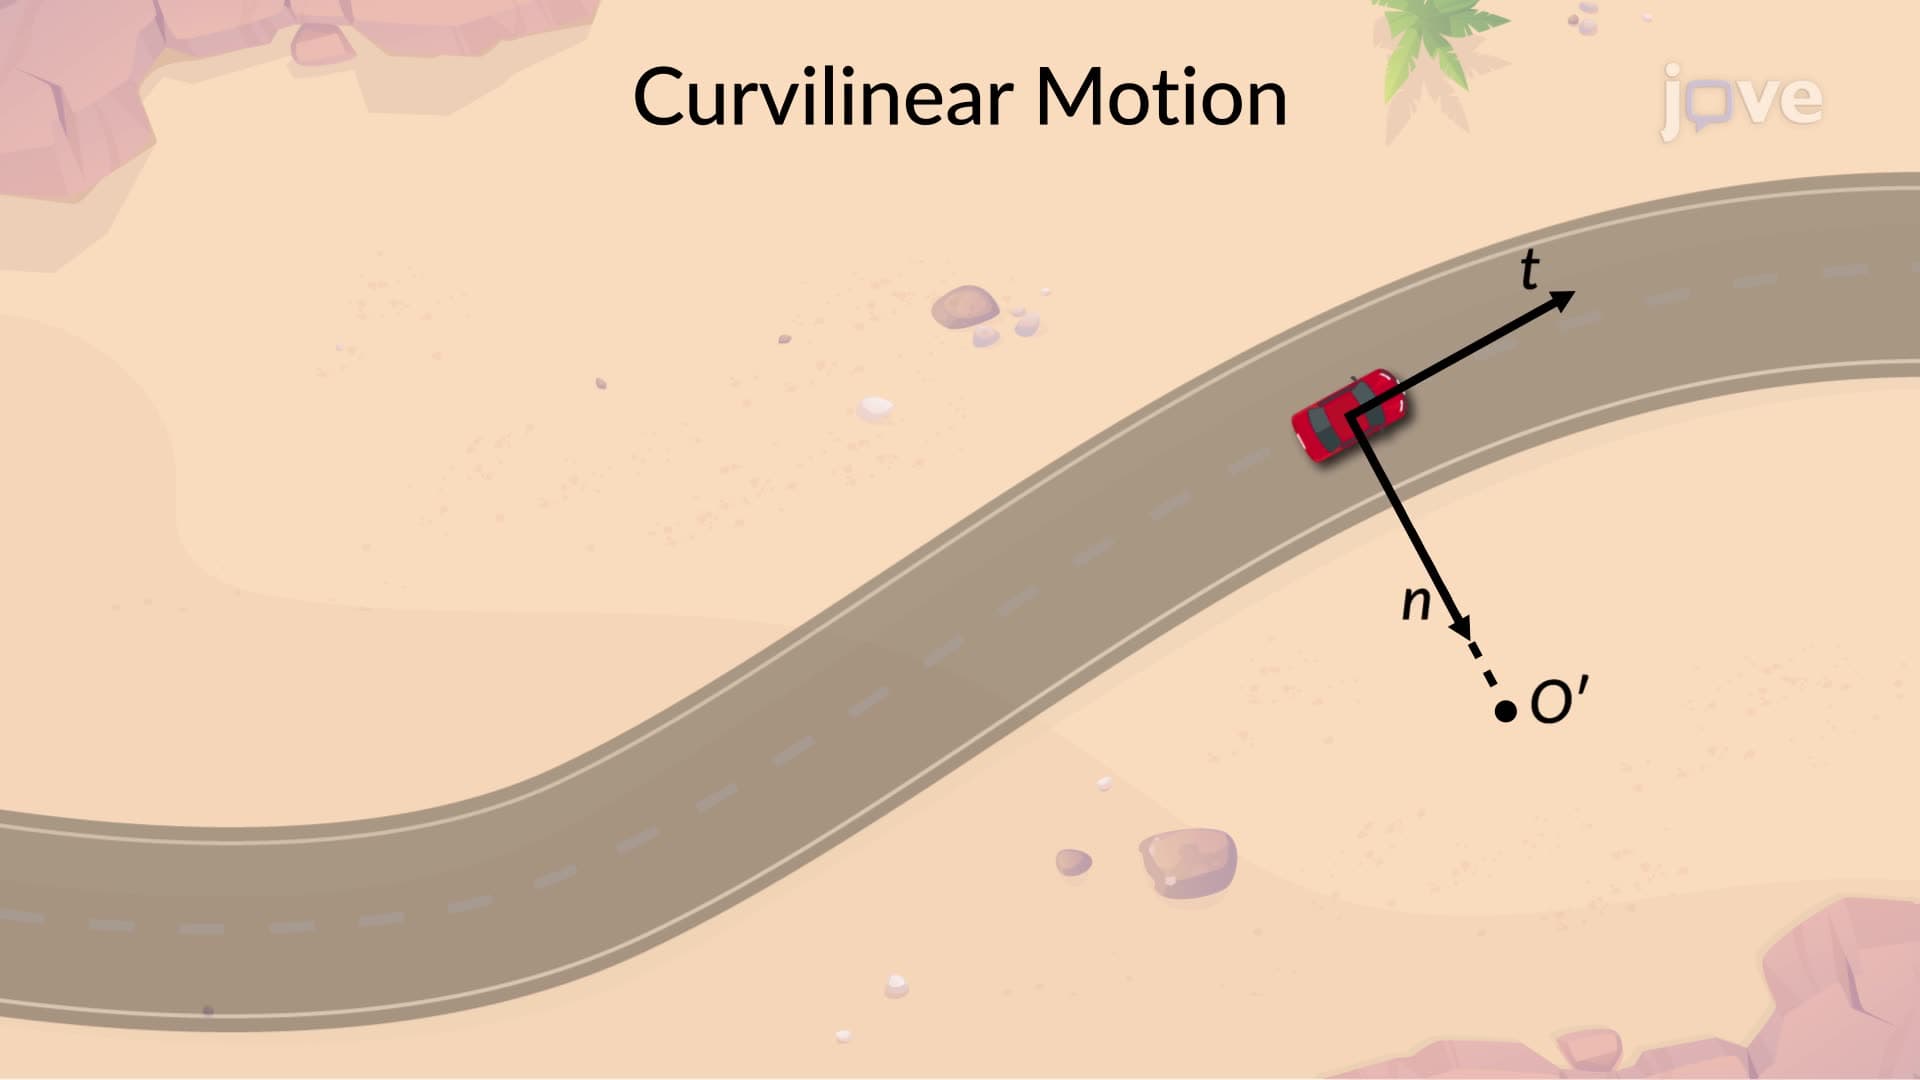
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...