DPCS: Path Tracing-Based Differentiable Projector-Camera Systems
Related Experiment Video
Updated: May 21, 2025
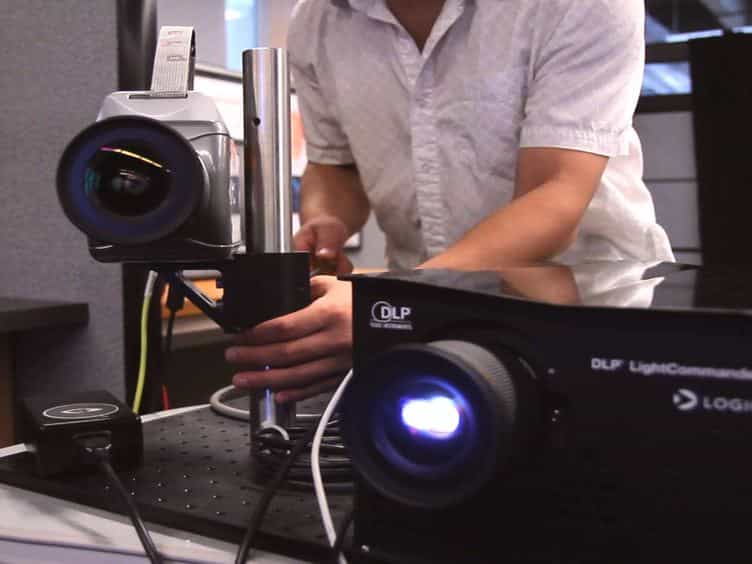
High-resolution, High-speed, Three-dimensional Video Imaging with Digital Fringe Projection Techniques
Published on: December 3, 2013

Abstract:
Projector-camera systems (ProCams) simulation aims to model the physical project-and-capture process and associated scene parameters of a ProCams, and is crucial for spatial augmented reality (SAR) applications such as ProCams relighting and projector compensation. Recent advances use an end-to-end neural network to learn the project-and-capture process. However, these neural network-based methods often implicitly encapsulate scene parameters, such as surface material, gamma, and white balance in the network parameters, and are less interpretable and hard for novel scene simulation. Moreover, neural networks usually learn the indirect illumination implicitly in an image-to-image translation way which leads to poor performance in simulating complex projection effects such as soft-shadow and interreflection. In this paper, we introduce a novel path tracing-based differentiable projector-camera systems (DPCS), offering a differentiable ProCams simulation method that explicitly integrates multi-bounce path tracing. Our DPCS models the physical project-and-capture process using differentiable physically-based rendering (PBR), enabling the scene parameters to be explicitly decoupled and learned using much fewer samples. Moreover, our physically-based method not only enables high-quality downstream ProCams tasks, such as ProCams relighting and projector compensation, but also allows novel scene simulation using the learned scene parameters. In experiments, DPCS demonstrates clear advantages over previous approaches in ProCams simulation, offering better interpretability, more efficient handling of complex interreflection and shadow, and requiring fewer training samples. The code and dataset are available on the project page: https://jijiangli.github.io/DPCS/.
Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:22
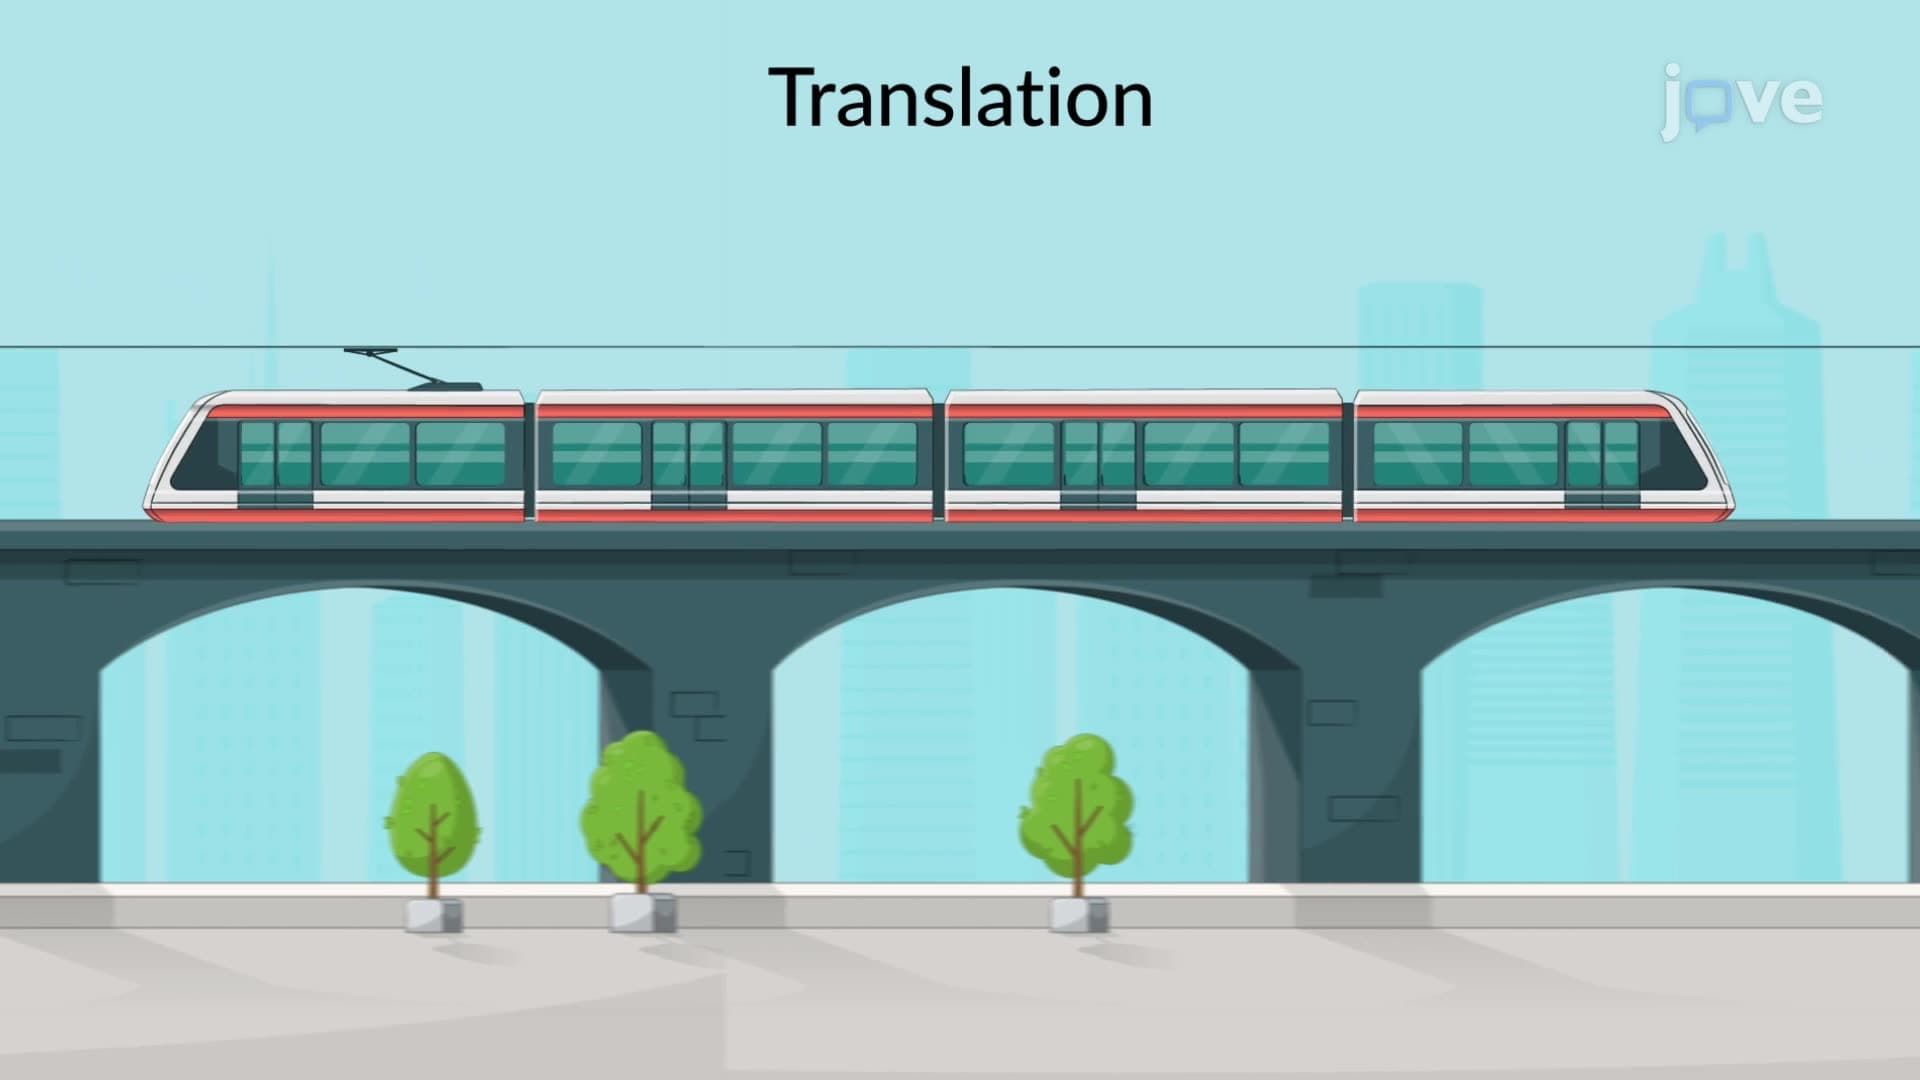
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:25
Design Example: Traverse Angle Computations
 01:27
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position...