Related Experiment Video
Updated: May 21, 2025


Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot
Published on: June 10, 2020
Earthworm-Inspired Multimodal Pneumatic Continuous Soft Robot Enhanced by Winding Transmission
Jianbin Liu1, Pengcheng Li1, Zhihan Huang1
1Key Laboratory of Mechanism Theory and Equipment Design of Ministry of Education, Tianjin University, Tianjin 300072, China.

Abstract:
This paper presents an earthworm-inspired multimodal pneumatic continuous soft robot enhanced by wire-winding transmission. First, a derived overlapped continuous control law based on multiple peristaltic waves is introduced to effectively improve the motion performance of the robot. Second, by applying the wire-winding transmission method, the extension of one segment is simultaneously transformed into the contraction of other segments, achieving coordinated deformation and making it more similar to real earthworms. In addition, an autonomous obstacle-avoidance control strategy based on contact force sensing is developed to enhance the environmental adaptability of the robot. Based on these methods, an earthworm-inspired soft robot that can perform multimodal movements with autonomous obstacle-avoidance ability and enhanced motion efficiency is developed. A series of experiments including in- and cross-plane crawling, obstacle avoidance steering, and pipeline crawling are conducted to validate the robot's multimodal motion capabilities. The robot can achieve a speed of 6.65 mm/s (36.0 × 10⁻³ bl/s) during in-plane crawling movement and 1.66 mm/s (8.97 × 10⁻³ bl/s) during pipeline crawling movement. In terms of the in-plane crawling speed, the robot surpasses other robots of the same type. In conclusion, the robot's multimodal capabilities and enhanced motion efficiency demonstrate superior overall performance, and the robot has good potential for medical and industrial applications.

Related Concept Videos
 01:22
Mechanical Systems
 01:16
Design of Transmission Shafts
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:14
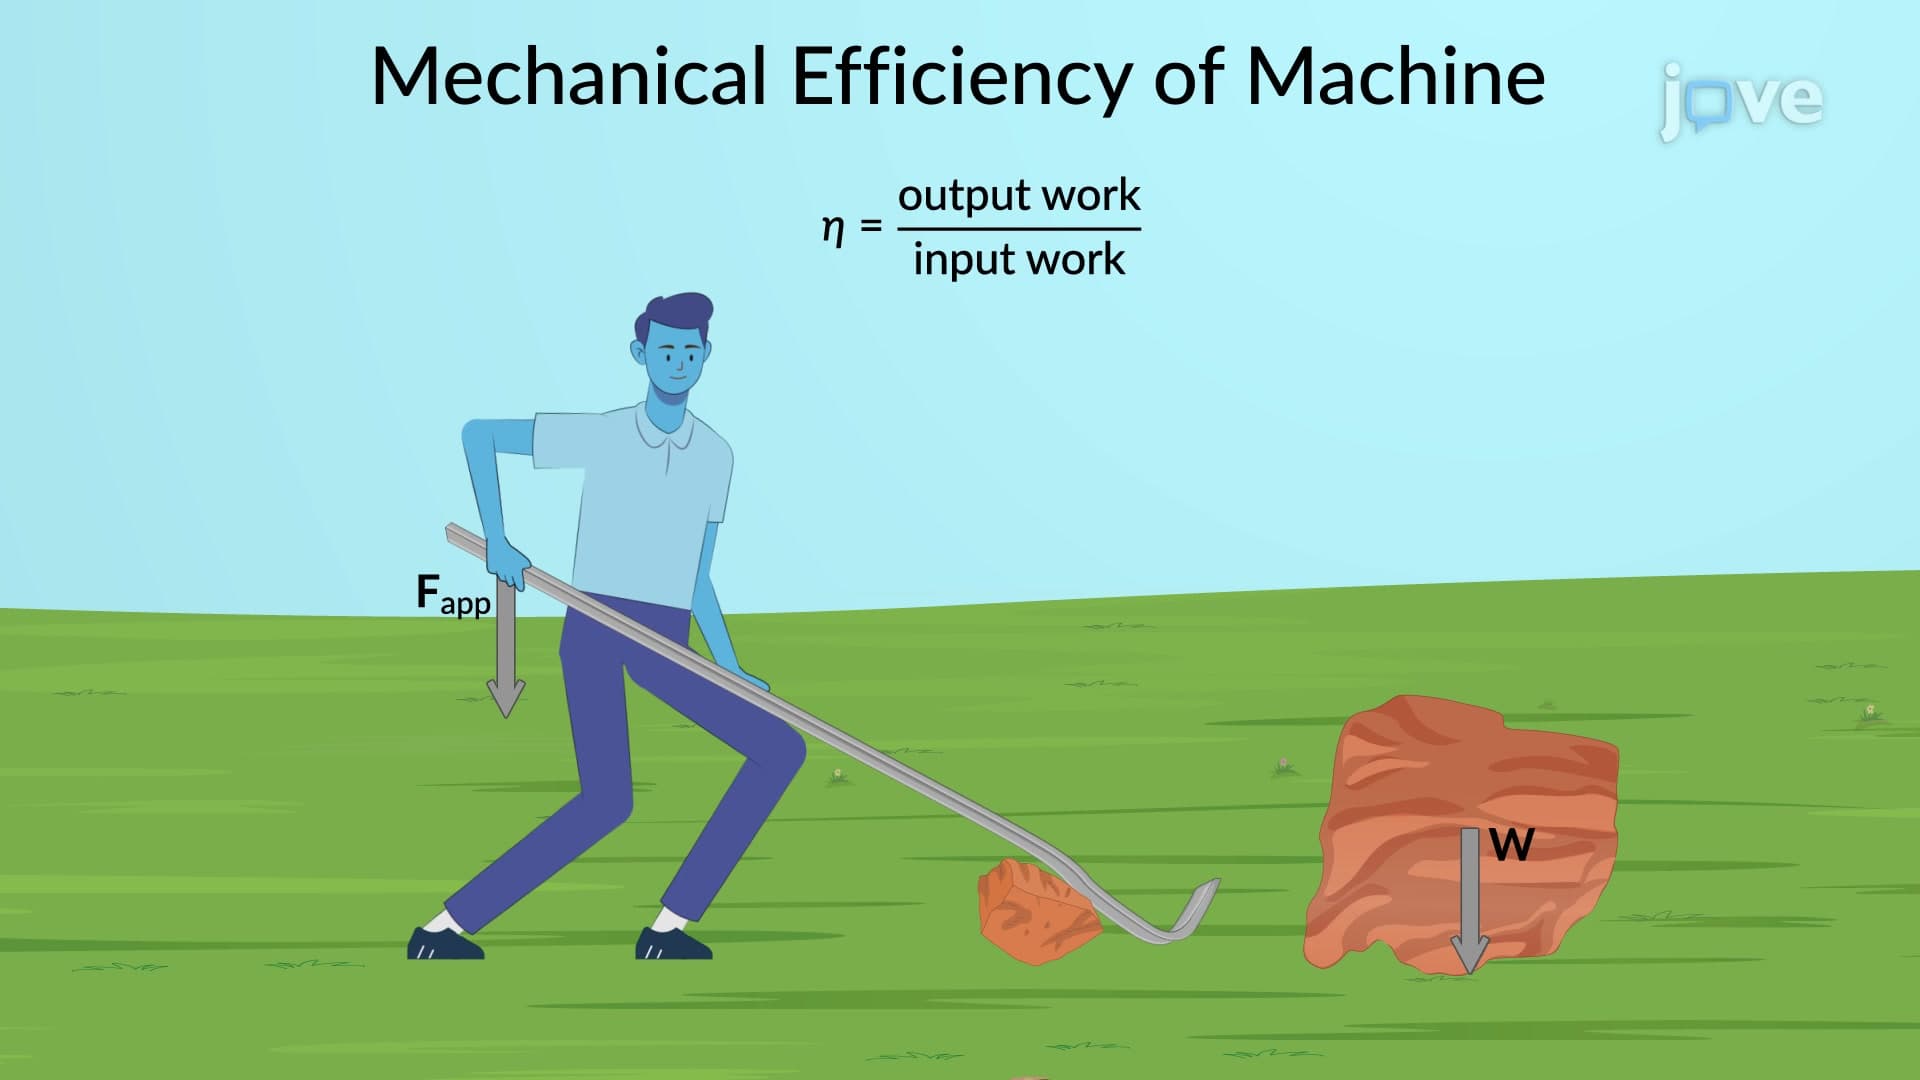
Mechanical Efficiency of Real Machines
However, in reality, no machine can be truly ideal, and all of them experience some...
 01:20
Plastic Deformation in Circular Shafts
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...