Related Experiment Video
Updated: May 5, 2026

Quantifying Learning in Young Infants: Tracking Leg Actions During a Discovery-learning Task
Published on: June 1, 2015
Changes in time-continuous joint kinematics in preschool children over the stance phase of gait
Marketa Rygelova1, Jaroslav Uchytil1, Joseph Hamill2
1Department of Human Movement Studies, University of Ostrava, Ostrava, Czech Republic.

Insights
Statistical parameter mapping (SPM) reveals significant differences in lower limb gait kinematics in preschool children. This method offers a clearer understanding of age-related changes in child gait development.
Area of Science:
- Pediatric Gait Analysis
- Developmental Biomechanics
- Motor Development
Background:
- Comparing gait kinematics across different child ages requires advanced analytical tools.
- Statistical parameter mapping (SPM) is a suitable method for analyzing gait waveform differences.
- Traditional methods focusing on curve maxima/minima are less descriptive of age-related gait changes.
Purpose of the Study:
- To investigate differences in lower limb kinematic waveforms during gait in typically developing preschool children.
- To determine if and how gait patterns evolve between ages 2, 3, and 6 years.
Main Methods:
- A cross-sectional study design was employed.
- Statistical parameter mapping (SPM) was utilized to compare gait kinematics.
- Kinematic data were collected from 42 typically developing preschool children aged 2, 3, and 6 years.
Main Results:
- Significant differences were observed in foot internal rotation and knee rotation/abduction waveforms between age groups.
- Two-year-olds exhibited distinct foot internal rotation patterns compared to 3- and 6-year-olds.
- Knee kinematics, including internal rotation and abduction, showed age-dependent variations during the stance phase.
Conclusions:
- Comparing gait kinematic waveforms using SPM provides a more comprehensive understanding of developmental changes.
- This approach enhances the clarity of differences in gait patterns across various preschool ages.
- SPM is a valuable tool for characterizing normative gait development in children.
Background:
The use of statistical parameter mapping (SPM) to compare gait kinematics of children at different ages seems to be a more appropriate tool to describe the differences than simply describing the maxima and minima on the curves.
Research Question:
Does lower limb kinematic waveforms differ during gait in normally developing preschool children?
Methods:
In a cross-sectional study, SPM was used to compare kinematic waveforms of typically developing preschool children at ages 2, 3, and 6 years (n = 42).
Results:
Differences in internal rotation foot angle between 2-year-olds and 3-, 6-year-olds in 22-55 % lower in 2-year-olds but 85-100 % greater in 2-year-olds. Greater internal rotation of the knee in 2-year-olds versus 6-year-olds in 13-25 % of the stance phase. Lower knee abduction in 2-year-olds versus 6-year-olds in the first 13 % of the stance phase.
Significance:
Comparison of the waveforms of the angle may provide a clearer understanding of the differences in gait kinematics in children at different ages.
Related Concept Videos
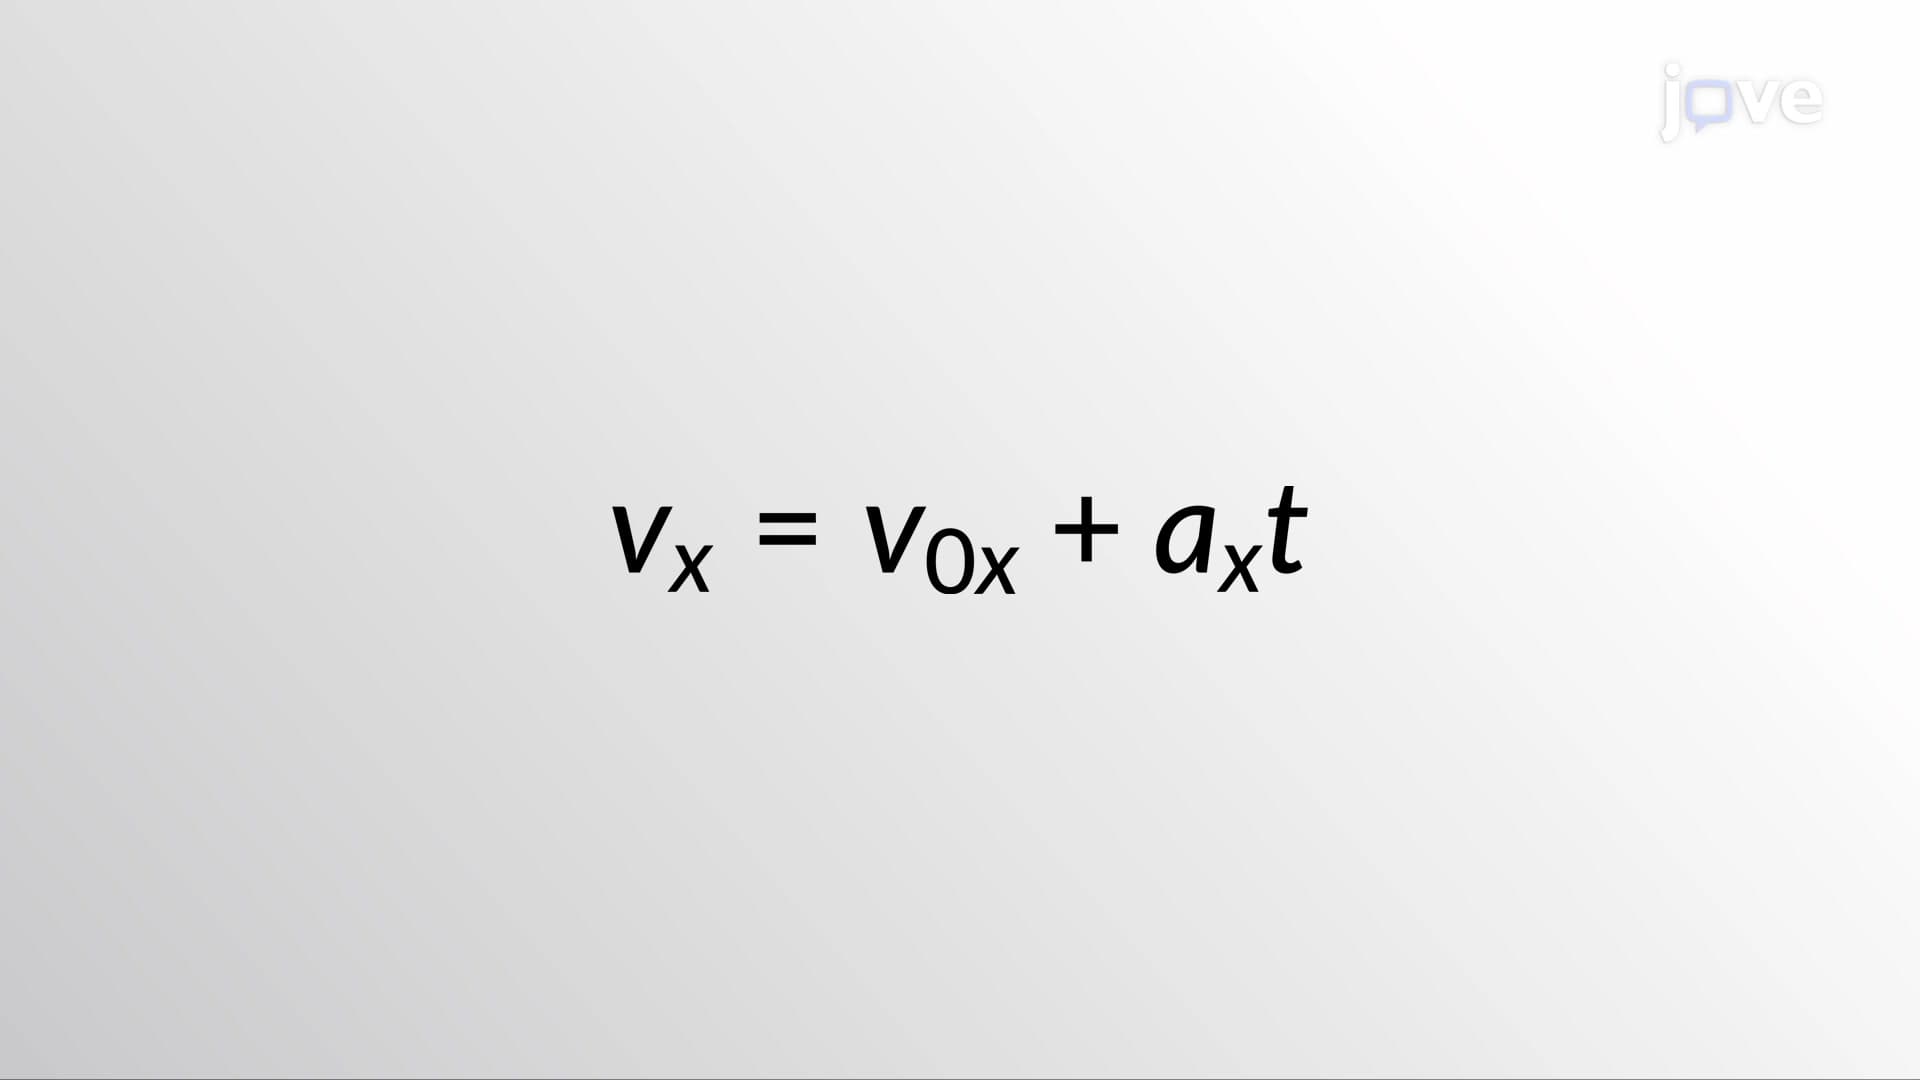 01:26
Kinematic Equations - I
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:15
Kinematic Equations: Problem Solving
 01:09
Changes in the Appendicular Skeleton with Age
Initially, the limb buds consist of a core of mesenchyme covered by a layer of ectoderm. The ectoderm at the end of the limb bud thickens to form a narrow crest called the apical ectodermal ridge. This ridge stimulates the underlying...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...