Related Experiment Video
Updated: May 12, 2025


Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
Nonsingular fast predefined time convergence sliding mode control for construction robot
Chun-Wu Yin1, Yun-Peng Ding1, Hou-Jun Sun2
1College of Information and Control Engineering, Xi'an University of Architecture and Technology, Xi'an, Shaanxi 710055, China.

Abstract:
To solve the practical engineering problem that the angle of a construction robot with an arbitrary initial value completely and accurately track the desired trajectory, this paper presents a control strategy for extending the desired trajectory, and a sliding mode controller with predefined time convergence is designed for an uncertain construction robot. Firstly, the special characteristics of the construction robot's trajectory tracking control are analyzed, an extended desired trajectory control strategy including the arrival phase and the precise tracking phase is proposed, and the design method of the extended desired trajectory in the arrival stage is given. Then, based on the improved non-singular fast sliding mode surface and a novel stability criterion of predefined time convergence, a predefined time convergence sliding mode controller based on a state observer was designed for the construction robot, which enables the angle tracking error of the construction robot to converge to zero within the specified time, ensures the angle completely and accurately tracking the original desired trajectory. Comparative simulation results show that the angle tracking error based on the proposed algorithm reaches 0.0004 rad, with an accuracy improvement of 33 %, and solves the problem of control torque chattering.


Related Concept Videos
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
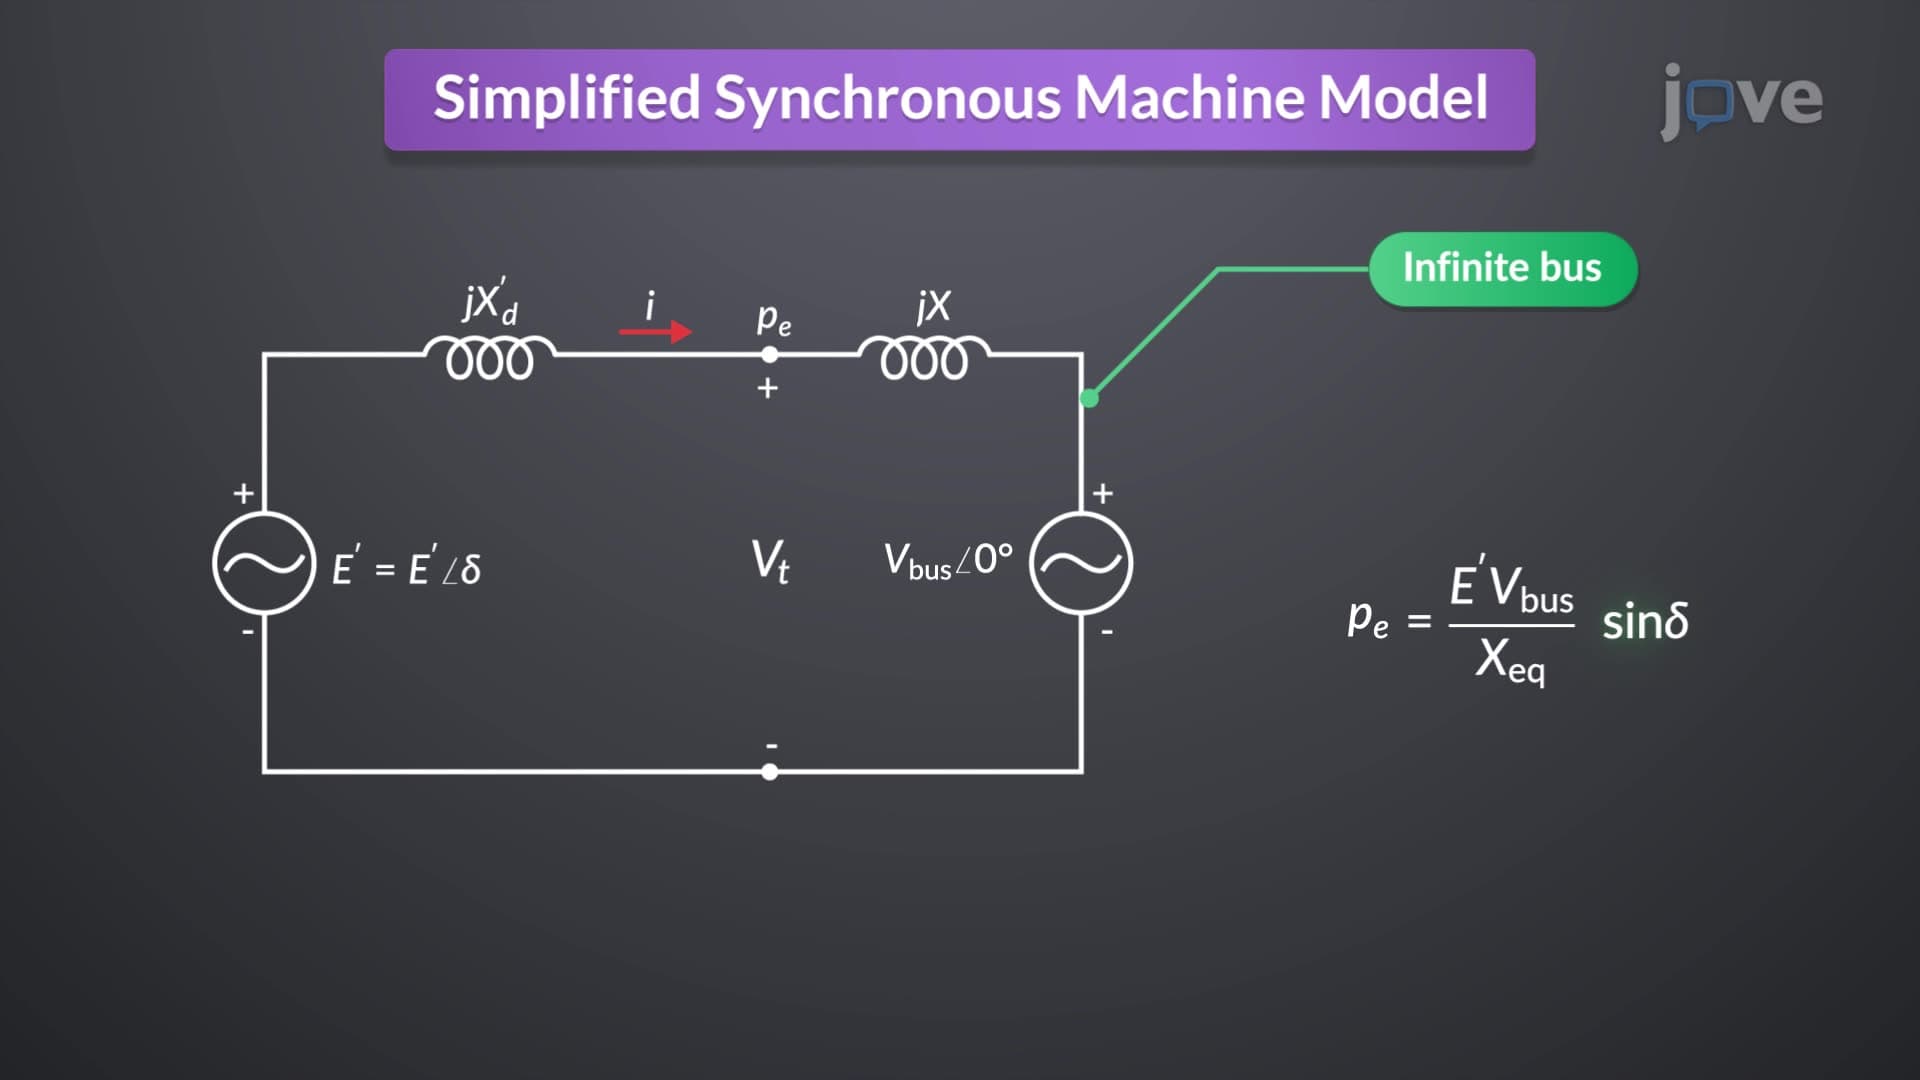 01:30
Simplified Synchronous Machine Model
In this model, each generator is connected to a...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:10
Relative Motion Analysis - Acceleration