Related Experiment Video
Updated: May 15, 2025


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Model-free reinforcement learning control with zero-min barrier functions for constrained systems
1Robotics and Advanced Manufacturing, Center for Research and Advanced Studies (CINVESTAV), 1062 Industria Metalurgica Av., Ramos Arizpe, 25903, Mexico.

Abstract:
The primary focus of this research is to develop an adaptive output feedback controller designed to minimize a cost-to-go function subject to constraints on input, output, and tracking error for a class of unknown non-affine discrete-time systems. The problem formulation addresses a general class of non-affine dynamics, exemplified by a high-gain DC motor torque control system, in which maintaining safe operation within prescribed input and output limits is critical. These physical limitations necessitate the incorporation of constraints to ensure the plant operates within safe regions. Consequently, a zero-min barrier function is employed in conjunction with a reinforcement learning algorithm to enforce both symmetric and asymmetric constraints. The control law employs actor-critic networks implemented through fuzzy rule-emulated networks, enabling adaptive performance. By deriving online learning laws, the system achieves nearly optimal tracking performance and ensures the forward invariance of the safe operating region, all without requiring inner iterations, thereby enhancing computational efficiency. Experimental validation under extreme disturbances and abrupt changes in the desired trajectory, which present a risk of constraint violations, demonstrates the robustness and effectiveness of the proposed controller. Comparative results further highlight the advantages of the proposed method in achieving a balance between near-optimal performance and strict constraint satisfaction, thereby ensuring stable operation within predefined limits.


Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
 01:21
First Order Systems
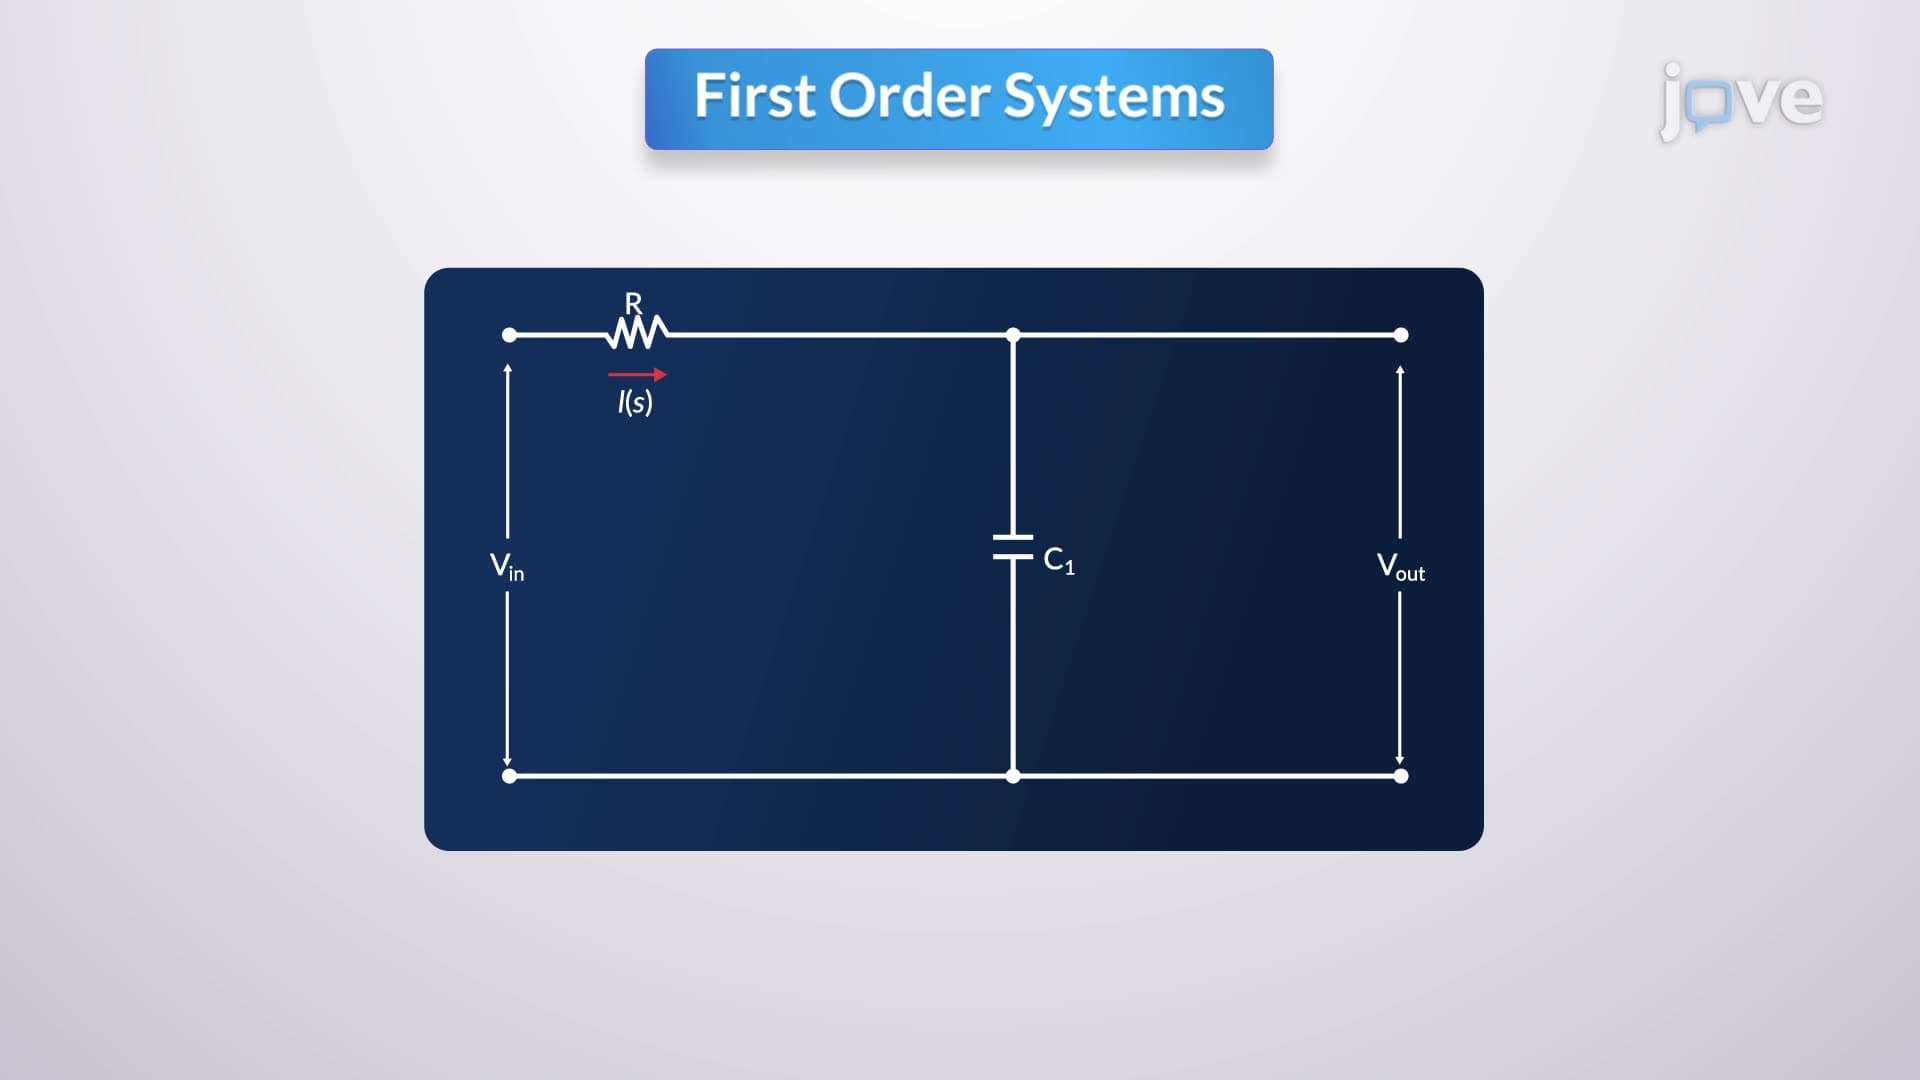
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...