Related Experiment Video
Updated: May 24, 2026
A Method for 3D Reconstruction and Virtual Reality Analysis of Glial and Neuronal Cells
Published on: September 28, 2019
SPU+: Dimension Folding for Semantic Point Cloud Upsampling

Abstract:
Semantic Point Cloud Upsampling (SPU) aims to reconstruct a high-resolution (dense) 3D point cloud from a low-resolution (sparse) one, ensuring that the upsampled point cloud is easily recognizable by downstream tasks. Conventional upsampling architectures typically represent point clouds using high-dimensional feature vectors. However, we observe a dimensional bottleneck, where simply increasing the feature dimensionality does not necessarily improve performance on semantic tasks. This insight motivates us to explore more effective feature representations within upsampling networks. In this paper, we propose a novel SPU method called SPU+, which introduces dimension folding as an alternative strategy for handling high-dimensional features. Specifically, SPU+ decomposes each high-dimensional feature into several g-dimensional packages, allowing interactions among packages within the feature space. Guided by the principle of maximizing feature diversity, we determine that setting the package dimension to 3 yields optimal performance. To enable convolutional operations over these 3D packages, we present a 3D Residual Graph Convolution Block (3D-RGCB) that achieves high computational efficiency. Based on 3D-RGCBs, we design an upsampling network that incorporates three structural modes: pre-mode, middle-mode, and end-mode. Additionally, for large-scale upsampling, we develop a scaling-and-shuffling strategy that adaptively adjusts the spatial size of each 3D package. Finally, we analyze the covering number of the 3D package representation and compare it to traditional high-dimensional feature representations. Experiments on publicly available datasets demonstrate not only the effectiveness of dimension folding but also the state-of-the-art performance achieved by SPU+. Code is available at: https://github.com/lizhuangzi/SPU_plus.
Related Concept Videos
 01:23
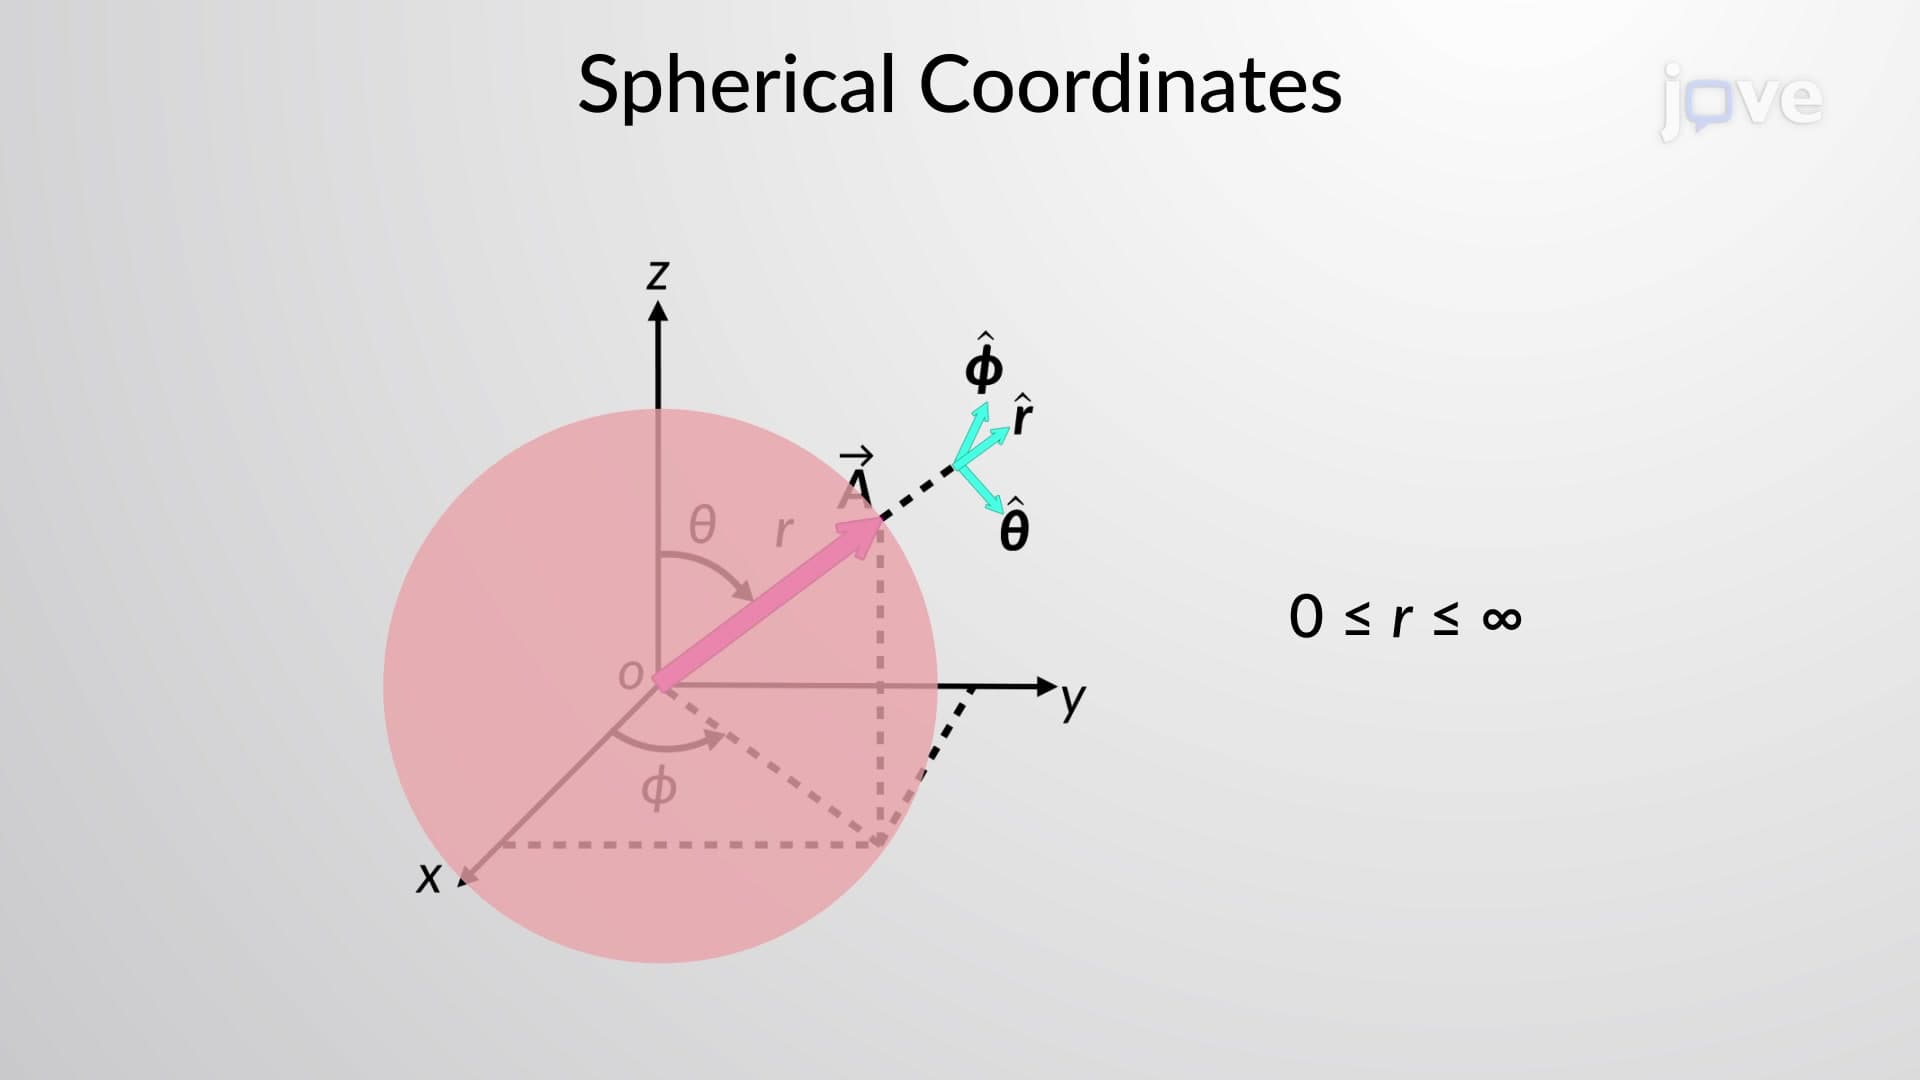
Spherical Coordinates
 01:20
Downsampling
The Fourier transform of the decimated sequence reveals a combination of scaled and shifted versions of the original spectrum. This...
 01:22
Upsampling
 01:15
Depth Perception and Spatial Vision