Composite safety potential field for highway driving risk assessment
Related Experiment Video
Updated: Sep 19, 2025
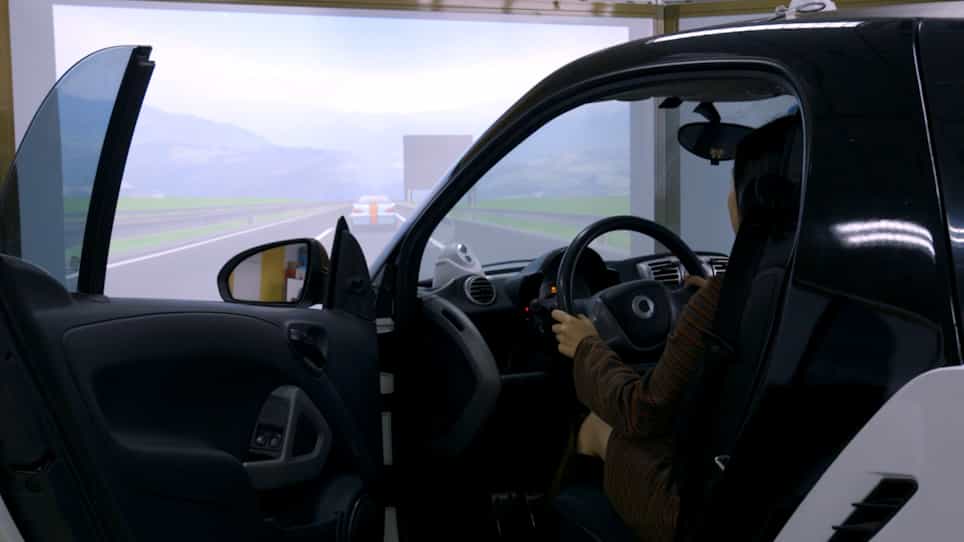
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Dachuan Zuo1, Zilin Bian1, Fan Zuo1
1Department of Civil and Urban Engineering, Tandon School of Engineering, New York University, 6 MetroTech Center, 4th Floor, Brooklyn, NY, USA.

Abstract:
In the era of rapid advancements in vehicle safety technologies, driving risk assessment has become a focal point of attention. Technologies such as collision warning systems, advanced driver assistance systems (ADAS), and autonomous driving require driving risks to be evaluated proactively and in real time. To be effective, driving risk assessment metrics must not only accurately identify potential collisions but also exhibit human-like reasoning to enable safe and seamless interactions between vehicles. Existing safety potential field models assess driving risks by considering both objective and subjective safety factors. However, their practical applicability in real-world risk assessment tasks is limited. These models are often challenging to calibrate due to the arbitrary nature of their structures, and calibration can be inefficient because of the scarcity of accident statistics. Additionally, they struggle to generalize across both longitudinal and lateral risks. To address these challenges, we propose a composite safety potential field framework, namely C-SPF, involving a subjective field to capture drivers' risk perception about spatial proximity and an objective field to quantify the imminent collision probability, to comprehensively evaluate driving risks. Different from existing models, the C-SPF is calibrated using abundant two-dimensional spacing data from trajectory datasets, enabling it to effectively capture drivers' proximity risk perception and provide a more realistic explanation of driving behaviors. Analysis of a naturalistic driving dataset demonstrates that the C-SPF can capture both longitudinal and lateral risks that trigger drivers' safety maneuvers. Further case studies highlight the C-SPF's ability to explain lateral driver behaviors, such as abandoning lane changes or adjusting lateral position relative to adjacent vehicles, which are capabilities that existing models fail to achieve.
Related Concept Videos
 01:28
Survey Safety
 01:29
Sight Distance in a Vertical Curve
 01:22
Design Consideration
The factor of safety is another key...
 01:21
Friction: Problem Solving
Initially, a visual representation of the...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:17
Design Example: Analyzing Capacity Contours for Flood Risk Assessment