Enhancing mu-ERD through combined robotic assistance and motor imagery: a novel approach for upper limb
Hiroki Yasuda1,2, Masaya Ueda1, Keita Ueno1
1Department of Occupational Therapy, Osaka Metropolitan University Graduate School of Rehabilitation Science, Habikino, Japan.

Introduction:
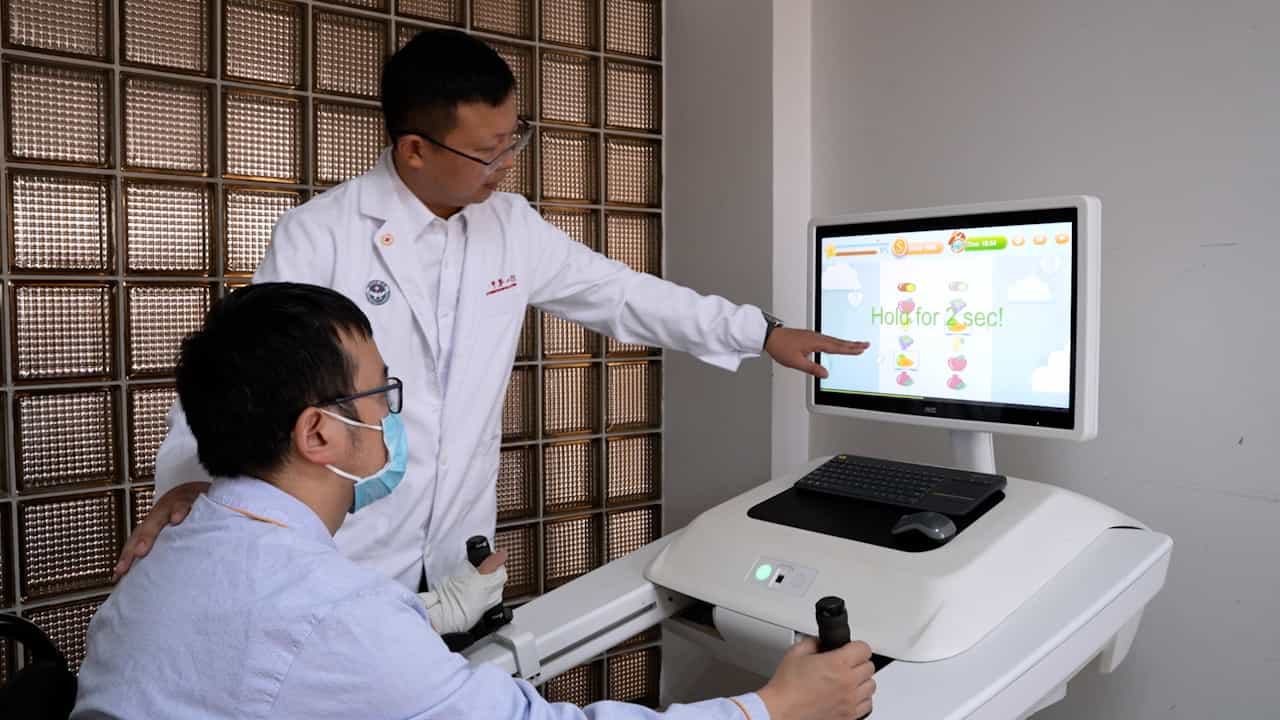
Previous research has suggested that mu-event-related desynchronization (mu-ERD) reflects neural activity associated with motor observation and execution, primarily within the sensorimotor cortex. This study aimed to investigate the effects of combining robotic full-assist therapy with motor imagery on mu-ERD in healthy adults for potential application in stroke patients with severe upper limb paralysis.
Methods:
Fifteen healthy adults were included in this study. Each participant performed three conditions using the ReoGo-J® robotic system: voluntary movement, full-assist robotic therapy without motor imagery, and full-assist robotic therapy with motor imagery. Electroencephalography (EEG) was used to measure mu-ERD, focusing on the 8-10 Hz and 10-13 Hz frequency bands at the C3, C4, Cz, and Pz electrodes.
Results:
Significant differences in mu-ERD occurrence were observed at C3 (8-10 Hz) and C4 (10-13 Hz) between the conditions. The combination of motor imagery and robotic therapy demonstrated a higher frequency of mu-ERD occurrence than the other conditions, with moderate effect sizes. However, no significant differences in mu-ERD attenuation rates were found between the conditions. This suggests variability in individual responses.
Discussion:
These findings highlight the potential of robotic full-assist therapy combined with motor imagery to stimulate neural mechanisms associated with motor recovery. Future studies should include a larger sample size and patients with stroke to validate these findings and explore their clinical applications.