Related Experiment Video
Updated: Sep 18, 2025

Combining 3D Magnetic Force Actuator and Multi-Functional Fluorescence Imaging to Study Nucleus Mechanobiology
Published on: July 5, 2022
Analysis of magnetic configuration and its effect on motion in magnetically actuated soft miniature robots within
Afarin Khabbazian1, Mir Behrad Khamesee1, Veronika Magdanz2
1Department of Mechanical and Mechatronics Engineering, University of Waterloo, Waterloo, Ontario Canada.

Abstract:
Soft, magnetically actuated robots offer promising potential for medical applications due to their simple fabrication, controllability, cargo loading ability and flexibility. This research focuses on the design, modeling, and behavior of soft, millimeter-scale filamentous robots composed of Gelatin Methacrylate (GelMa) hydrogels and embedded with micromagnets for magnetic actuation. These robots are designed for navigation within the human urinary tract. The study investigates two distinct configurations: screw-like and fin-like robots, each responding differently to an external rotating magnetic field. The screw-like robots propel forward through synchronized helical motion, while the fin-like robots rely on interaction with surrounding surfaces for crawling motion. Experimental frequency response tests reveal that fin-like robots exhibit three times faster motion than screw-like robots in confined environments, reaching velocities of up to 18 mm/s. Additionally, the influence of micromagnet location inside the filaments on their propulsion dynamics is explored, highlighting the potential for optimized performance in medical applications requiring navigation through narrow channels, such as the ureter. Further optimization is proposed to enhance control and performance in more complex biological environments.
Supplementary Information:
The online version contains supplementary material available at 10.1007/s12213-025-00188-1.
More Related Videos

Related Concept Videos
 01:17
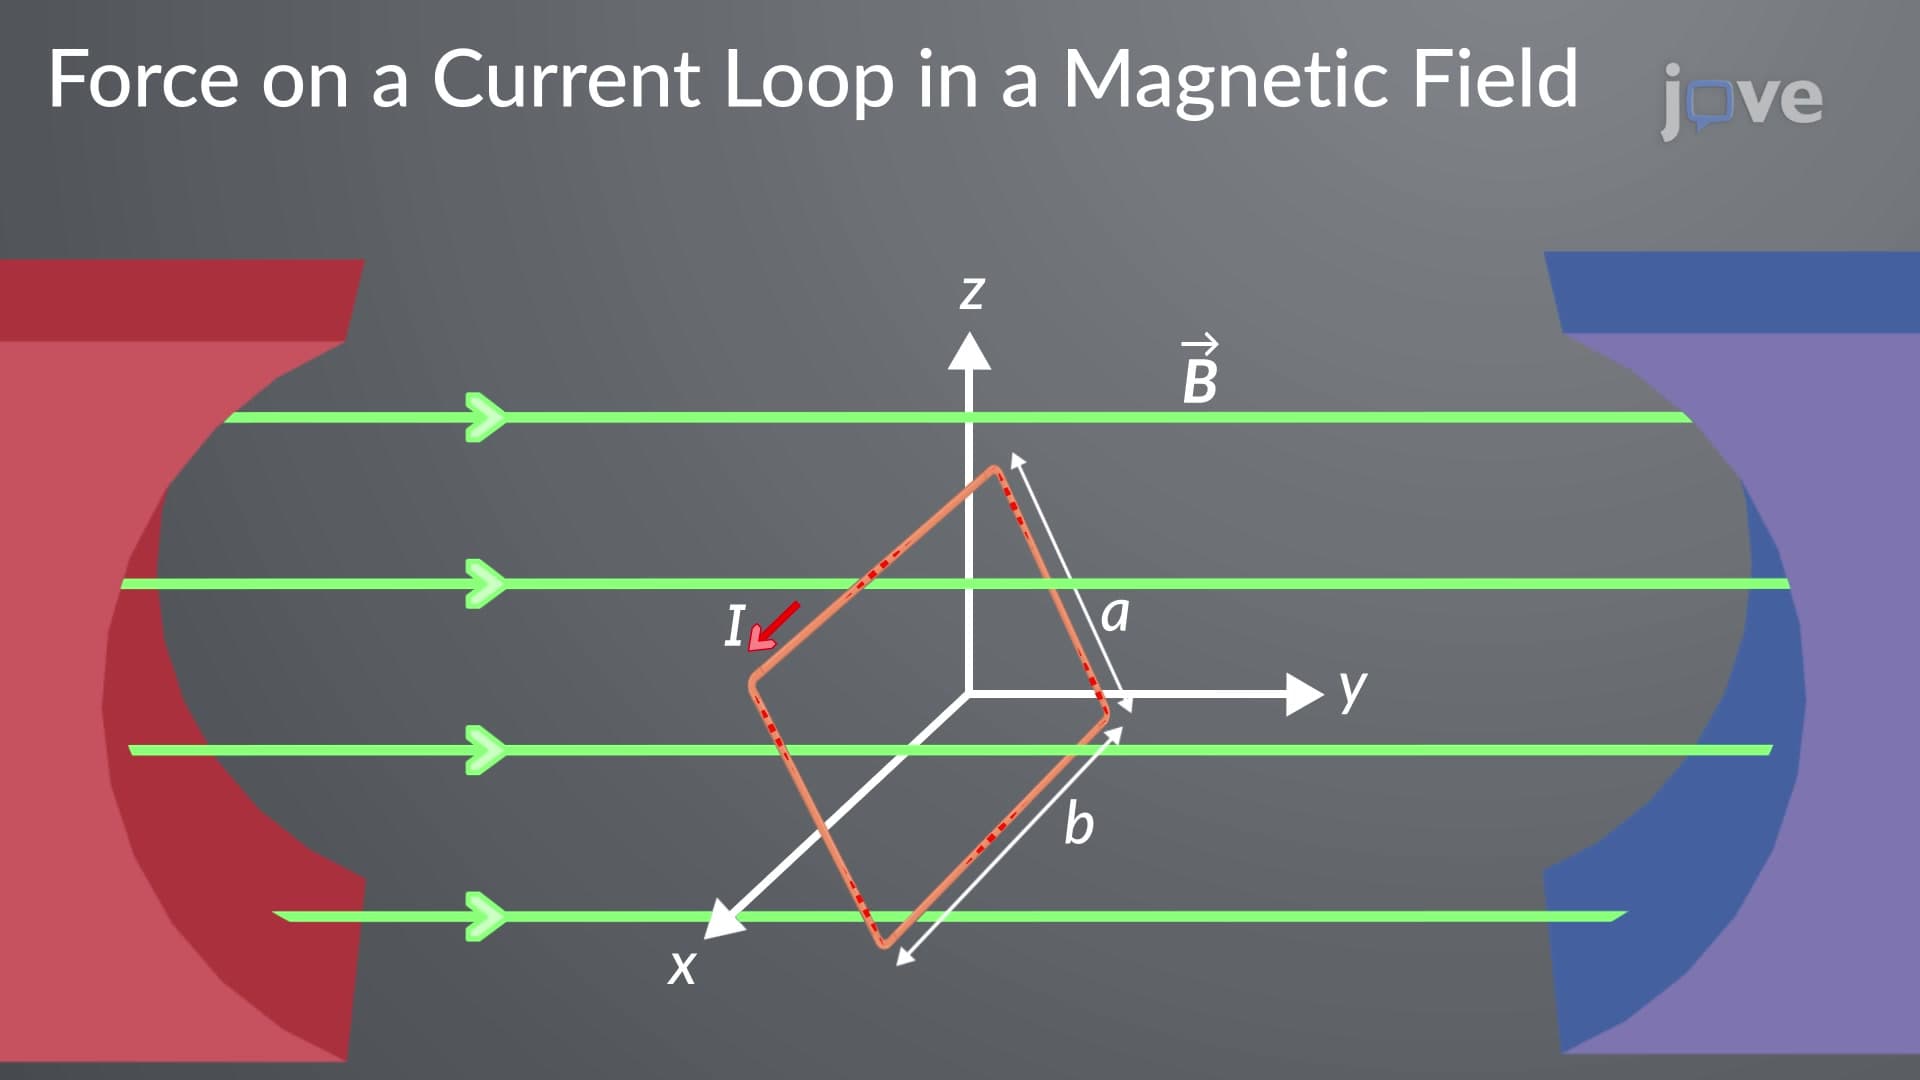
Force On A Current Loop In A Magnetic Field
 01:13
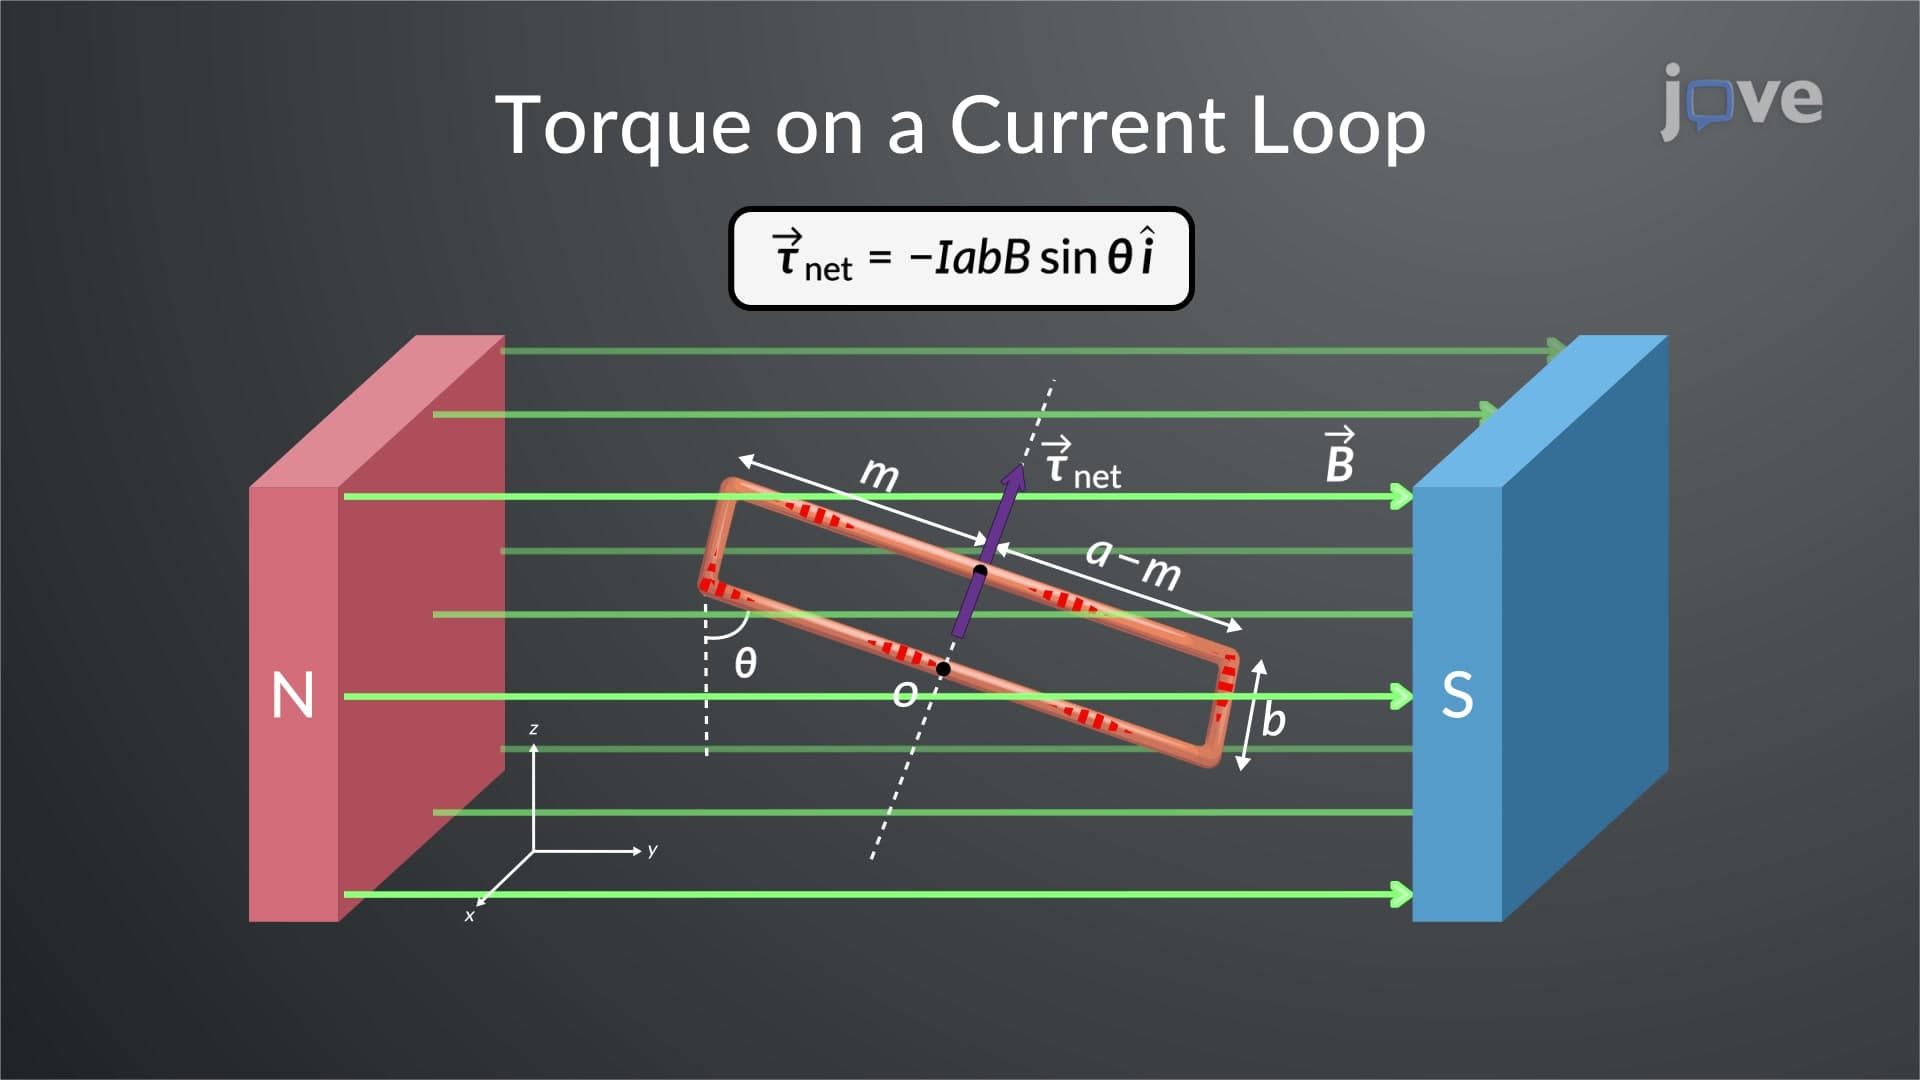
Torque On A Current Loop In A Magnetic Field
Consider a rectangular current-carrying loop containing N turns of wire, placed in a uniform magnetic field. The net force on a current-carrying loop...
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:15
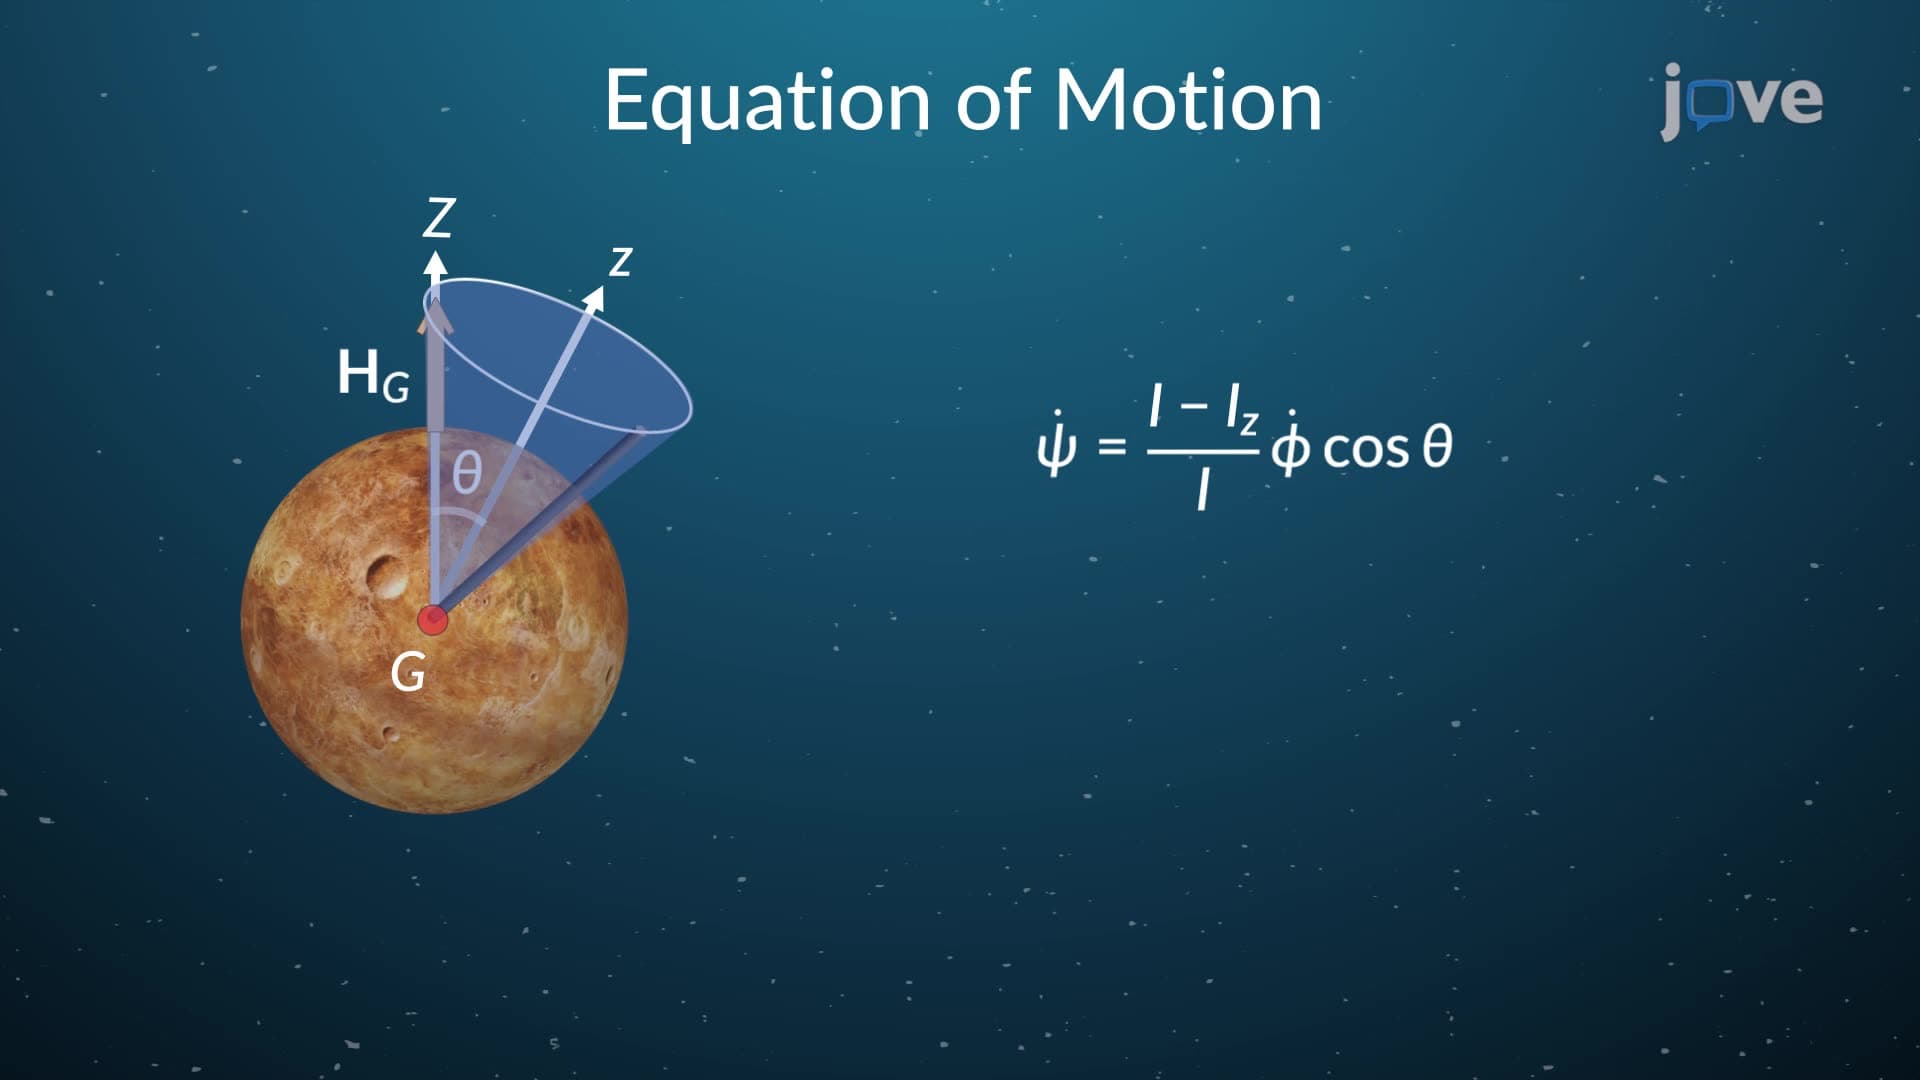
Torque Free Motion
 01:22
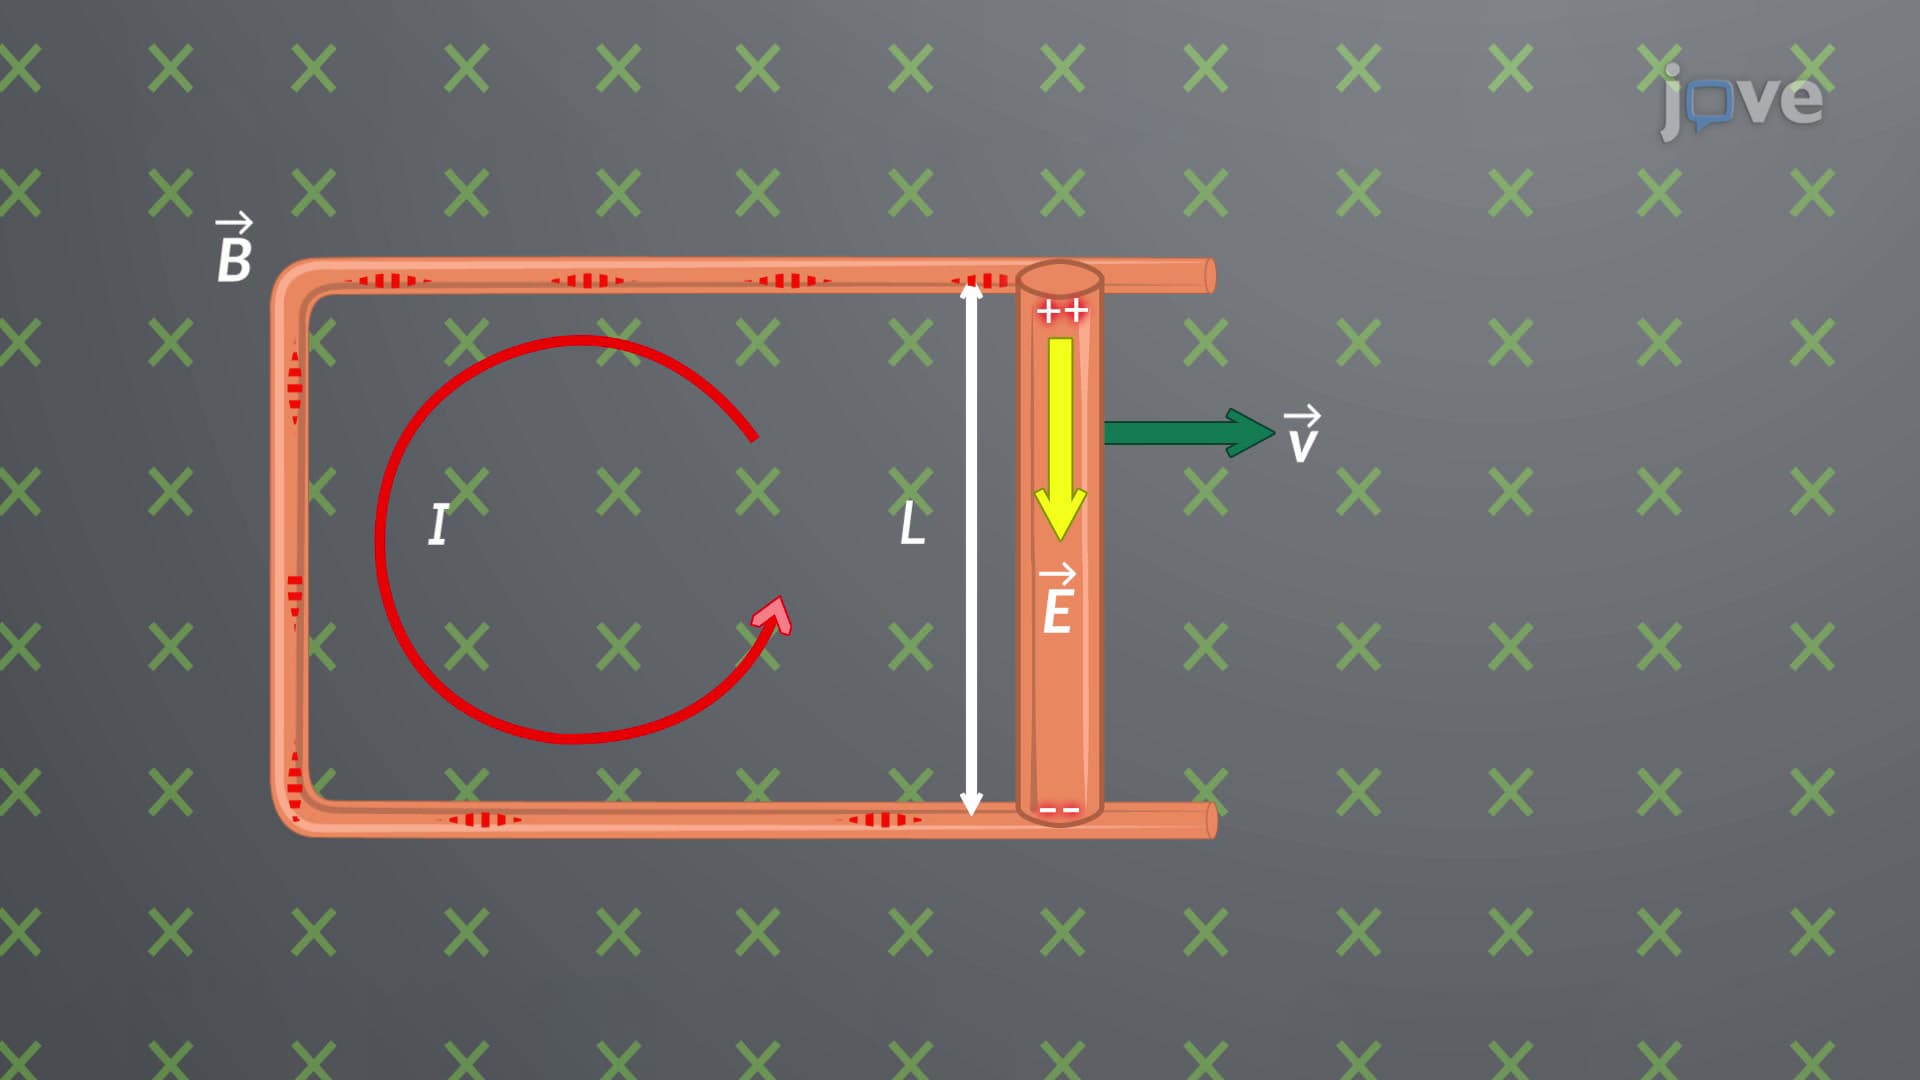
Motional Emf
 01:22
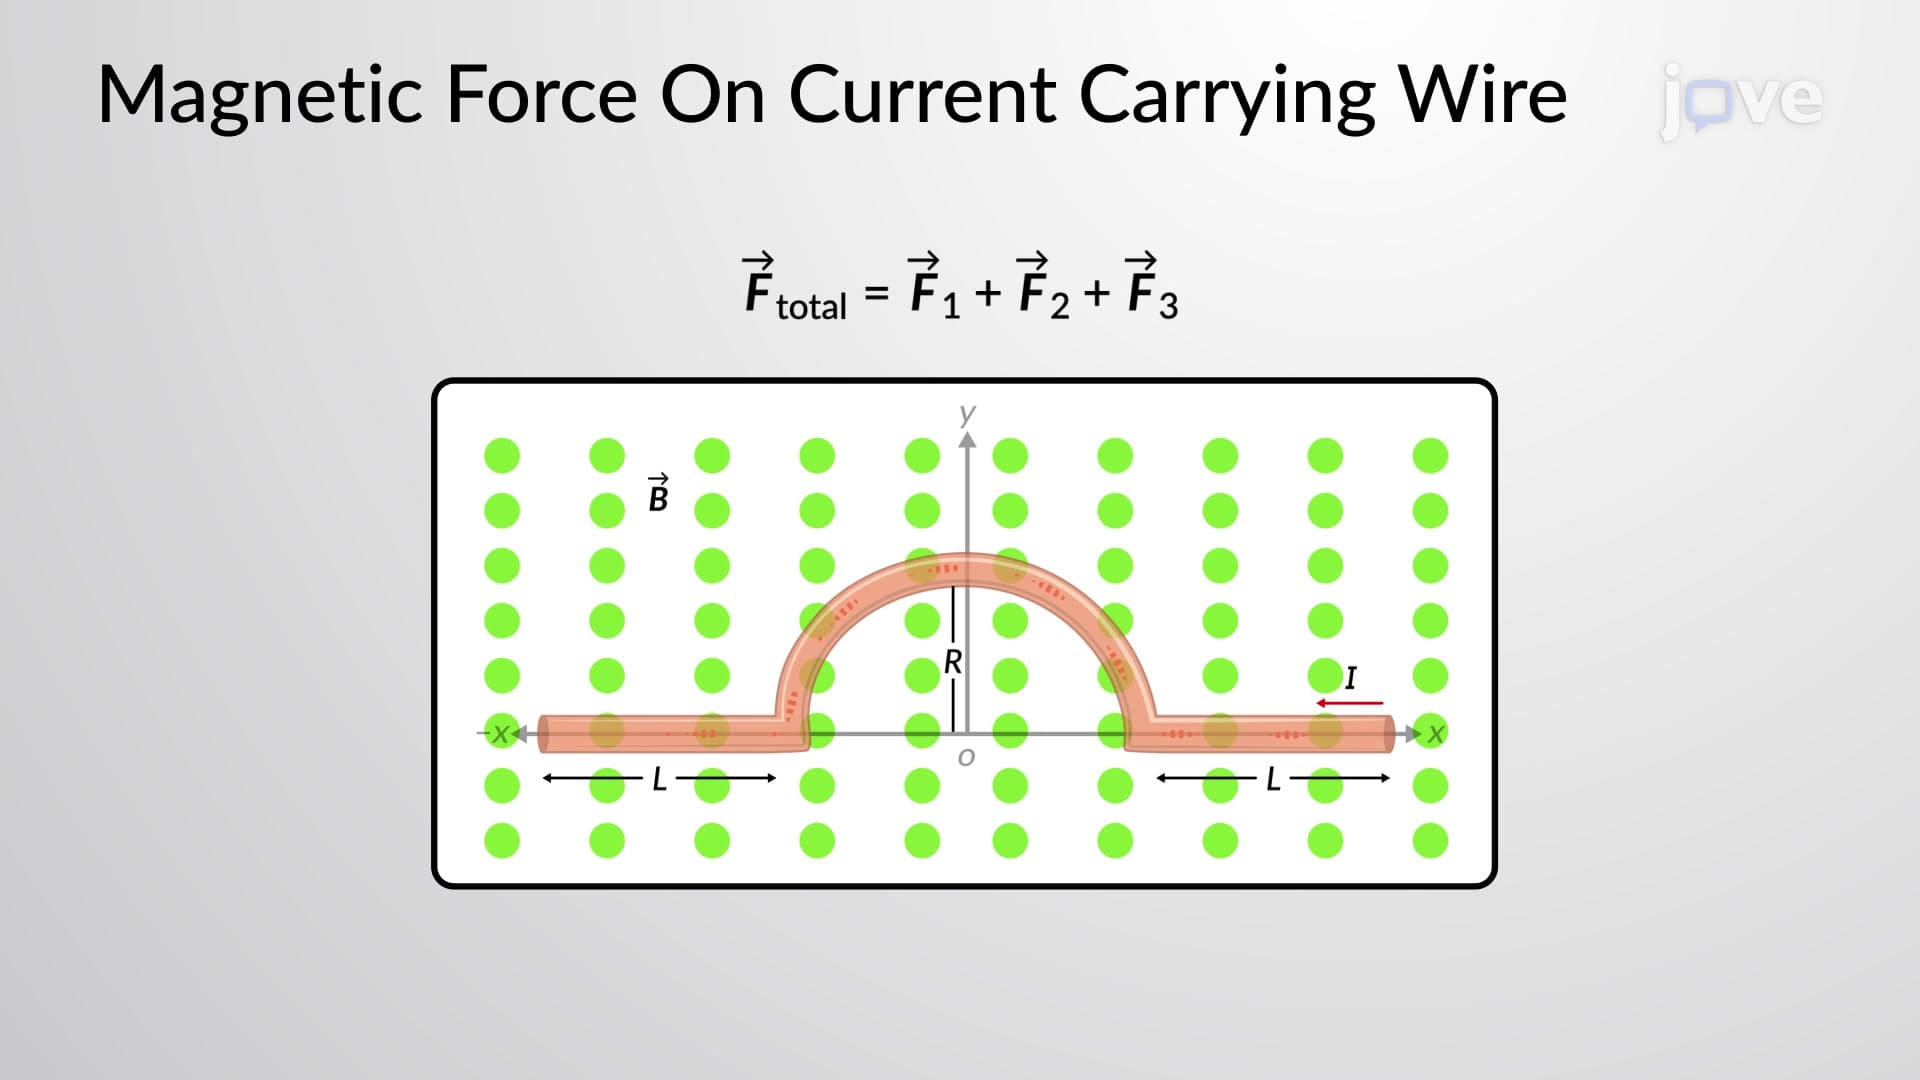
Magnetic Force On Current-Carrying Wires: Example