Related Experiment Video
Updated: Sep 18, 2025


Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot
Published on: June 10, 2020
Bio-Inspired Compliant Joints and Economic MPC Co-Design for Energy-Efficient, High-Speed Locomotion in Snake-like
Shuai Zhou1, Gengbiao Chen1, Mingyu Gong2
1College of Mechanical and Vehicle Engineering, Changsha University of Science and Technology, Changsha 410114, China.

Abstract:
Snake-like robots face critical challenges in energy-efficient locomotion and smooth gait transitions, limiting their real-world deployment. This study introduces a bio-inspired compliant joint design integrated with a hierarchical neural oscillator network and an energy-optimized control framework. The joint mimics biological skeletal flexibility using specialized wheeled mechanisms and adaptive parallel linkages, while the control network enables adaptive gait generation and seamless transitions through a phase-smoothing algorithm. Critically, this work adopts a synergistic design philosophy where mechanical components and control parameters are co-optimized through shared dynamic modeling. The proposed predictive control strategy optimizes locomotion speed while minimizing energy consumption. Experimental simulations demonstrate that the method achieves an 18% higher average forward speed (0.0563 m/s vs. 0.0478 m/s) with 7% lower energy use (0.1952 J vs. 0.2107 J) compared to conventional approaches. Physical prototype testing confirms these improvements under real-world conditions, showing a 12.9% speed increase (0.0531 m/s vs. 0.0470 m/s) and 7.3% energy reduction (0.2147 J vs. 0.2317 J). By unifying mechanical flexibility and adaptive control parameter tuning, this work bridges dynamic performance and energy efficiency, offering a robust solution for unstructured environments.


Related Concept Videos
 01:07
Development of the Limb Synovial Joints
The mesenchymal stem cells differentiate into chondrocytes that form the hyaline cartilage, and later the cartilaginous model of the bone. This model further transforms into a bone. This process is known as endochondral ossification.
During development, the limbs...
 01:22
Mechanical Systems
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:22
Indirect Motor Pathways
The vestibulospinal tract originates in the vestibular nuclei of the brainstem. The vestibular system detects changes in...
 01:14
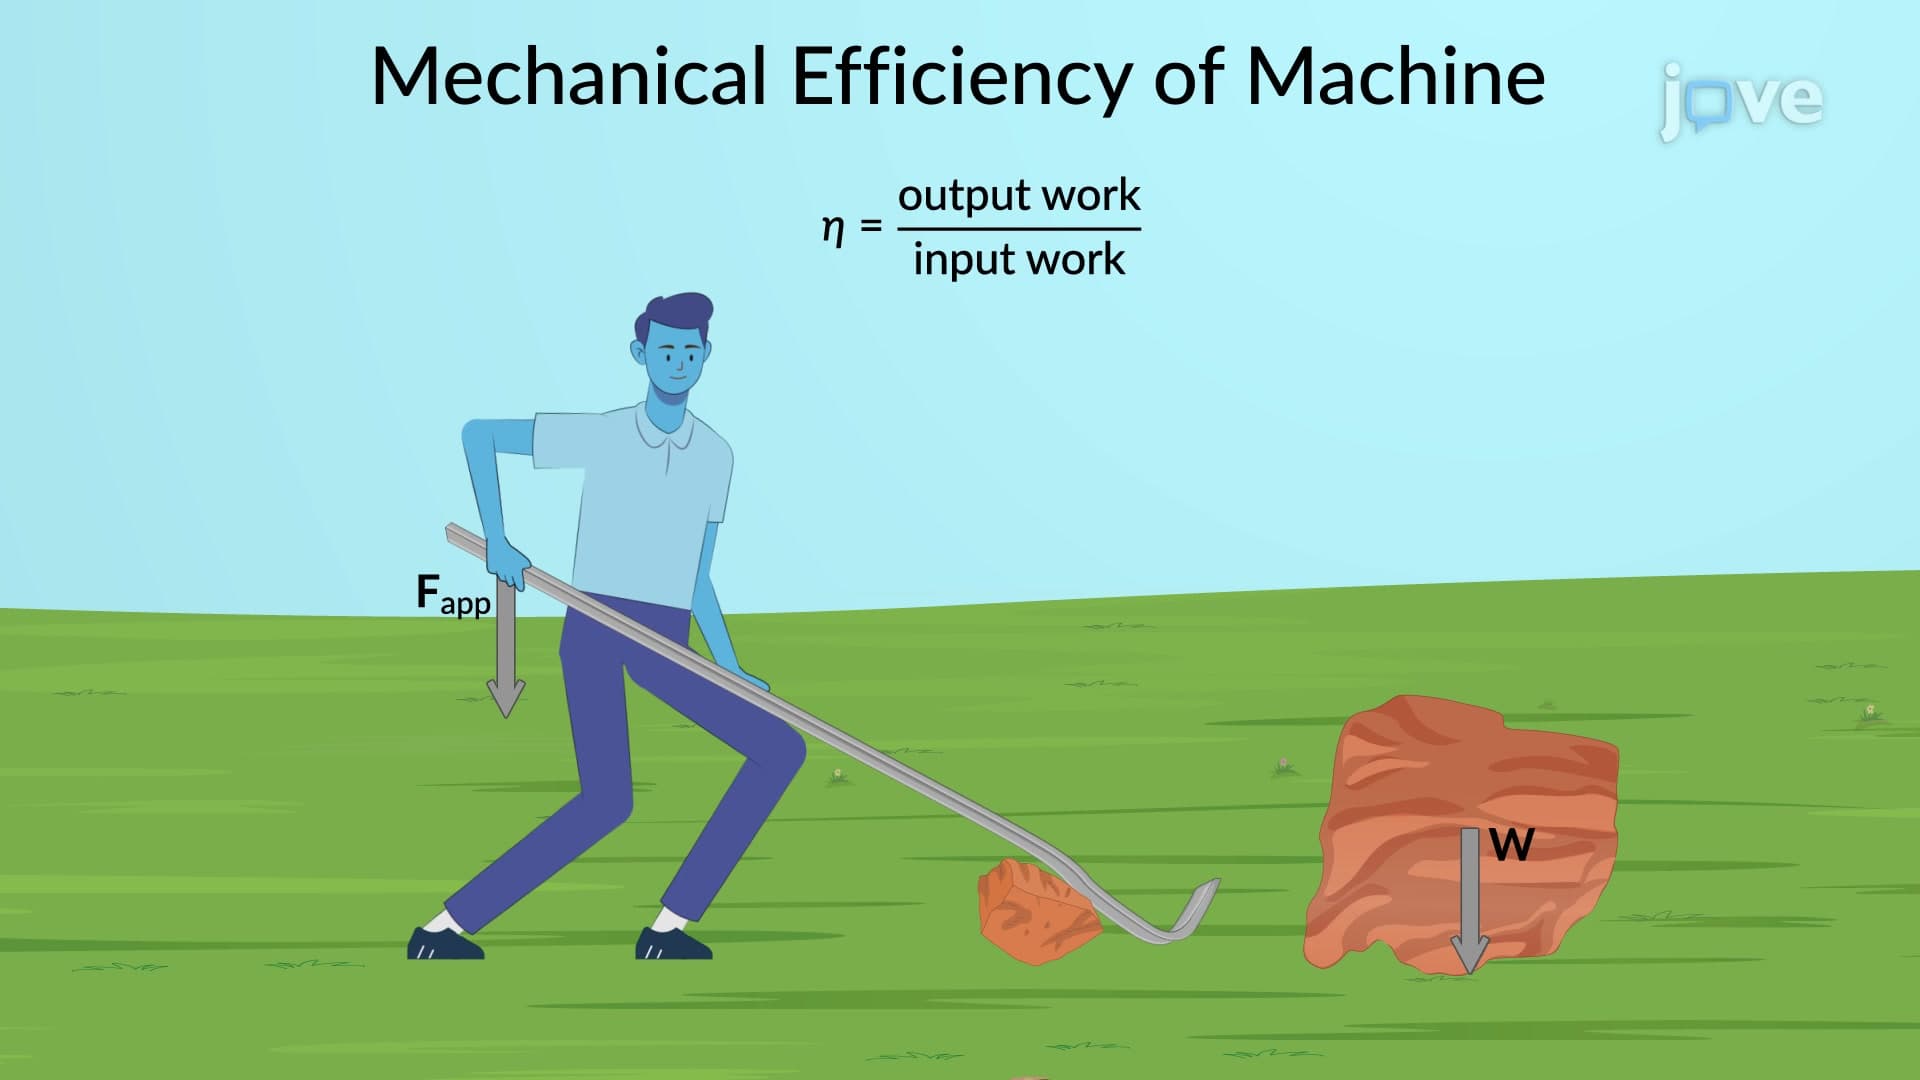
Mechanical Efficiency of Real Machines
However, in reality, no machine can be truly ideal, and all of them experience some...