Related Experiment Video
Updated: Sep 17, 2025


Rod-based Fabrication of Customizable Soft Robotic Pneumatic Gripper Devices for Delicate Tissue Manipulation
Published on: August 2, 2016
An ultralight, tiny, flexible six-axis force/torque sensor enables dexterous fingertip manipulations
Qian Mao1, Zijian Liao1, Shiqiang Liu1
1State Key Laboratory of Precision Measurement Technology and Instruments, Department of Precision Instrument, Tsinghua University, Beijing, China.

Abstract:
Multi-dimensional mechanoreceptors are crucial for both humans and robots, providing omnidirectional force/torque senses to ensure dexterous and precise manipulations. Current six-axis force/torque sensors are bulky, heavy, and rigid with complicated sensing structures and high-cost manufacture. Although flexible force sensors have emerged recently, their perceptive dimension and performance are limited and still unsatisfactory for practical applications. Here, we propose an ultralight (0.30 g), tiny (fingertip size), and flexible six-axis force/torque sensor with a simple structure and low-cost fabrication. The sensor accurately perceives six-dimensional force/torque via capturing the spatial strain field of an elastic piezo-thermic material utilizing web-like scattered thin-film thermoreceptors. Integrating the sensor on the fingertip of humans or robots, we or robots can dexterously manipulate objects (e.g., open bottle cap), play games, and accomplish human-robot collaborative operations via easy fingertip-touch, demonstrating a broad prospect in applications of helping disabled and elderly people, intelligent robots, and virtual reality.

Related Concept Videos
 01:30
Three-Dimensional Force System
 01:15
Torque Free Motion
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:02
Gyroscope
 01:20
Two-Dimensional Force System
 01:05
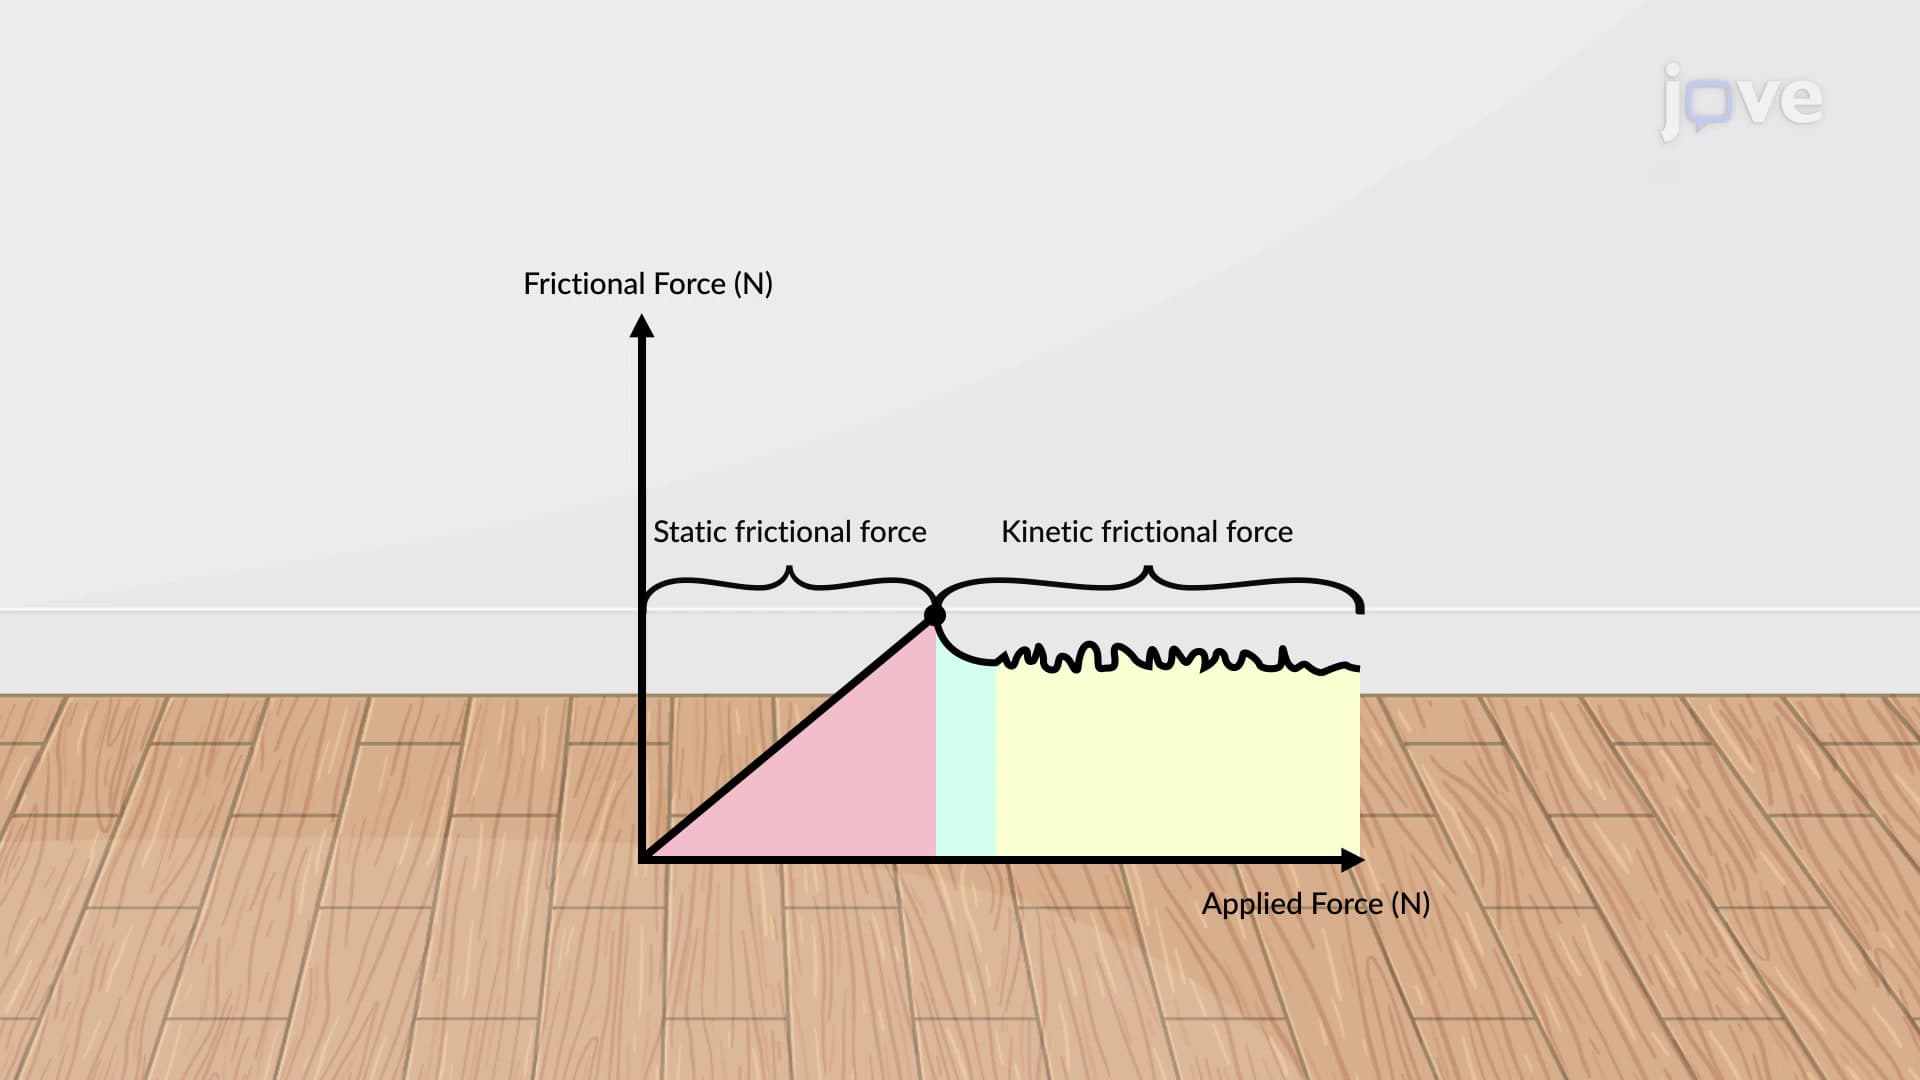
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...