Related Experiment Video
Updated: Sep 16, 2025

An Analog Macroscopic Technique for Studying Molecular Hydrodynamic Processes in Dense Gases and Liquids
Published on: December 4, 2017
Gross-Pitaevskii systems of fractional order with respect to multicomponent solitary wave dynamics
Muhammad Bilal1, Yazen M Alawaideh2, Shafqat Ur Rehman3
1Department of Physics, Shanghai University, Shanghai, 200444, China.

Abstract:
This study presents a comparative analysis of the fractional Gross-Pitaevskii equation (GPE), a fundamental nonlinear Schrödinger-type model, focusing on the derivation of exact soliton solutions critical for understanding nonlinear phenomena such as superfluidity and superconductivity. We compare the effectiveness of β-fractional and M-truncated fractional derivatives in solving the complex fractional GPE. This comparison reveals that while both fractional derivatives enable the construction of diverse optical soliton solutions-including hyperbolic, periodic, Jacobi elliptic, and exponential forms-the β-derivative provides smoother soliton profiles with computational simplicity, whereas the M-truncated derivative captures richer oscillatory dynamics due to its enhanced memory effects. Employing advanced analytical tools-namely the generalized extended direct algebraic method (gEDAM) and the Kummar-Malik (KM) method-along with Wolfram Mathematica for verification, we extract and rigorously validate a variety of exact solutions. The generated solutions and their corresponding wave profiles under varying parameters highlight the distinct physical implications of each fractional derivative approach. Our results offer a robust framework for modeling nonlinear fractional dynamics, with applications spanning optical fibers, plasma physics, mathematical physics, and condensed matter systems. The comparative insights gained deepen the understanding of fractional-order effects in nonlinear wave evolution, paving the way for further exploration in complex physical systems.
Related Concept Videos
 01:18
Second Order systems II
 01:20
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:21
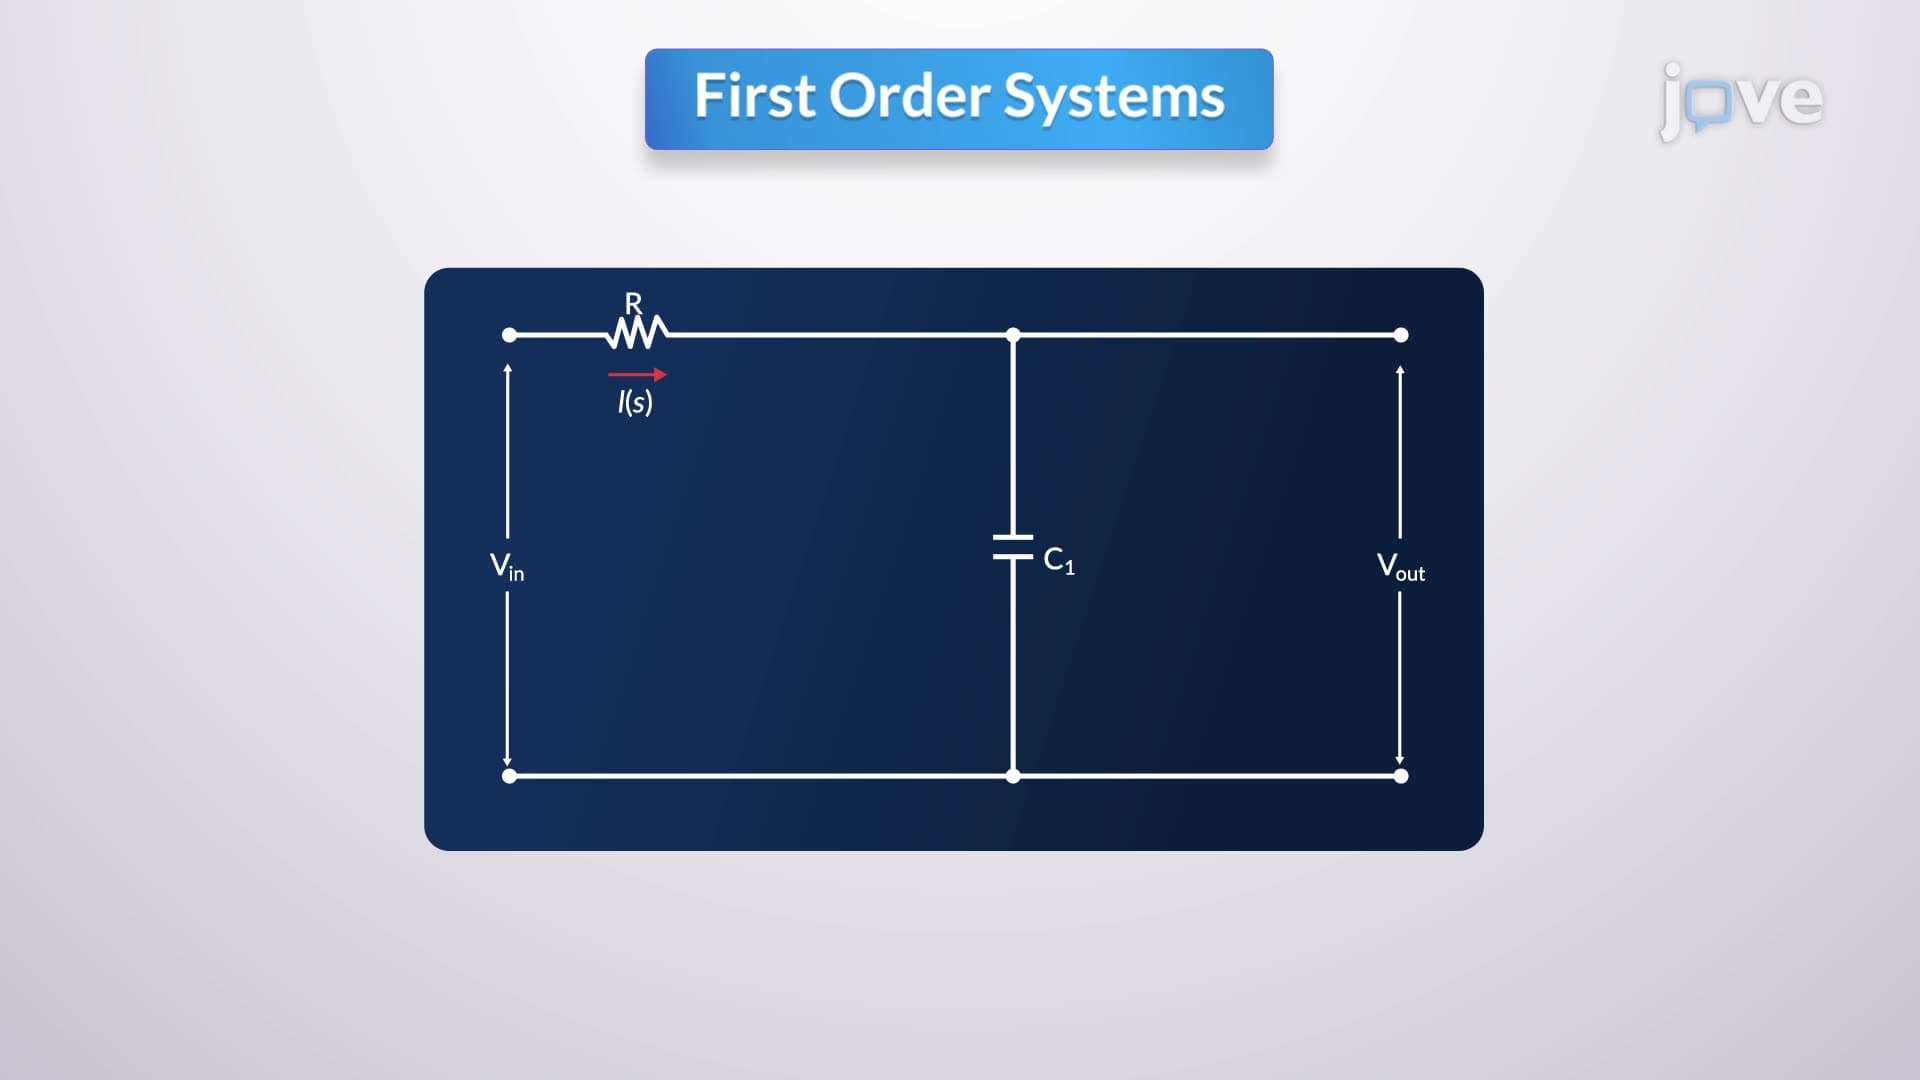
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:02
Equations of Wave Motion