Related Experiment Video
Updated: Sep 16, 2025
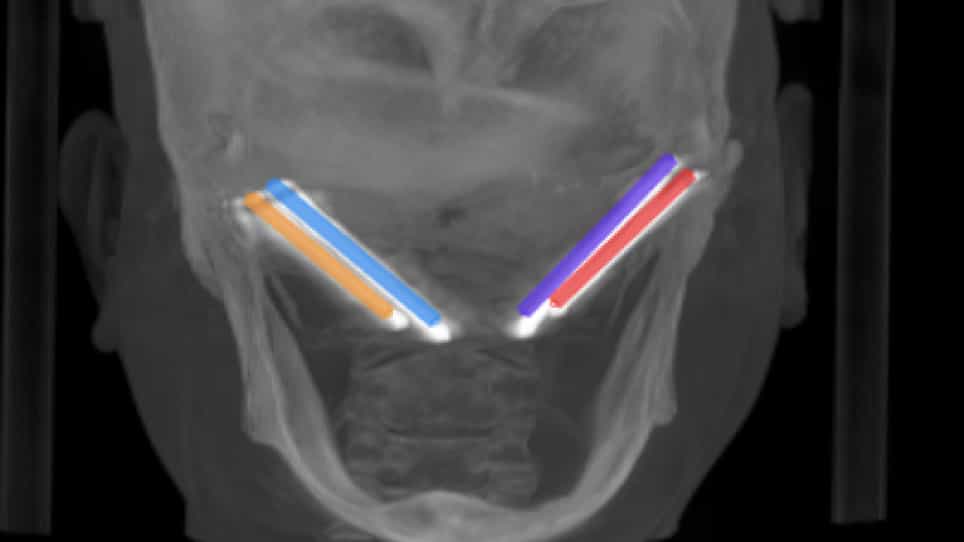

Real-Time Dynamic Navigation System for the Precise Quad-Zygomatic Implant Placement in a Patient with a Severely Atrophic Maxilla
Published on: October 18, 2021
Optimized design of a tooth-simulating screw for enhanced accuracy in robot-assisted implant placement in completely
Yulan Wang1, Jiaxian Chen2, Yufeng Zhang3
1Lecturer, State Key Laboratory of Oral & Maxillofacial Reconstruction and Regeneration, Key Laboratory of Oral Biomedicine Ministry of Education, Hubei Key Laboratory of Stomatology, Department of Oral Implantology, School & Hospital of Stomatology, Wuhan University, Wuhan, PR China.

Statement Of Problem:
The absence of natural teeth in computer-assisted complete arch implant surgery presents challenges as natural teeth as anatomic landmarks are lacking.
Purpose:
The purpose of this in vitro study was to evaluate implant placement accuracy using a robotic-assisted system with a novel tooth-simulating screw simulating natural teeth and optimizing their distribution in a completely edentulous jaw model.
Material And Methods:
A total of 12 identical 3-dimensionally (3D) printed models were used, with 4 implants placed in each. The models were divided into 4 groups based on the number (3 or 4) and distribution (dispersed or localized) of tooth-simulating screws. Cone beam computed tomography (CBCT) data of the tooth-simulating screw in a mandible model were imported into a robotic planning software program for registration, implants were placed under full robotic guidance, and deviations between planned and actual positions were measured by superimposing pre-operative and postoperative CBCT data. All measurements were recorded as absolute values and presented as mean ±standard deviation. Two-way ANOVA was used for data analyses.
Results:
The use of the tooth-simulating screw to assist registration and tracker fixation resulted in high accuracy. No significant differences were observed among the groups in terms of platform and apex deviation (P>.05); however, angular deviation was affected (P<.05). Tooth- simulating screws in a dispersed distribution demonstrated a significantly lower angular deviation compared with localized groups. Among the dispersed groups, 3 tooth-simulating screws (0.50 ±0.19 degree) exhibited higher accuracy than 4 tooth-simulating screws (0.82 ±0.26 degree).
Conclusions:
The novel tooth-simulating screw used in robot-assisted implant surgery achieved high accuracy. Dispersed tooth-simulating screw placement led to higher accuracy.