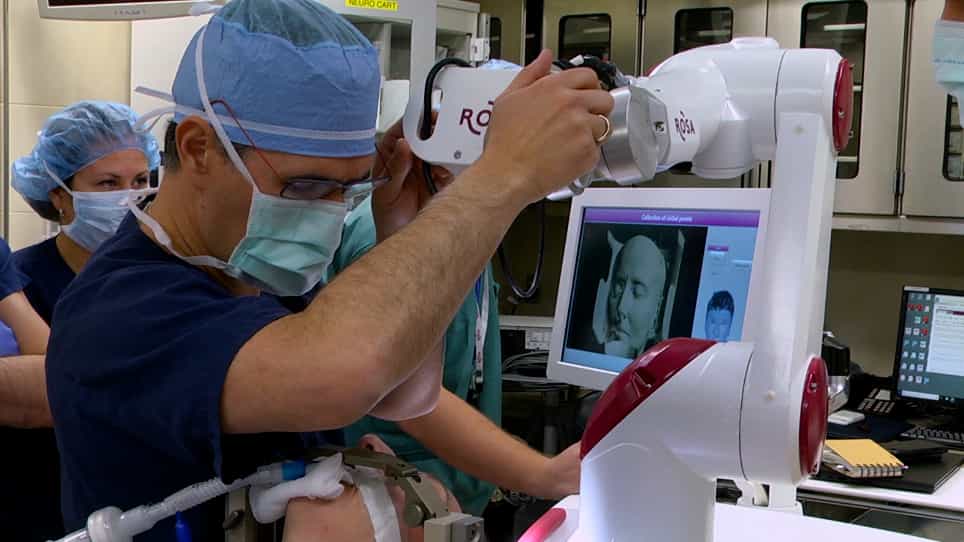
Accuracy of implant surgery planning and surgery with a dental robot in transcrestal sinus floor elevation
Related Experiment Video
Updated: Apr 3, 2026
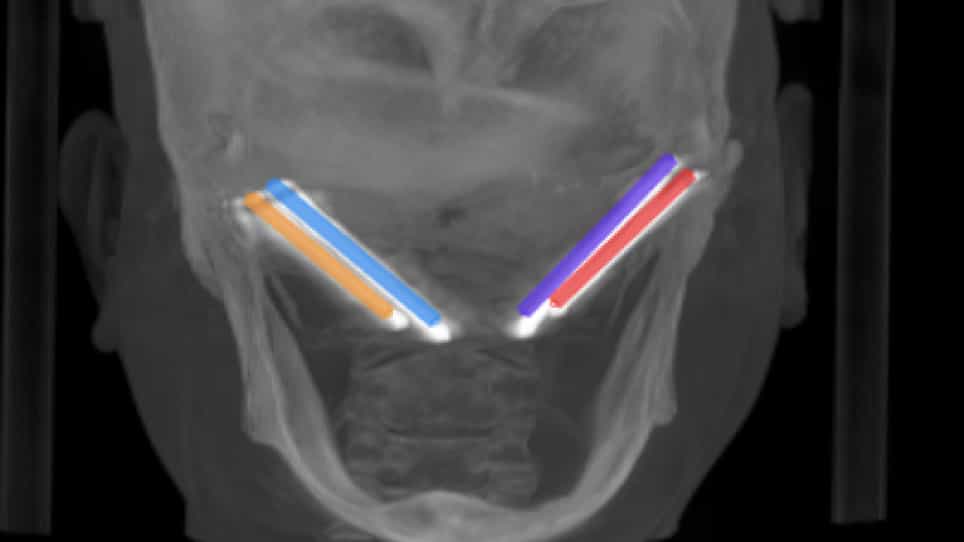
Real-Time Dynamic Navigation System for the Precise Quad-Zygomatic Implant Placement in a Patient with a Severely Atrophic Maxilla
Published on: October 18, 2021
Yulan Wang1,2, Yaoyu Zhao1,2, Jiaxian Chen1,2
1State Key Laboratory of Oral & Maxillofacial Reconstruction and Regeneration, Key Laboratory of Oral Biomedicine, Ministry of Education, Hubei Key Laboratory of Stomatology, School & Hospital of Stomatology, Wuhan University, Wuhan, China.

Purpose:
The present in vitro study aims to evaluate the potential of a dental robot to enhance implant accuracy in transcrestal sinus floor elevation (tSFE).
Materials And Methods:
Thirteen 3D-printed maxillary resin models were fabricated from patient data, with two models generated per patient-one allocated to the robotic group, where implant placement was planned and executed using the built-in surgical software, and one to the freehand group, where the surgeon manually placed the implant according to the position planned by the robotic system. Implant accuracy was evaluated by comparing the preoperative plan with postoperative scans, including deviations at the platform, apex, and angle, as well as the implant apex-sinus floor distance deviation. Meanwhile, the drill force was continuously monitored by the force feedback function of the robotic arm.
Results:
For positional deviation, the total deviation at the implant platform was 0.4323 ± 0.1304 mm in the robotic group and 0.8608 ± 0.2902 mm in the freehand group; the total deviation at the apex was 0.4815 ± 0.1338 mm in the robotic group and 1.292 ± 0.5275 mm in the freehand group, showing a significantly higher accuracy in the robotic group compared with the freehand group. Regarding angular deviation, the deviation in the robotic group was 1.239 ± 0.3176°, and in the freehand group was 4.938 ± 2.846°, p < 0.0001. Upon initial breakthrough of the sinus floor, three distinct force reduction points were observed, culminating in a complete drop to zero force at full perforation, after which the drill automatically retracted.
Conclusions:
Robotic computer-assisted implant surgery showed higher implant placement accuracy than freehand procedures in tSFE, while providing consistent haptic feedback.