Related Experiment Video
Updated: Sep 15, 2025
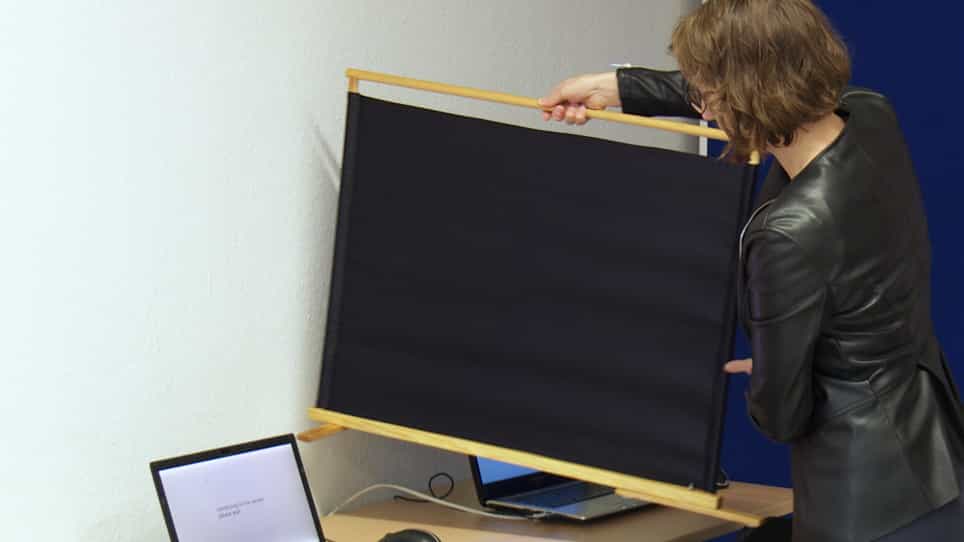

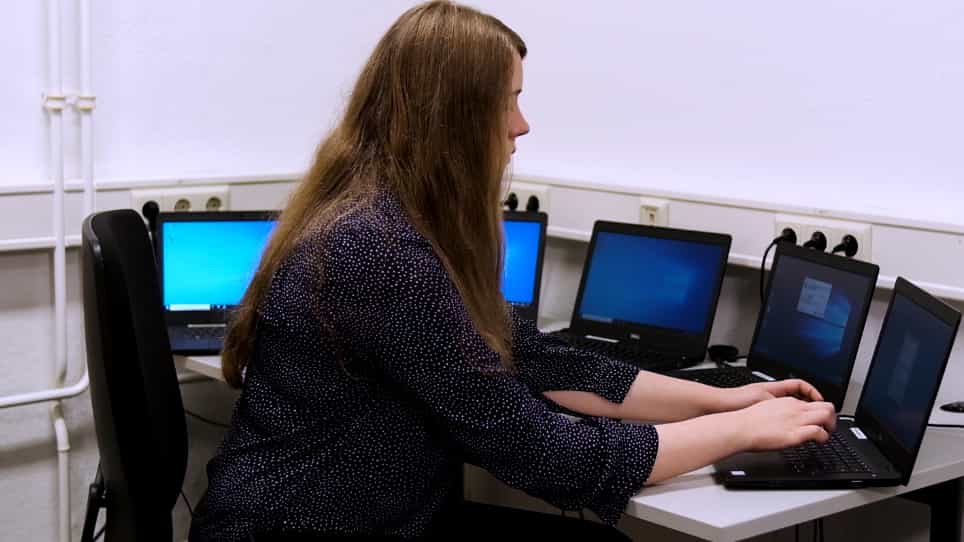
The HoneyComb Paradigm for Research on Collective Human Behavior
Published on: January 19, 2019
Multiagent Consensus Tracking Control Over Asynchronous Cooperation-Competition Networks

Abstract:
In nature, populations of organisms (e.g., wolves) exhibit a remarkable ability to coordinate their group actions, such as hunting prey or evading predators, despite the coexistence of cooperative and competitive interactions among individuals. Motivated by this intriguing phenomenon, this article investigates the cooperative consensus tracking control problem of multiagent systems (MASs) over cooperation-competition networks with asynchronous communications. That is, all followers can simultaneously achieve trajectory tracking of the leader agent, even if there exist competitive interactions between the followers and the leader. To portray the cooperation and competition level among agents, a new distance-based weight function is designed, which is more flexible than the fixed weight values in existing research works. Theoretically, the sufficient conditions for achieving consensus tracking control are obtained based on the convergence analysis method of infinite products of super-stochastic matrices. Finally, some numerical simulations are given to verify the effectiveness of the proposed consensus tracking control scheme.

Related Concept Videos
 01:14
Agonism and Antagonism: Quantification
To quantify these effects, researchers use a dose-response curve, which provides valuable information about the potency and efficacy of a drug. Potency refers to...
 01:21
Distributed Loads: Problem Solving
 01:24
Sequence Networks of Rotating Machines
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...
 01:58
Cooperative Allosteric Transitions
 01:25
Distribution Reliability and Automation
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...