Related Experiment Video
Updated: Jul 7, 2026
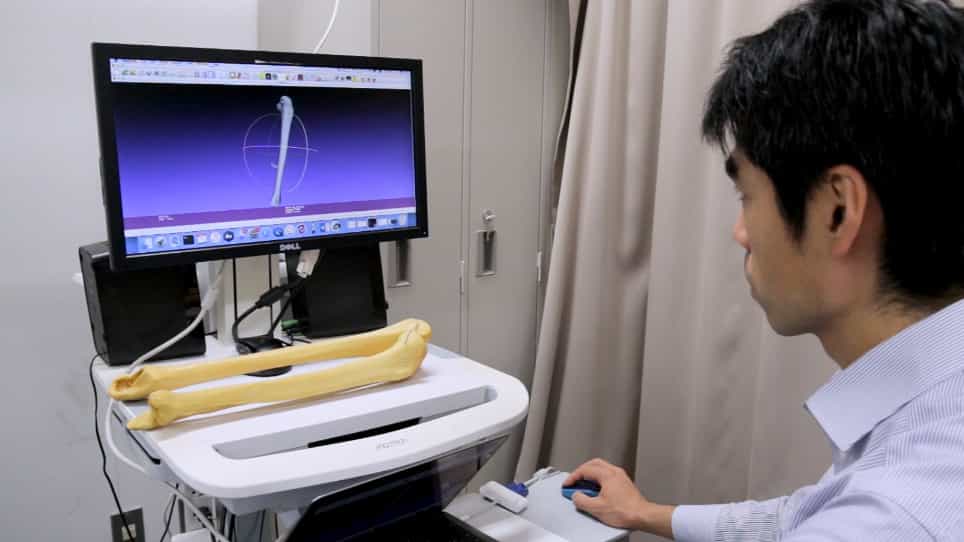

Four-Dimensional CT Analysis Using Sequential 3D-3D Registration
Published on: November 23, 2019
Cross-Modality Registration using Bone Surface Pointcloud for Robotic Ultrasound-Guided Spine Surgery
Xihan Ma1, Xiao Zhang2, Yang Wang1
1Department of Robotics Engineering, Worcester Polytechnic Institute, 100 Institute Rd., Worcester, MA 01609, USA.

Abstract:
Image guidance using preoperative magnetic resonance imaging (MRI) and intraoperative ultrasound (US) can improve the outcome of spine surgery. Employing a robotic US system (RUSS) allows the automated acquisition of large 3D US volumes, facilitating accurate registration. However, such registration remains challenging due to the cross-modality discrepancy. To address this issue, we present a pipeline that extracts spine pointclouds from MRI and 3D US to perform per-vertebra registration. Experiments showed a registration accuracy of 1.82 mm in terms of residual root mean square error and 7.02 mm in terms of Chamfer distance. The pipeline exhibits superior robustness to suboptimal initial conditions compared with the two baseline methods. It also demonstrated good time efficiency under real-time conditions, demonstrating the potential applicability in RUSS-guided spine surgeries.

Related Concept Videos
 01:40
Bone Remodeling
 01:31
Bone Remodeling and Repair