Related Experiment Video
Updated: Sep 14, 2025

Large Scale Energy Efficient Sensor Network Routing Using a Quantum Processor Unit
Published on: September 8, 2023
Event-Based Integral Sliding-Mode Consensus Control for Networked Multiagent Systems With State Quantization

Abstract:
This article focuses on the issue of the quantization-based event-triggered integral sliding-mode controller design for networked multiagent systems (MASs) encountering interferences under limited network bandwidth. An integral sliding manifold (ISM) is designed to address the effect of disturbances and ensure the desired dynamic performance of the system. We establish an event-triggered mechanism (ETM) with an exponential decay rate to conserve the limited communication resources. Then, a uniform quantizer is added to quantify the triggered state signals to lessen the network transmission burden caused by the digital network. Combining the designed ETM with a static uniform quantizer, the quantized trigger state signals are sent to decoders through the digital network to construct a quantized ISM. Subsequently, an event-triggered integral sliding-mode controller under quantization technology is developed to ensure the asymptotic average consensus of networked MASs. By testifying that every network agent has a lower positive bound, the viability of the proposed ETM is demonstrated, thereby ensuring the absence of Zeno behavior. Eventually, two simulation examples are proffered to confirm the efficacy of the quantization feedback-based event-triggered sliding-mode control methodology.


Related Concept Videos
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:22
Multi-input and Multi-variable systems
In the absence...
 01:10
Propagation of Uncertainty from Systematic Error
 01:21
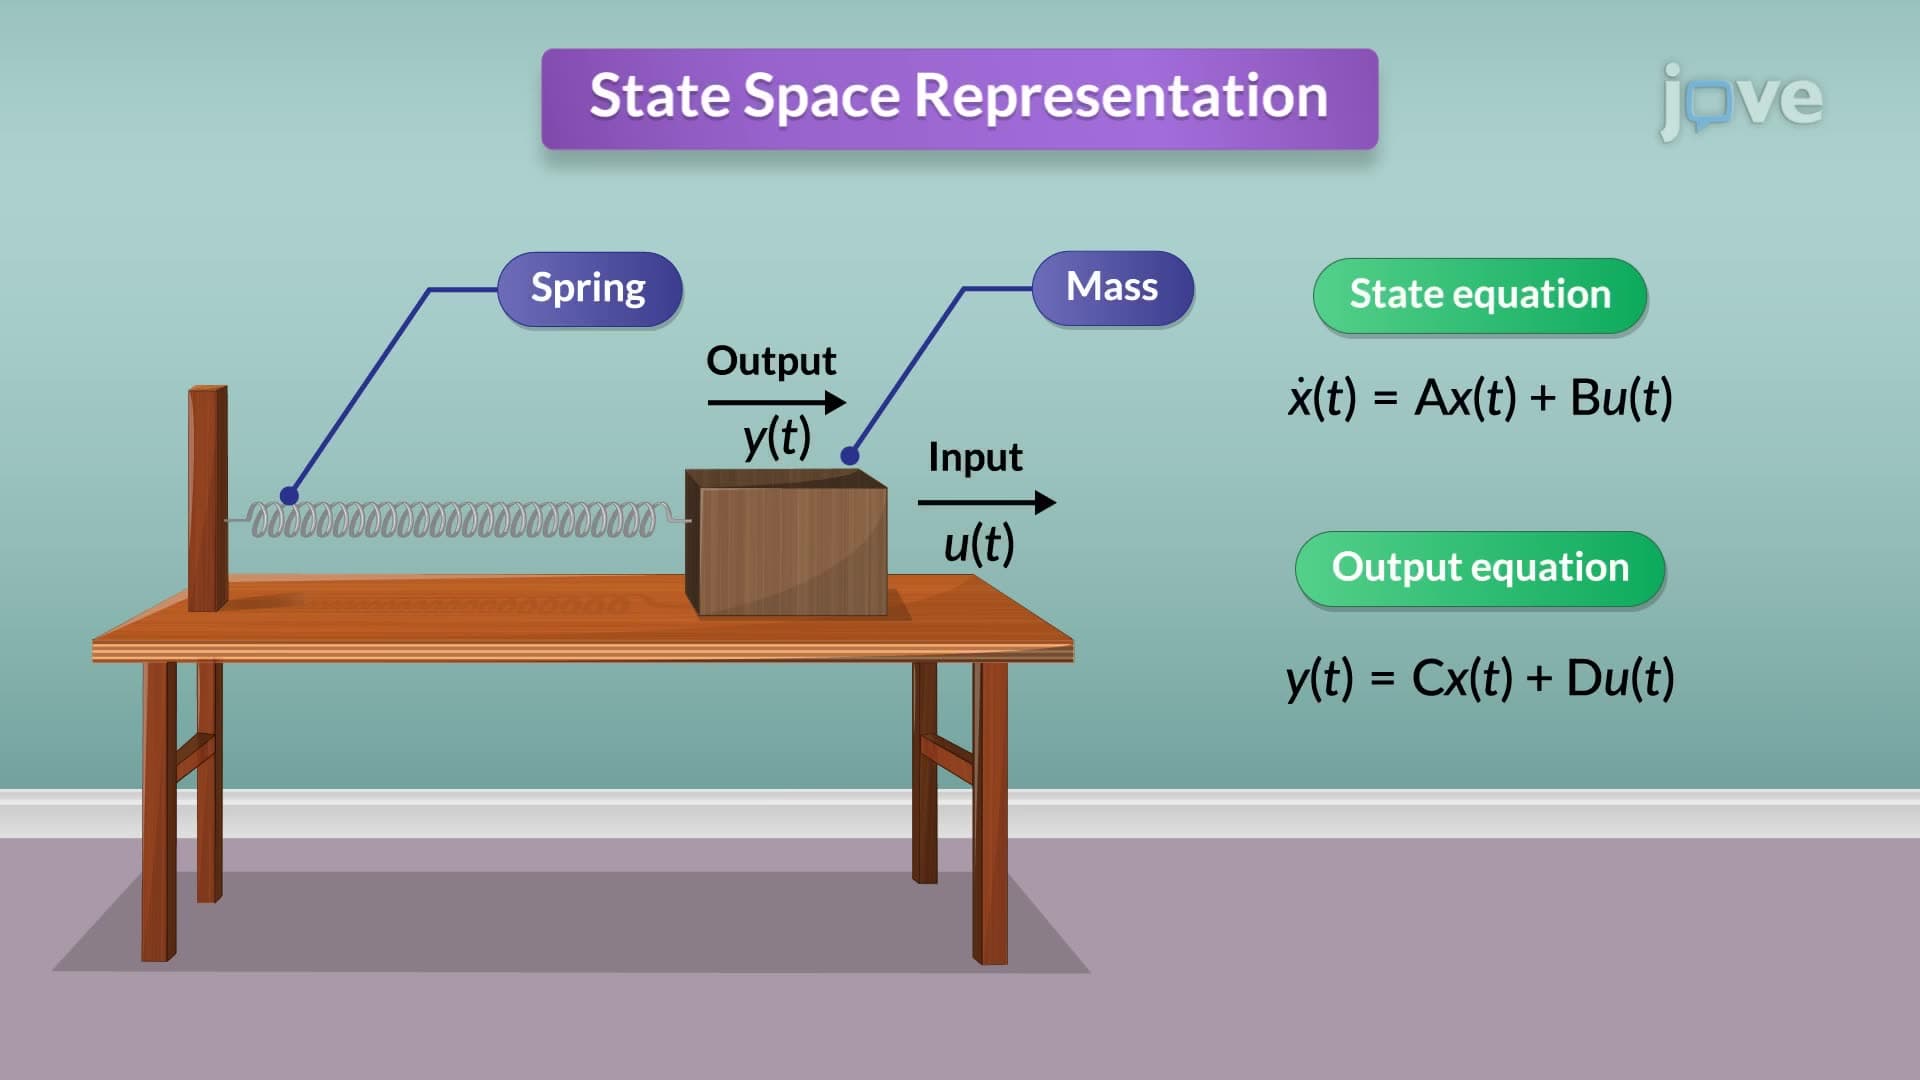
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 00:59
Propagation of Uncertainty from Random Error