Related Experiment Video
Updated: May 5, 2026
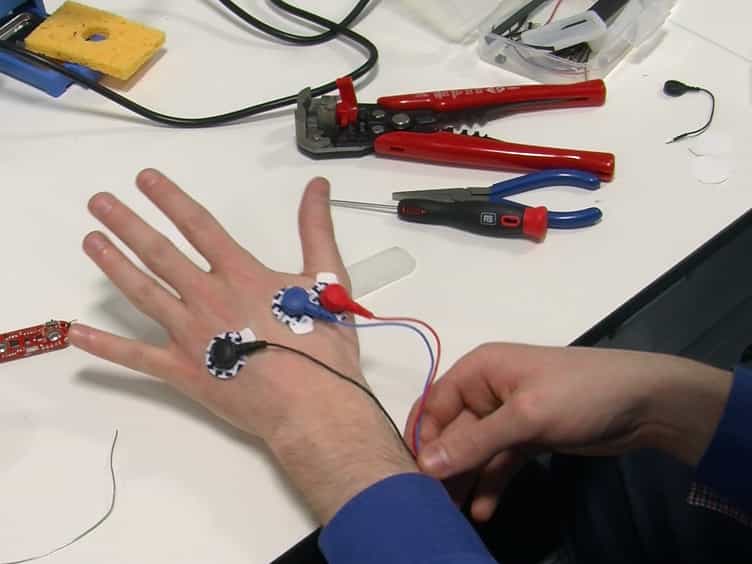

The Bionic Clicker Mark I & II
Published on: August 14, 2017
Slip-actuated bionic tactile sensing system with dynamic DC generator integrated E-textile for dexterous robotic
Vashin Gautham1,2, Ashutosh Panpalia1,2, Hamid Manouchehri1
1Department of Mechanical and Aerospace Engineering, University at Buffalo, The State University of New York, Buffalo, NY, USA.

Abstract:
Dexterous manipulation in robotics requires coordinated sensing, signal processing, and actuation for real-time, precise object control. Despite advances, the current artificial tactile sensory system lacks the proficiency of the human sensory system in detecting multidirectional forces and multimodal stimuli. To address this limitation, we present a bio-inspired "slip-actuated" tactile sensing system, incorporating dynamic direct-current generator into stretchable electronic textile. This self-powered bionic tactile sensing system operates in conjunction with a normal force sensor, paralleling the functions of human rapid-adapting and slow-adapting mechanoreceptors, respectively. Furthermore, we tailor and integrate the bionic tactile sensing system with robotic fingers, creating a bionic design that mimics human skin and skeleton with mechanoreceptors. By embedding this system into the feedback loop of robotic fingers, we are able to achieve fast slip and grasp monitoring, as well as effective object manipulation. Moreover, we perform quantitative analysis based on Hertzian contact mechanics to fundamentally understand the dependency of output on force and velocity in our sensor system. The results of this work provide an artificial tactile sensing mechanism for AI-driven smart robotics with human-inspired tactile sensing capabilities for future manufacturing, healthcare, and human-machine interaction.


