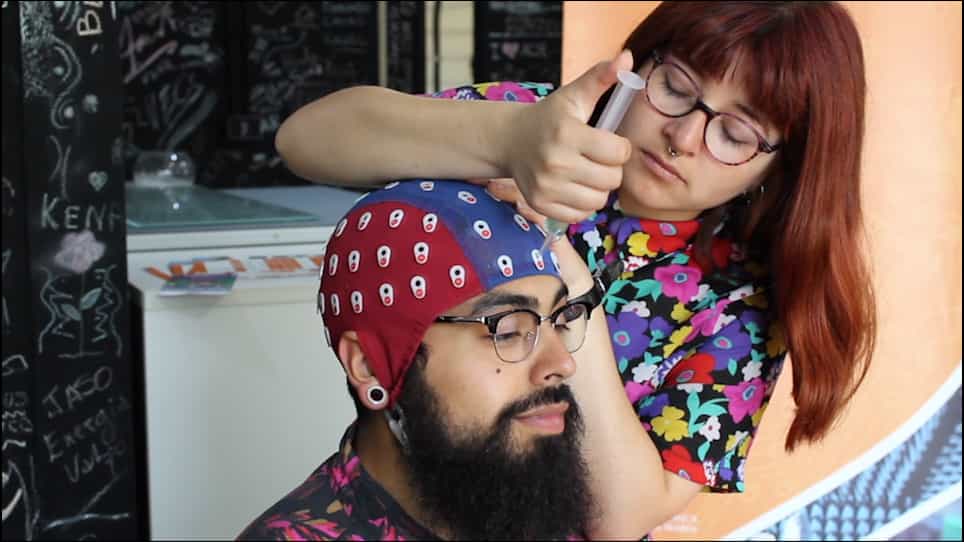
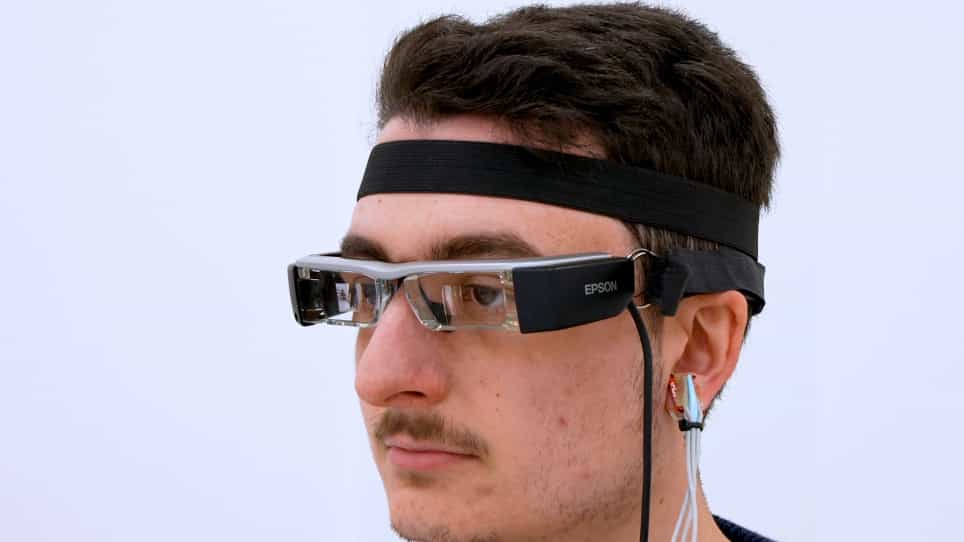
Related Experiment Video
Updated: May 10, 2026

SSVEP-based Experimental Procedure for Brain-Robot Interaction with Humanoid Robots
Published on: November 24, 2015
Leveraging low-frequency components for enhanced high-frequency steady-state visual evoked potential based brain
Yixin Chen1,2, Ren Xu3, Andrew Ty Lau4
1East China University of Science and Technology, Shanghai, 200237 China.

Abstract:
High-frequency steady-state visual evoked potential-based brain-computer interface (SSVEP-BCI) systems offer improved user comfort but suffer from reduced performance compared to their low-frequency counterparts, limiting their practical application. To address this issue, we propose a transfer learning-based method that leverages low-frequency SSVEP data to enhance high-frequency SSVEP performance. A filtering mechanism is designed to extract informative components from low-frequency signals, and the least squares algorithm is employed to generate high-quality synthetic high-frequency data. Experiments conducted on two public datasets using TDCA, eTRCA, and advanced TRCA-based algorithms demonstrate significant performance improvements. Our approach requires only two calibration trials, achieving 9.03% and 14.49% accuracy increases for eTRCA and TDCA in Dataset 1, and 13.91% and 14.53% improvements in Dataset 2, all within 1.5 s. Moreover, our approach effectively addresses the issue of single calibration data for high-frequency SSVEP-BCI systems. These results support the feasibility of fast calibration and improved performance in real-world high-frequency BCI applications.