Related Experiment Video
Updated: Sep 11, 2025
Robotized Testing of Camera Positions to Determine Ideal Configuration for Stereo 3D Visualization of Open-Heart Surgery
Published on: August 12, 2021
Universal Vector Calibration for Orientation-Invariant 3D Sensor Data
1School of Electrical Engineering, Korea University, Seoul 02841, Republic of Korea.

Abstract:
Modern electronic devices such as smartphones, wearable devices, and robots typically integrate three-dimensional sensors to track the device's movement in the 3D space. However, sensor measurements in three-dimensional vectors are highly sensitive to device orientation since a slight change in the device's tilt or heading can change the vector values. To avoid complications, applications using these sensors often use only the magnitude of the vector, as in geomagnetic-based indoor positioning, or assume fixed device holding postures such as holding a smartphone in portrait mode only. However, using only the magnitude of the vector loses the directional information, while ad hoc posture assumptions work under controlled laboratory conditions but often fail in real-world scenarios. To resolve these problems, we propose a universal vector calibration algorithm that enables consistent three-dimensional vector measurements for the same physical activity, regardless of device orientation. The algorithm works in two stages. First, it transforms vector values in local coordinates to those in global coordinates by calibrating device tilting using pitch and roll angles computed from the initial vector values. Second, it additionally transforms vector values from the global coordinate to a reference coordinate when the target coordinate is different from the global coordinate by correcting yaw rotation to align with application-specific reference coordinate systems. We evaluated our algorithm on geomagnetic field-based indoor positioning and bidirectional step detection. For indoor positioning, our vector calibration achieved an 83.6% reduction in mismatches between sampled magnetic vectors and magnetic field map vectors and reduced the LSTM-based positioning error from 31.14 m to 0.66 m. For bidirectional step detection, the proposed algorithm with vector calibration improved step detection accuracy from 67.63% to 99.25% and forward/backward classification from 65.54% to 100% across various device orientations.
More Related Videos
 11:57
Three-dimensional Super Resolution Microscopy of F-actin Filaments by Interferometric PhotoActivated Localization Microscopy iPALM
Published on: December 1, 2016
 10:12
Three Dimensional Vestibular Ocular Reflex Testing Using a Six Degrees of Freedom Motion Platform
Published on: May 23, 2013
Related Concept Videos
 01:16
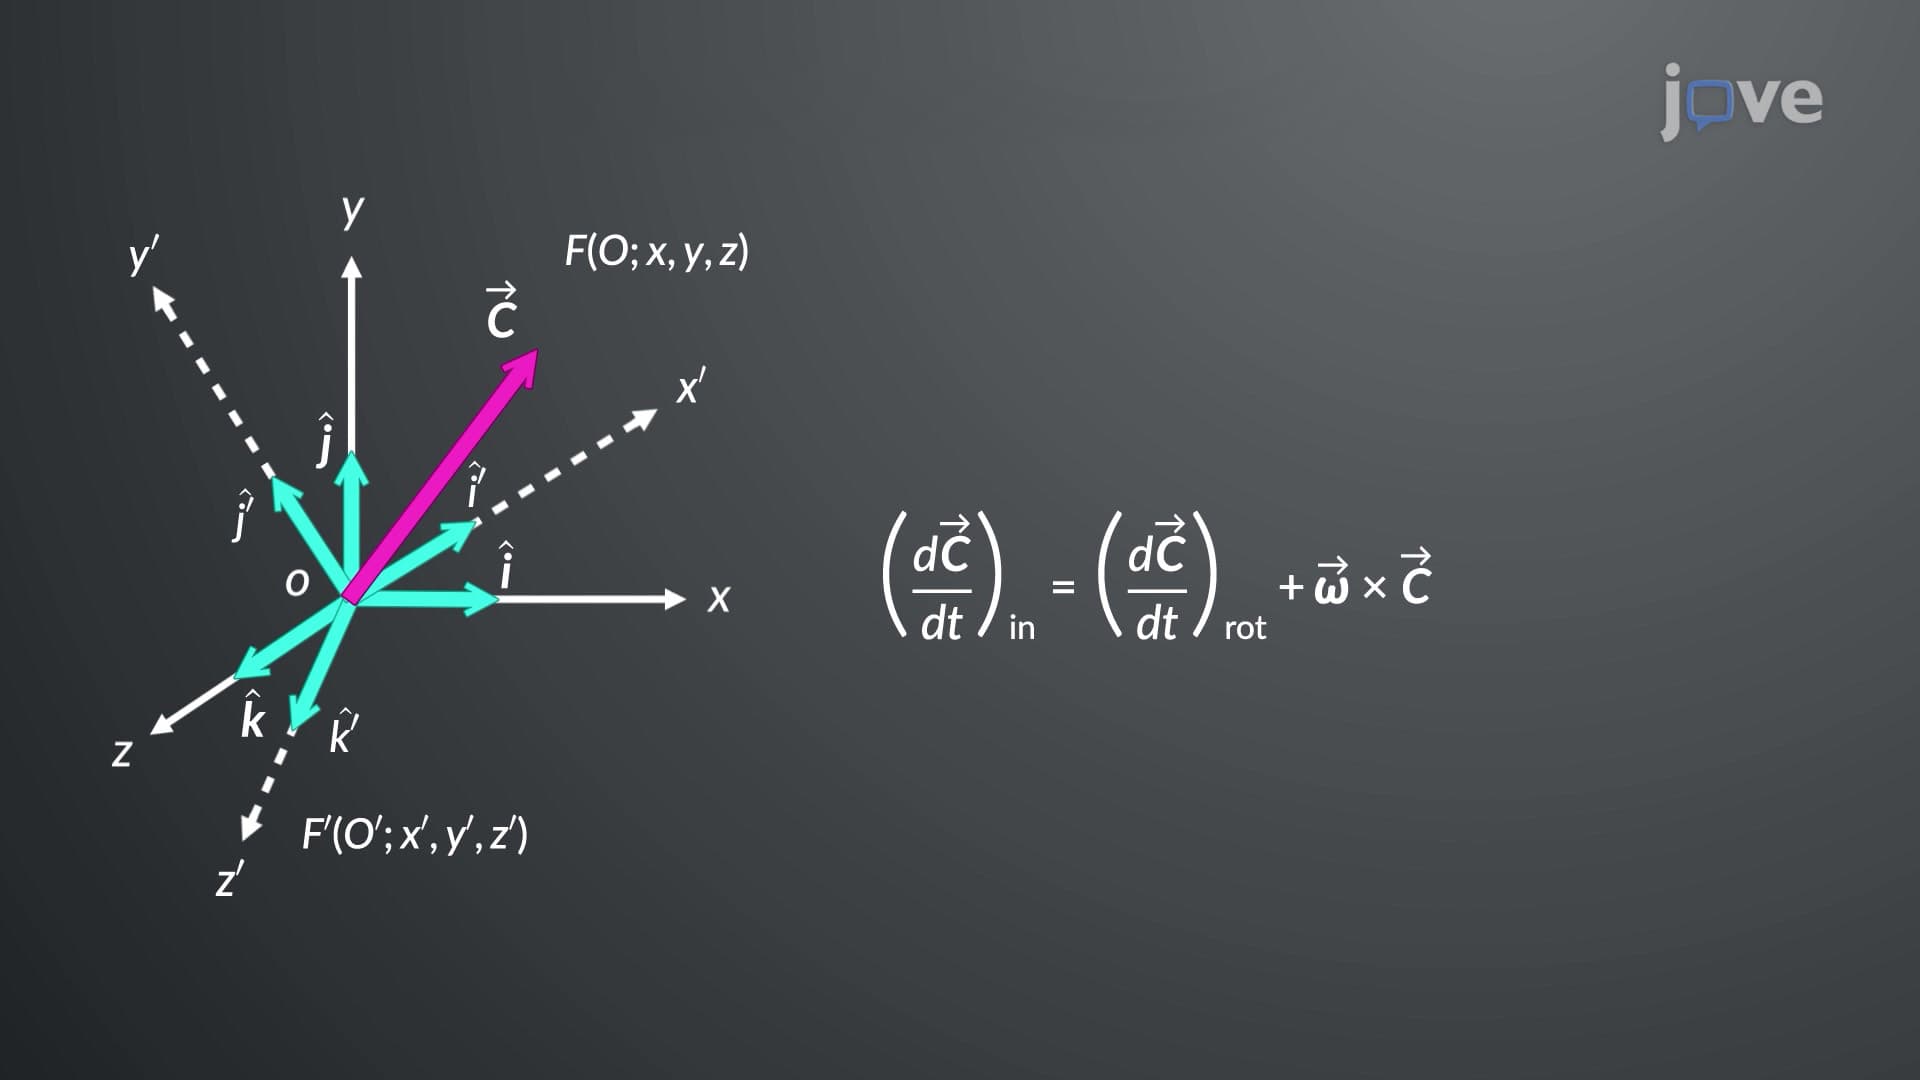
Vector Transformation in Rotating Coordinate Systems
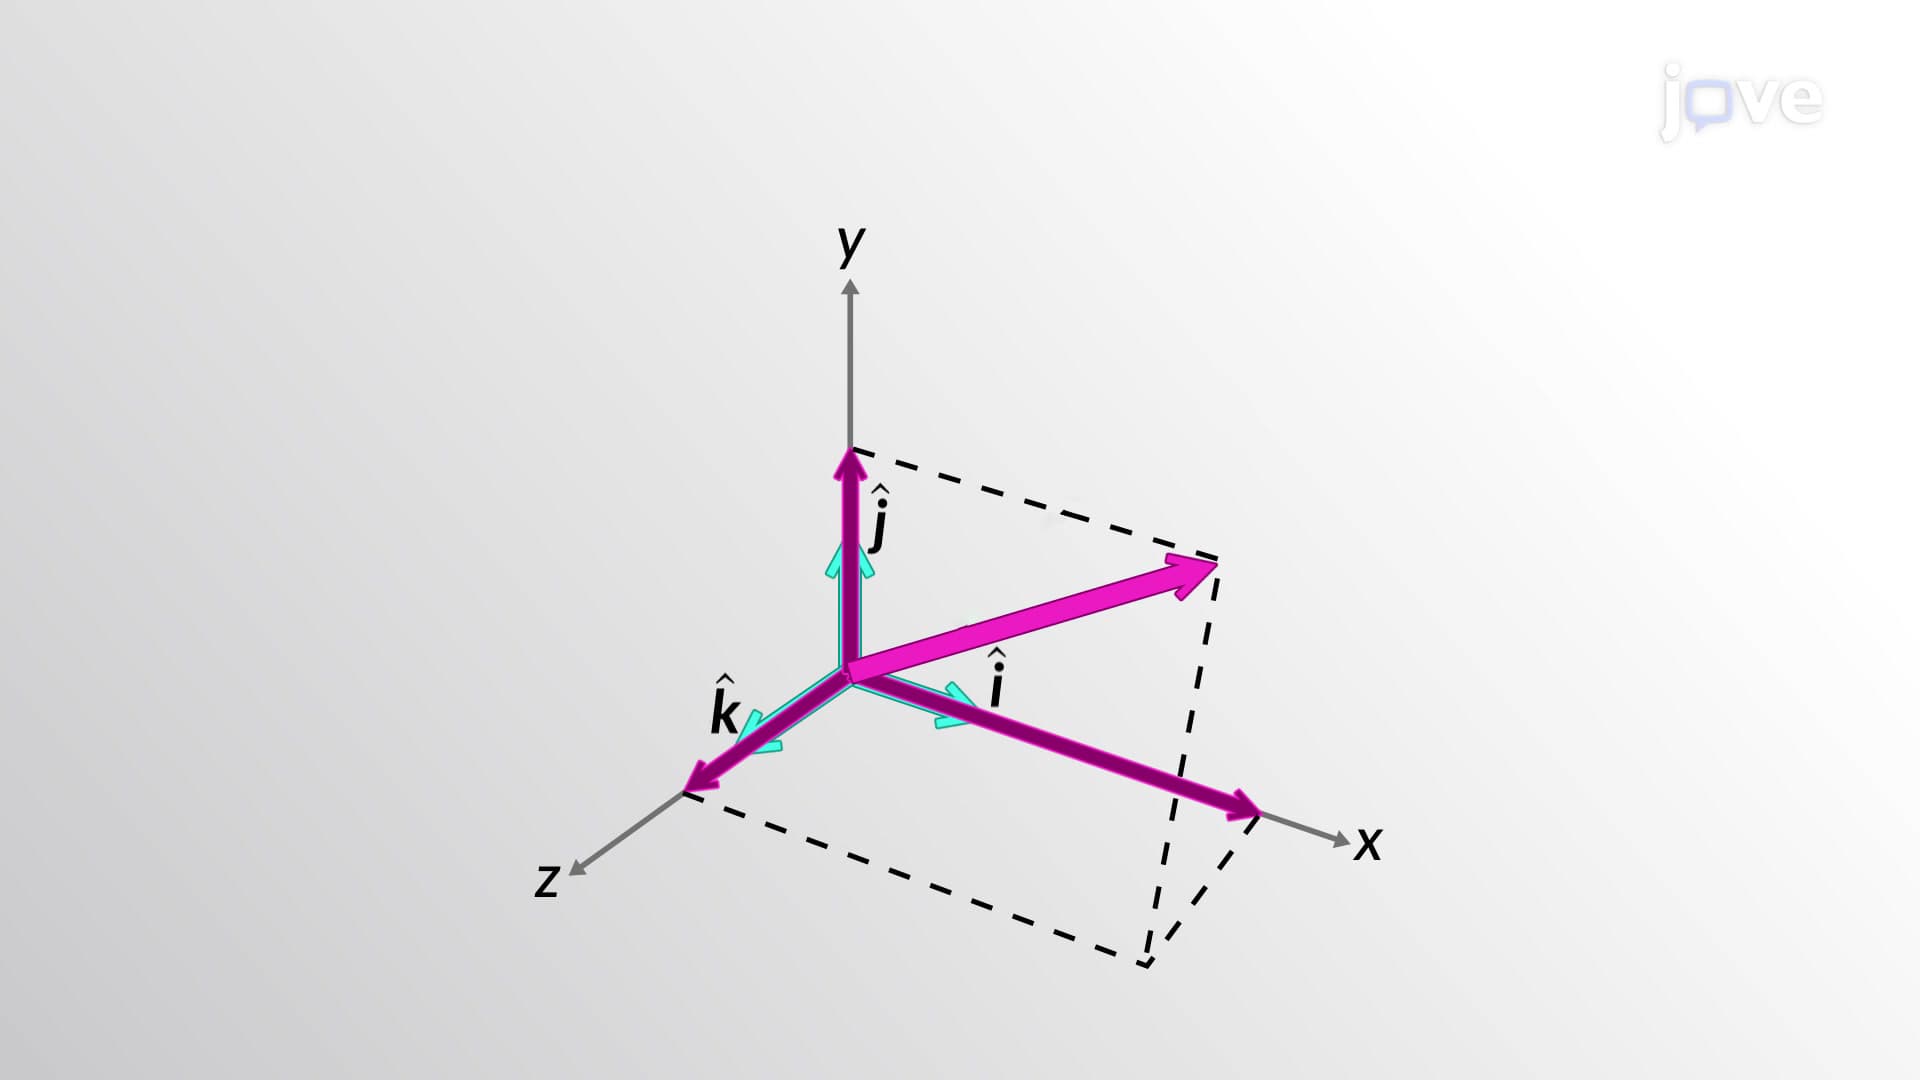 01:29
Vector Components in the Cartesian Coordinate System
 01:20
Calibration Curves: Linear Least Squares
For data that follow a straight line, the standard method for fitting is the linear...
 01:03
Inertial Frames of Reference
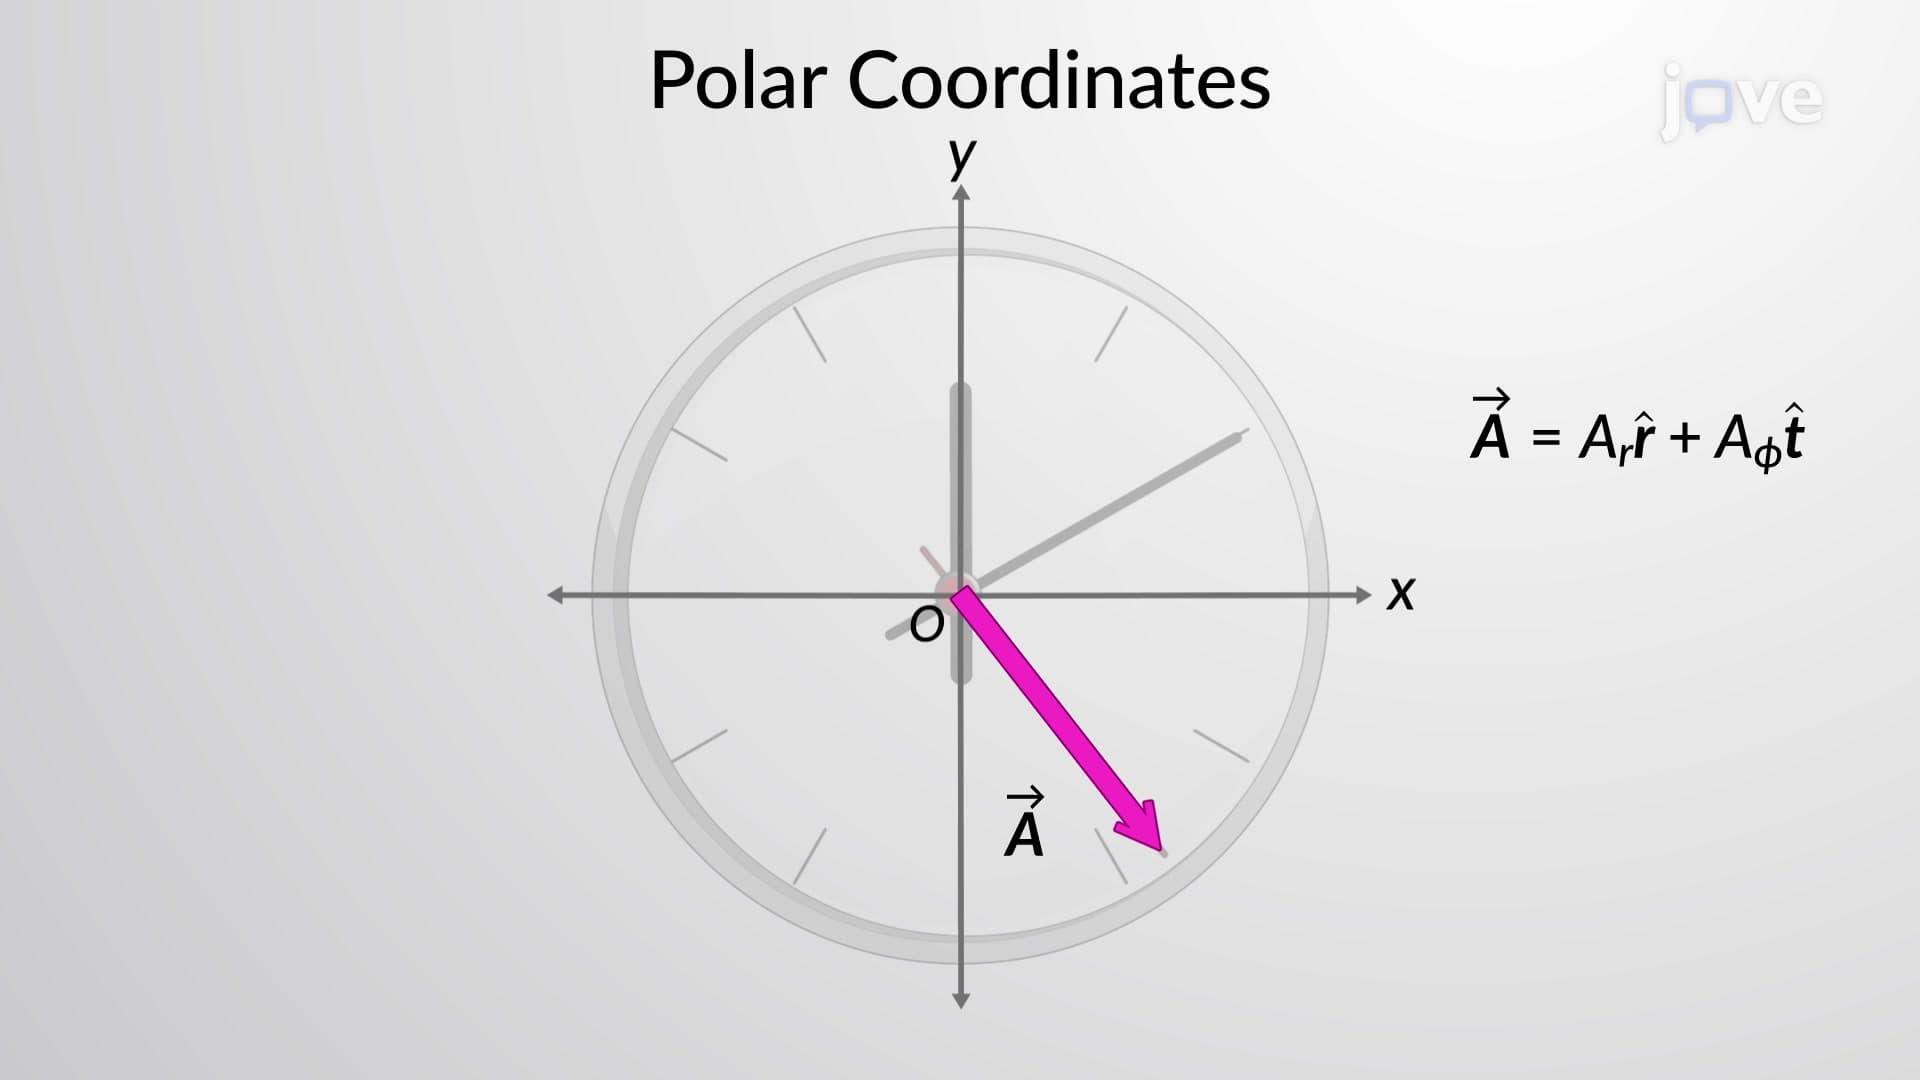 01:22
Polar and Cylindrical Coordinates
 01:12
Instrument Calibration
Analytical Balance Calibration
An analytical balance measures mass and requires regular calibration to...