Related Experiment Video
Updated: Sep 10, 2025

Measurement of Dynamic Force Acted on Water Strider Leg Jumping Upward by the PVDF Film Sensor
Published on: August 3, 2018
Water Strider-Inspired, Responsive Jumping Robot Driven by Electro-Ribbon Actuator
Jianhao Liu1, Yangyang Zhao1, Wanqiu Zhang1
1School of Mechanical Science and Engineering, Huazhong University of Science and Technology, Wuhan, 430074, P. R. China.

Abstract:
The water striders demonstrate exceptional agility in dynamic water-surface locomotion, enabling them to effectively avoid obstacles and evade predators. While current bioinspired jumping water strider robots predominantly rely on water pressure, which stores mechanical energy through elastic components to achieve transient high-power output, these robots exhibit delayed actuation responses (>500 ms) and substantial hydrodynamic disturbances during actuation. Here, a centimeter-scale jumping biomimetic water strider robot (mass: 0.21 g) that uses surface tension to jump on the water surface is presented. The robot employs an electro-ribbon actuator, enabling sub-second kinetics response, achieving vertical leaps of 128 mm with minimal surface perturbation. The gravitational potential energy of the robot at peak jumping height exceeds several orders of magnitude compared to the existing surface tension-dominated jumping robot. Additionally, the study also systematically studies the interaction mechanism of dynamic contact between the robot's driving legs and the liquid-air interface. This work provides new design principles for developing high-performance biomimetic systems capable of dynamic fluid surface interactions.

Related Concept Videos
 01:16
Hydraulic Jump: Problem Solving
 01:29
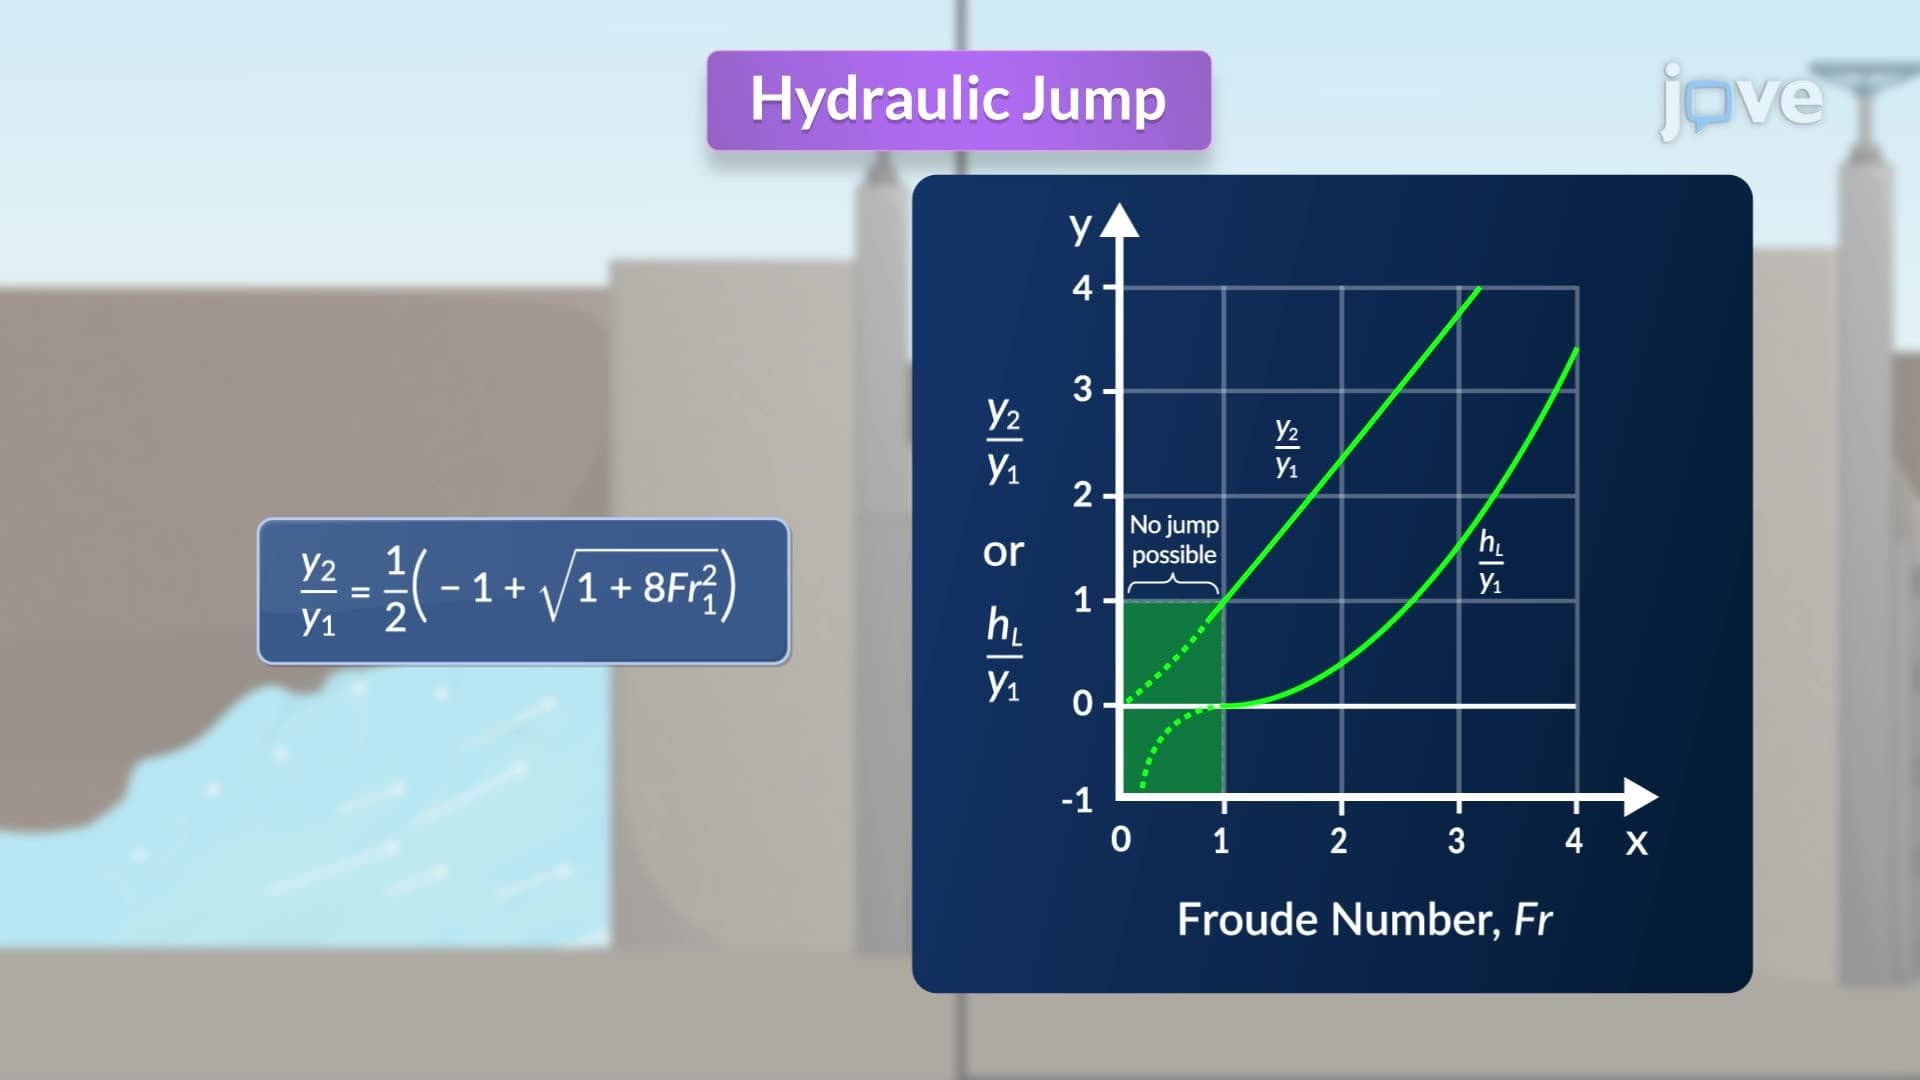
Hydraulic Jump
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:14
Design Example: Frog Muscle Response
When the switch connecting the RL circuit is closed, a brief muscle contraction is observed. This is because, at a steady state, the inductor acts like a short...
 01:26
Kinetic Friction
 01:18
Actin Treadmilling