Related Experiment Video
Updated: Sep 9, 2025
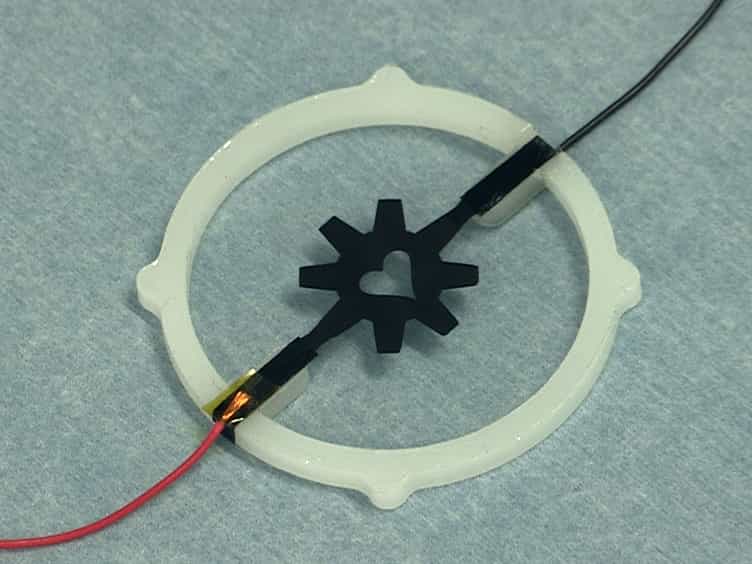

Fabrication Process of Silicone-based Dielectric Elastomer Actuators
Published on: February 1, 2016
Conformal Elastic Electret Actuators with High-Fidelity Haptic Rendering for Immersive Virtual Reality
Yunfei Bai1, Haolong Zhang1, Dongkai Wang1
1Shenzhen International Graduate School, Tsinghua University, Shenzhen 518055, China.

Abstract:
The development of high-performance wearable haptic actuators remains challenging for immersive virtual reality (VR) applications due to limitations in voltage efficiency, low-voltage operation, and tactile fidelity. This work presents conformal elastic electret actuators composed of silica and poly(dimethylsiloxane) (PDMS) nanocomposites and liquid-metal (LM) electrodes, which overcome limitations in skin-device mechanical mismatch and energy efficiency. Through parametric polarization optimization under coupled thermal-electric fields (4 MV/m, 180 °C), the actuators demonstrate low threshold voltage (38.2 V) and exceptional strong vibrational output (381 nN/V), which surpass those of conventional dielectric elastomer (DE) actuators (143 nN/V at 1000 V) and hydraulically amplified taxel (HAXEL) systems (214 nN/V at 500 V). The elastomer dip-coating fabrication enables finger-conformal integration, providing 119.9% displacement enhancement and maintaining kilohertz-range waveform fidelity under various driving signals compared to nonconformal configurations. Wearable haptic interaction systems with five-channel actuators achieve 95.4% accuracy in remote character transmission (635 trials) and facilitate proprioceptive guidance in piano pedagogy. When integrated into the VR system, the actuators achieve 91.2% discrimination of standardized textures (Ra = 0.8-12.5 μm) through spectral encoding of the surface roughness. This technology bridges the gap between wearable haptics and immersive VR, advancing applications in telematics, skill training, and virtual texture rendering.