Related Experiment Video

Updated: Jan 17, 2026
Measuring the Flight Ability of the Ambrosia Beetle, Platypus Quercivorus Murayama, Using a Low-Cost, Small, and Easily Constructed Flight Mill
07:37

Measuring the Flight Ability of the Ambrosia Beetle, Platypus Quercivorus Murayama, Using a Low-Cost, Small, and Easily Constructed Flight Mill

Published on: August 6, 2018

8.1K

Lowly fly or impressive miniature robot?

Robin R Murphy1

  • 1Computer Science and Engineering, Texas A&M University, College Station, TX 77843, USA.

Science Robotics
|September 24, 2025
PubMed

Abstract:

The novel Flybot gives a science-forward view of the challenges in building a fully autonomous robot fly.


More Related Videos

Insect-controlled Robot: A Mobile Robot Platform to Evaluate the Odor-tracking Capability of an Insect
09:00

Insect-controlled Robot: A Mobile Robot Platform to Evaluate the Odor-tracking Capability of an Insect

Published on: December 19, 2016

15.2K
An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
10:51

An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces

Published on: March 10, 2011

14.2K

Related Experiment Videos

Last Updated: Jan 17, 2026

Measuring the Flight Ability of the Ambrosia Beetle, Platypus Quercivorus Murayama, Using a Low-Cost, Small, and Easily Constructed Flight Mill
07:37

Measuring the Flight Ability of the Ambrosia Beetle, Platypus Quercivorus Murayama, Using a Low-Cost, Small, and Easily Constructed Flight Mill

Published on: August 6, 2018

8.1K
Insect-controlled Robot: A Mobile Robot Platform to Evaluate the Odor-tracking Capability of an Insect
09:00

Insect-controlled Robot: A Mobile Robot Platform to Evaluate the Odor-tracking Capability of an Insect

Published on: December 19, 2016

15.2K
An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
10:51

An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces

Published on: March 10, 2011

14.2K

Related Concept Videos

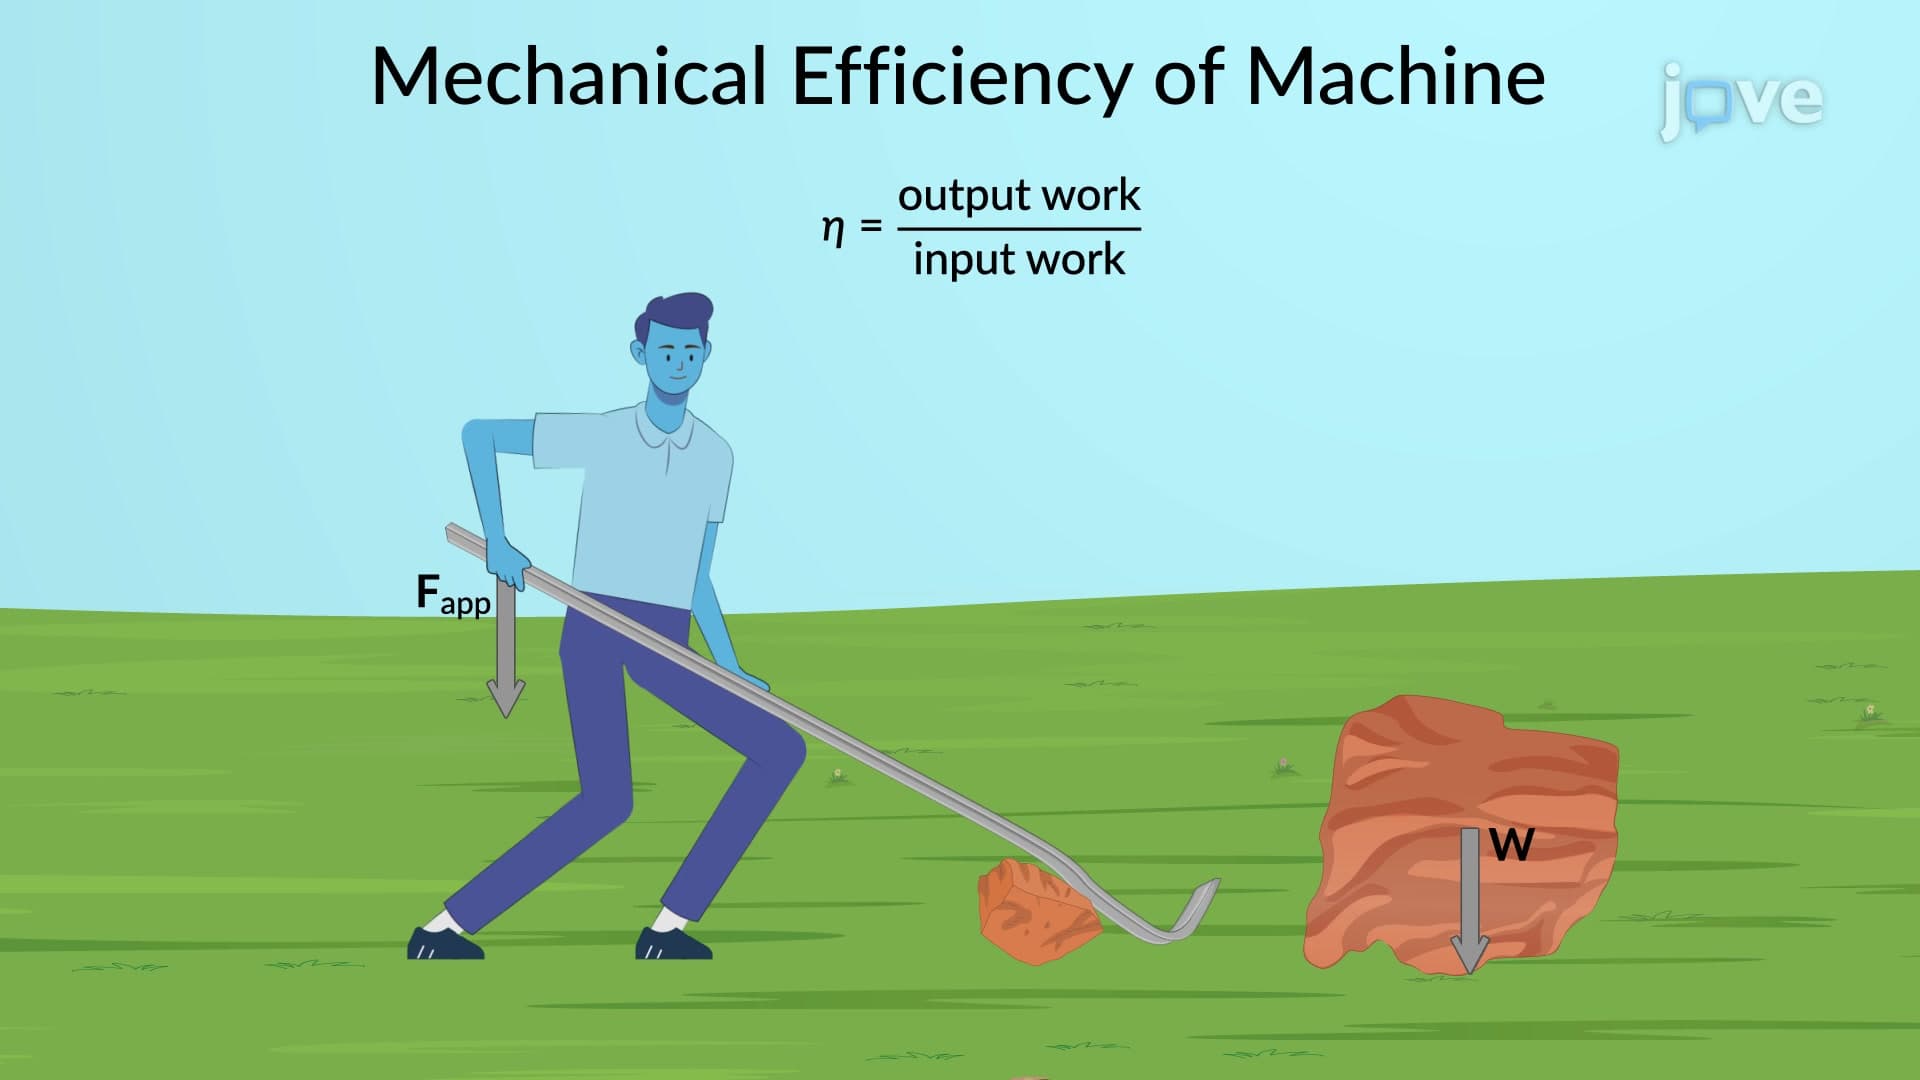
Mechanical Efficiency of Real Machines01:14

Mechanical Efficiency of Real Machines

1.2K
The mechanical efficiency of a machine is a fundamental concept that describes how effectively a machine can convert input work into output work. According to this concept, the efficiency of a machine is equal to the ratio of the output work to the input work. An ideal machine, meaning a machine that has no energy losses, has an efficiency of one. This implies that the input work and the output work are equal.
However, in reality, no machine can be truly ideal, and all of them experience some...
1.2K

Articles linked to this work by shared authors, journal, and citation graph.

What if an alien believes our robot videos?

Science robotics·2026

Are humanoid robots in 2035 more fiction than science?

Science robotics·2026

Is a robot a tool or an agent?

Science robotics·2026

Is your robot vacuum cleaner spying on you?

Science robotics·2026

The Moon needs robots.

Science robotics·2026

Robot farm elegy.

Science robotics·2026

ALBATROSS: A bioinspired, aerially deployable, autonomous sailing sensor platform.

Science robotics·2026

Taking aerial-aquatic robots beyond biological capabilities.

Science robotics·2026

Takeoff of an all-polymer micro aerial flying robot.

Science robotics·2026

AI-driven actuation-compatible tracking for closed-loop navigation of miniature robots in vivo.

Science robotics·2026

Stabilizing telerobotic endobronchial imaging and interventions in breathing lungs with a helical brace.

Science robotics·2026

Bridging stakeholder needs and technological capabilities to identify humanoid robot applications in rehabilitation: a case study in an ALS multidisciplinary care unit.

Frontiers in robotics and AI·2026

A shape-morphing bilayer hydrogel microrobot featuring prolonged retention for targeted cell delivery.

Journal of materials chemistry. B·2026

Knowledge of robotic identity modulates attentional orienting to humanoid robot motion.

Psychological research·2026

Robot-assisted total hip arthroplasty: does improved precision translate into better clinical outcomes? A systematic review.

International orthopaedics·2026

Radiographic accuracy of implant positioning in unicompartmental knee arthroplasty, does an imageless robotic system make a difference?

Archives of orthopaedic and trauma surgery·2026

The learning curve associated with robotic-assisted shoulder arthroplasty: A feasibility study.

Shoulder & elbow·2026
See all related articles
JoVE
x logofacebook logolinkedin logoyoutube logo
ABOUT JoVE
OverviewLeadershipBlogJoVE Help Center
AUTHORS
Publishing ProcessEditorial BoardScope & PoliciesPeer ReviewFAQSubmit
LIBRARIANS
TestimonialsSubscriptionsAccessResourcesLibrary Advisory BoardFAQ
RESEARCH
JoVE JournalMethods CollectionsJoVE Encyclopedia of ExperimentsArchive
EDUCATION
JoVE CoreJoVE BusinessJoVE Science EducationJoVE Lab ManualFaculty Resource CenterFaculty Site
Terms & Conditions of Use
Privacy Policy
Policies
Jove
Visualize
Contact Us