Related Experiment Video
Updated: Jan 16, 2026


Robotic Mirror Therapy System for Functional Recovery of Hemiplegic Arms
Published on: August 15, 2016
Robot-Assisted Mirror Rehabilitation for Post-Stroke Upper Limbs: A Personalized Control Strategy
Jiayue Chen1, Zhongjiang Cheng1, Yutong Cai1
1Sino-German College of Intelligent Manufacturing, Shenzhen Technology University, Shenzhen 518118, China.

Abstract:
To address the limitations of traditional mirror therapy in stroke rehabilitation, such as rigid movement mapping and insufficient personalization, this study proposes a robot-assisted mirror rehabilitation framework integrating multimodal biofeedback. By synchronously capturing kinematic features of the unaffected upper limb and surface electromyography (sEMG) signals from the affected limb, a dual-modal feature fusion network based on a cross-attention mechanism is developed. This network dynamically generates a time-varying mirror ratio coefficient λ, which is incorporated into the exoskeleton's admittance control loop. Combining a trajectory generation algorithm based on dynamic movement primitives (DMPs) with a compliant control strategy incorporating dynamic constraints, the system achieves personalized rehabilitation trajectory planning and safe interaction. Experimental results demonstrate that, compared to traditional mirror therapy, the proposed system exhibits superior performance in bilateral trajectory covariance metrics, the mirror symmetry index, and muscle activation levels.
More Related Videos
 04:49
Author Spotlight: Enhancing Post-Stroke Upper Limb Rehabilitation with Robotic Technologies for Improved Motor Recovery and Functional Outcomes
Published on: September 6, 2024
 05:28
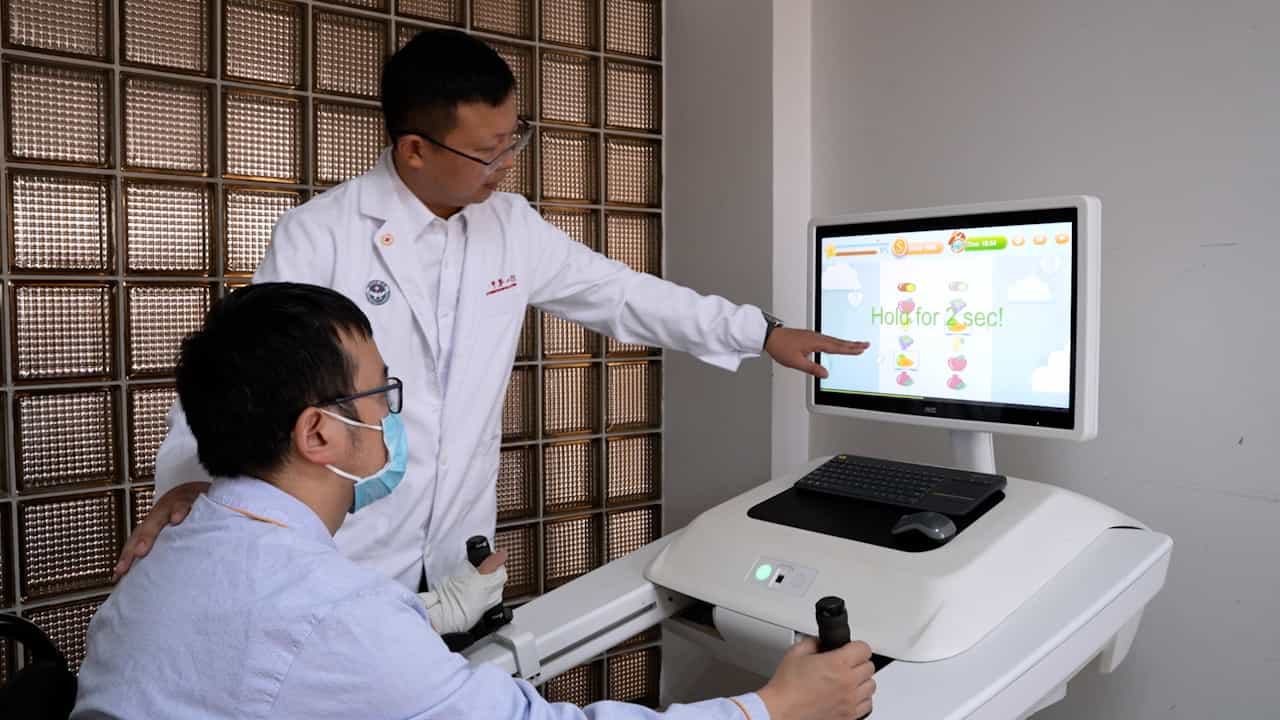
Author Spotlight: Enhancing Upper Limb Rehabilitation in Stroke Patients Through Advanced Robotic and Neuromodulation Technologies
Published on: October 11, 2024