Related Experiment Video
Updated: Jan 16, 2026


Robotic Mirror Therapy System for Functional Recovery of Hemiplegic Arms
Published on: August 15, 2016
Diagrammatic physical robot models
Alvaro Miyazawa1, Sharar Ahmadi2, Ana Cavalcanti1
1Department of Computer Science, University of York, York, UK.

Abstract:
Simulation is a favoured technique in robotics. It is, however, costly, in terms of development time, and its usability is limited by the lack of standardisation and portability of simulators. We present RoboSim, a diagrammatic tool-independent domain-specific language to model robotic platforms and their controllers. It can be regarded as a profile of UML/SysML enriched with time primitives, differential equations, and a mathematical semantics. Our previous work on RoboSim described a notation to specify control software. In this paper, we present a novel notation to describe physical models: block diagrams that can be linked to the platform-independent software model to characterise how services required by the software are realised by actuators and sensors. Behaviours are specified by differential equations, and simulations and mathematical models of the whole system can be generated automatically. Our main contributions are a modular and extensible diagrammatic notation that supports the explicit specification of physical behaviours; a set of validation rules that identify well-formed models; a model-to-model transformation from RoboSim to an input format accepted by several simulators; and a formal semantics for mathematical reasoning.


Related Concept Videos
 01:07
Free Body Diagrams: Examples
 01:22
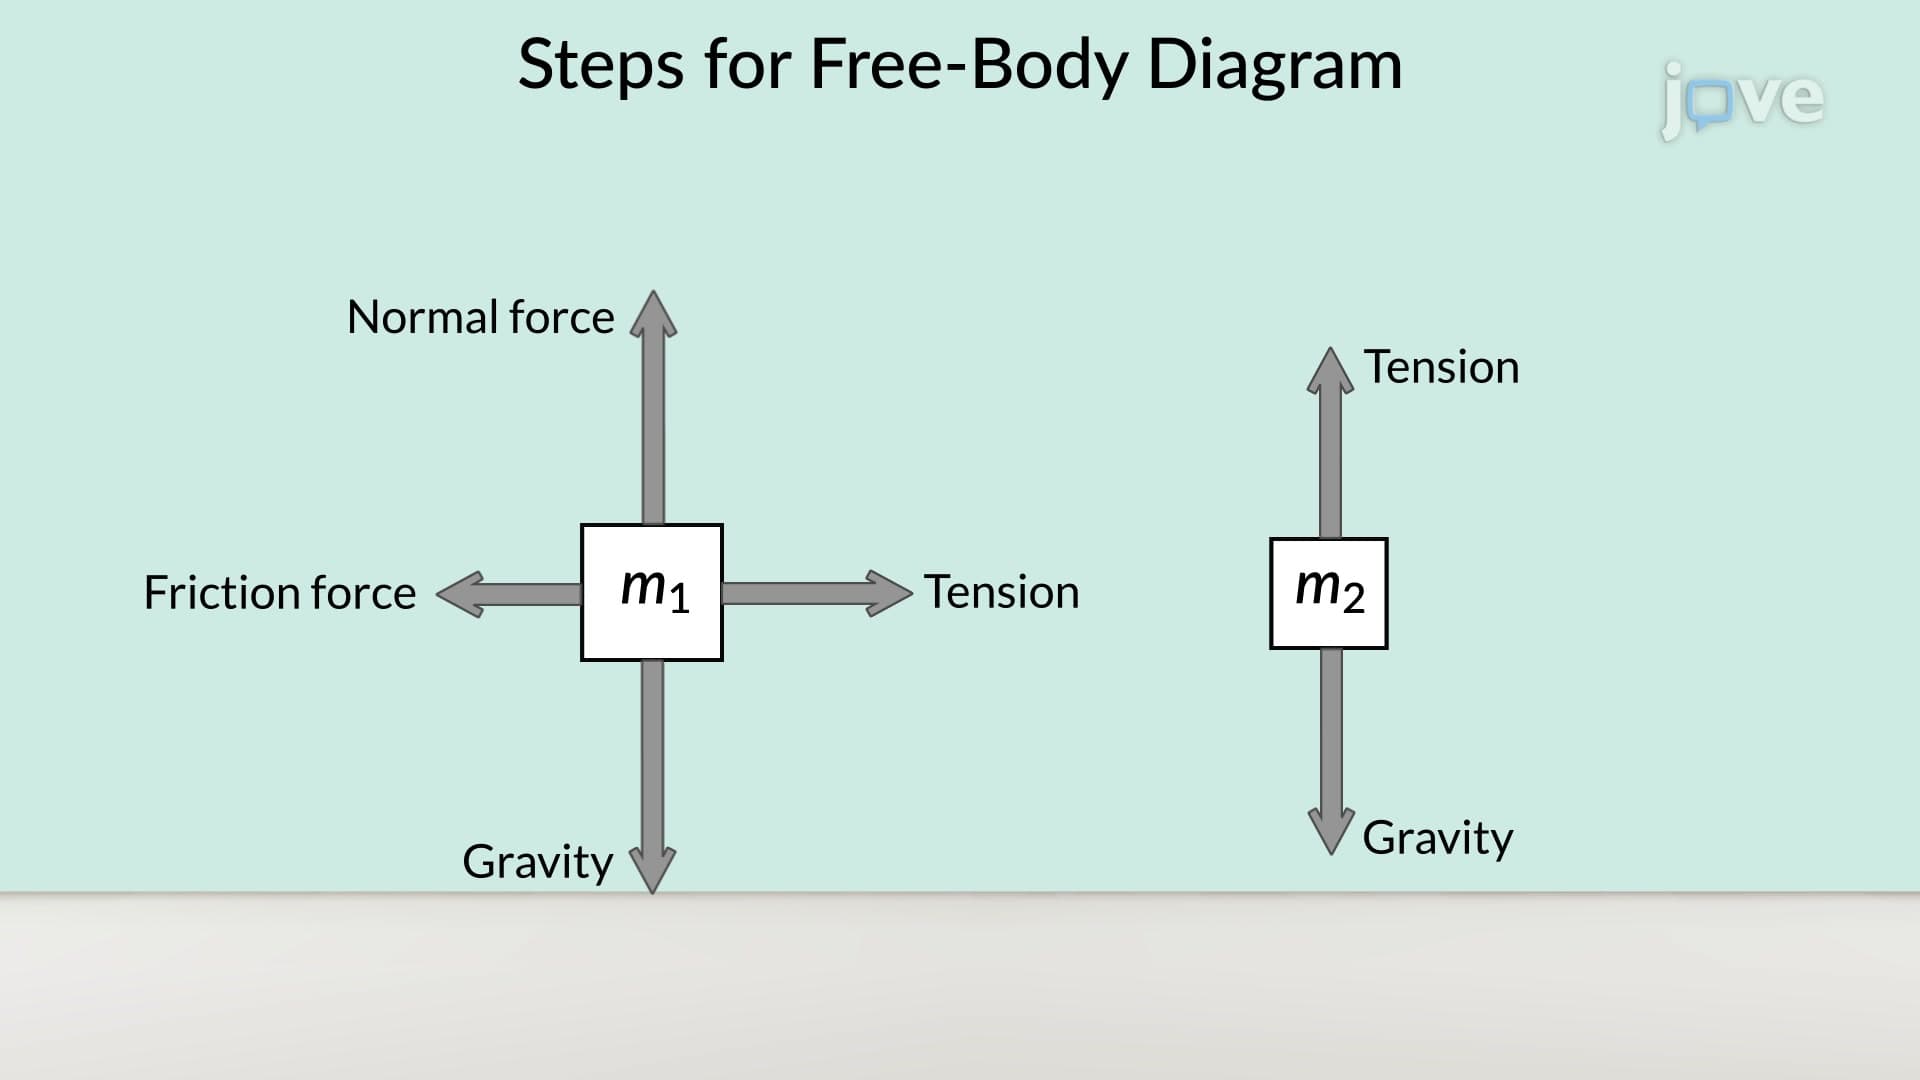
Steps for Free-Body Diagram
To find the acceleration of the system, it is first necessary to calculate the net force on the system. In order to accomplish this, a free-body diagram can be created to...
 01:28
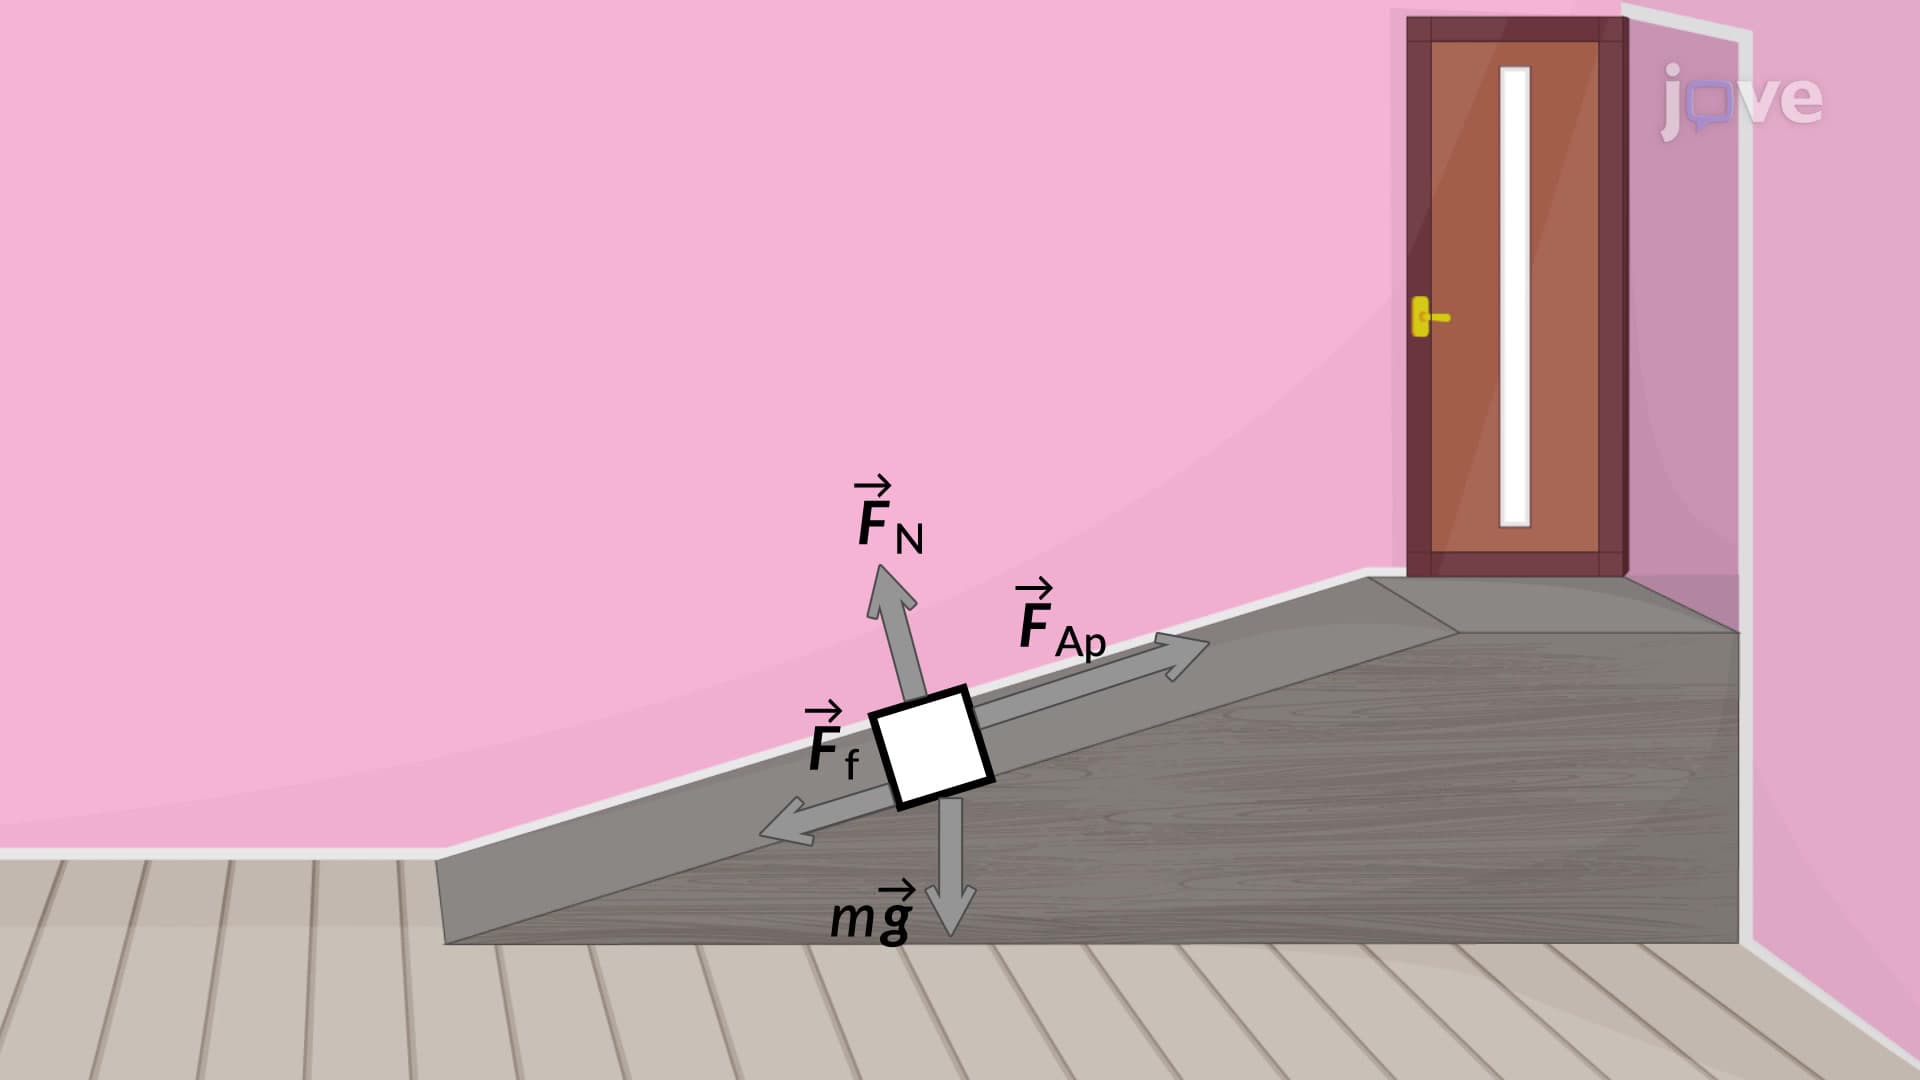
Free-body Diagram
A free-body diagram transforms a complex problem into a simple representation, making it easy to understand the...
 01:16
Drawing Free-body Diagrams: Rules
 01:21
Mechanistic Models: Overview of Compartment Models
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...