
Static output feedback pole placement via parameter-dependent Ackermann and Greville matrix formulae
Abdulrahman H Bajodah1, Hassen Mibar2
1Aerospace Engineering Department, King Abdulaziz University, P.O. Box 80204, Jeddah 21589, Saudi Arabia.

Abstract:
The paper generalizes Ackermann's pole placement methodology to static output feedback pole placement (SOFPP) for general MIMO continuous LTI systems. The main tool used is Moore-Penrose generalized inversion of Kalman controllability matrix, which replaces square inversion that is performed in the original Ackermann's formulation for single input controllable systems. Additionally, affine and partially explicit parameterization of the accompanying nonempty controllability matrix nullspace is utilized to characterize solution non uniqueness of the MIMO SOFPP control problem and to solve for SOFPP feedback control gains. The proposed nullspace parameterization is inspired by the vector Greville formula for general solutions of linear algebraic equations, and it extends the formula to solve parameter-dependent (PD) linear matrix equations. The redundant nullspace parameterizing variables in the PD matrix Greville formula are constrained such that the closed loop system matrix satisfies its characteristic equation. Necessary and sufficient conditions for SOFPP solution existence are derived for general (possibly uncontrollable) continuous LTI systems, regardless of dimensionalities and ranks of system triplet and controllability matrices, and regardless of spectral multiplicities of the open loop system matrix and the sought closed loop system matrix. If an SOFPP control problem is solvable then all its control matrix gain solutions are synthesized partially explicitly via affine parameterization in terms of the constrained nullspace parameterizing variables. Five examples are provided to illustrate the proposed SOFPP control system analysis and design methodology.
More Related Videos


Related Concept Videos
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:19
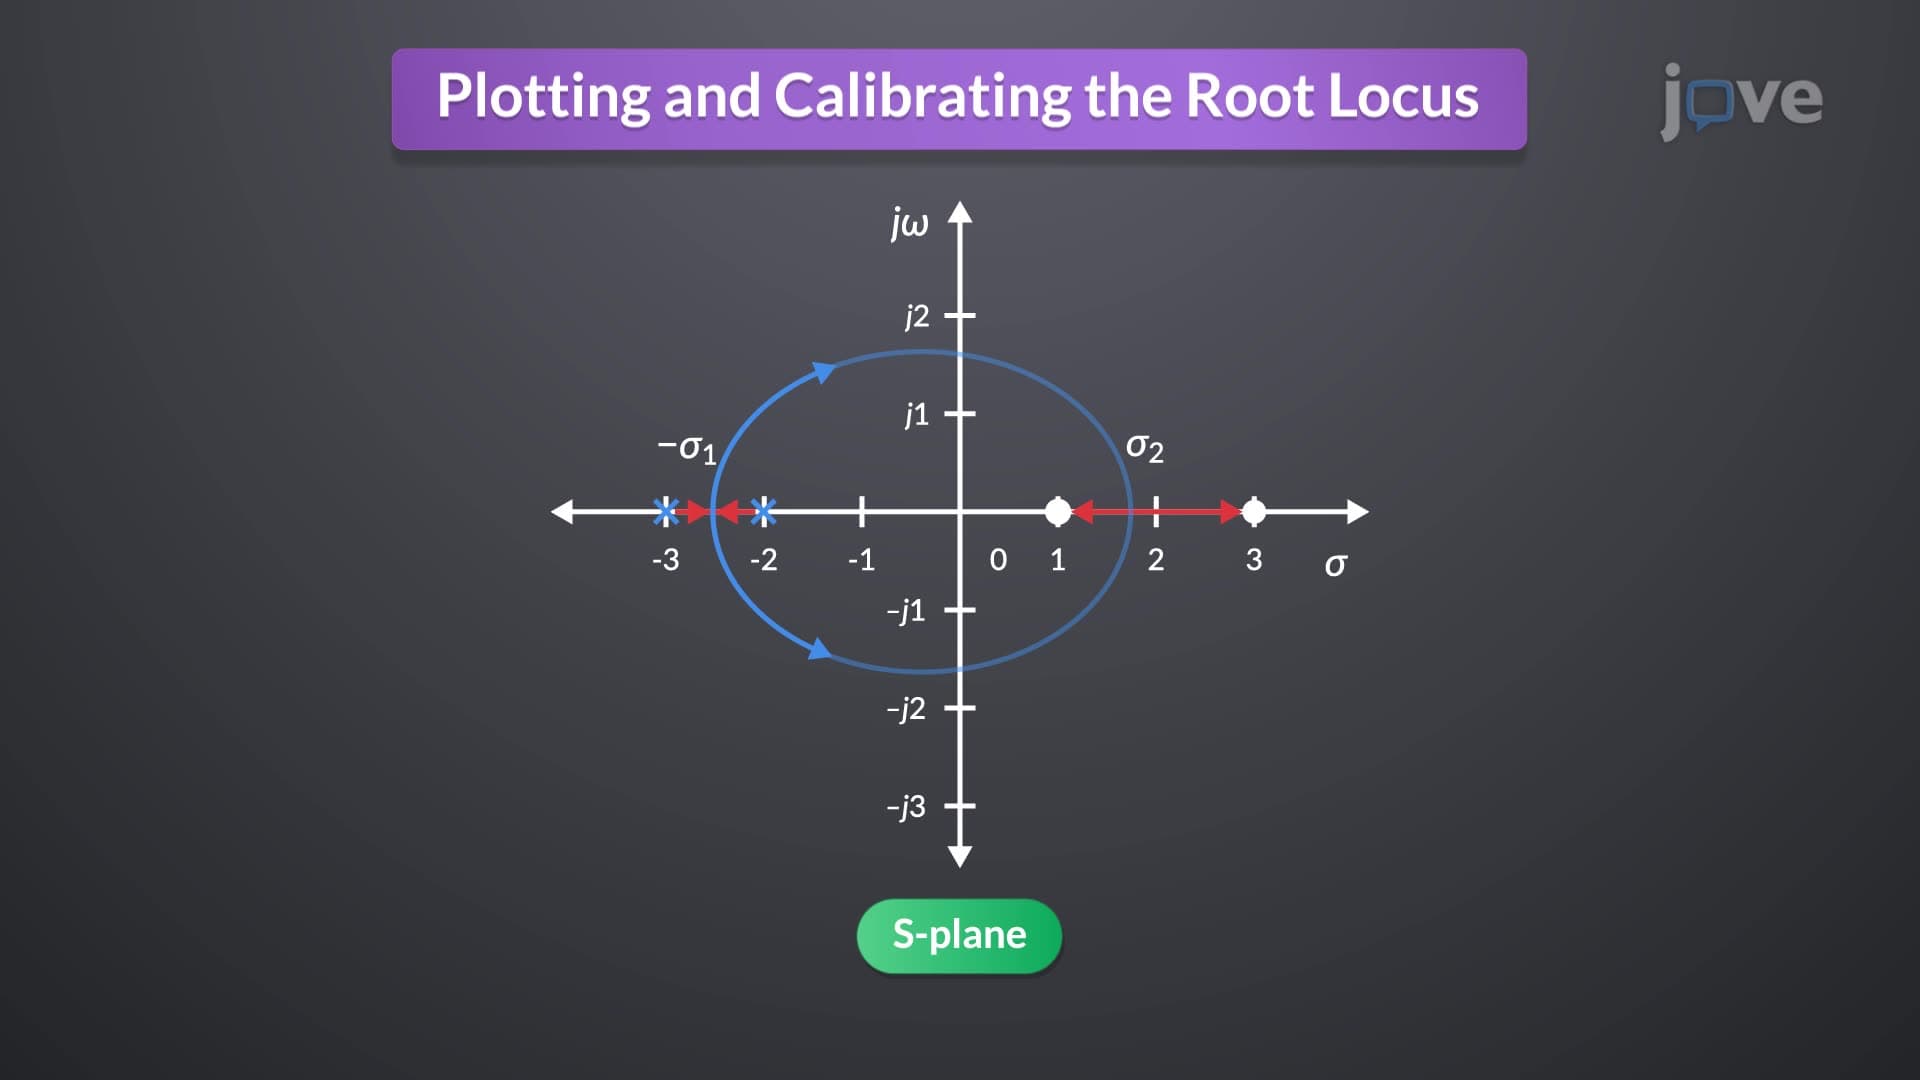
Plotting and Calibrating the Root Locus
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:23
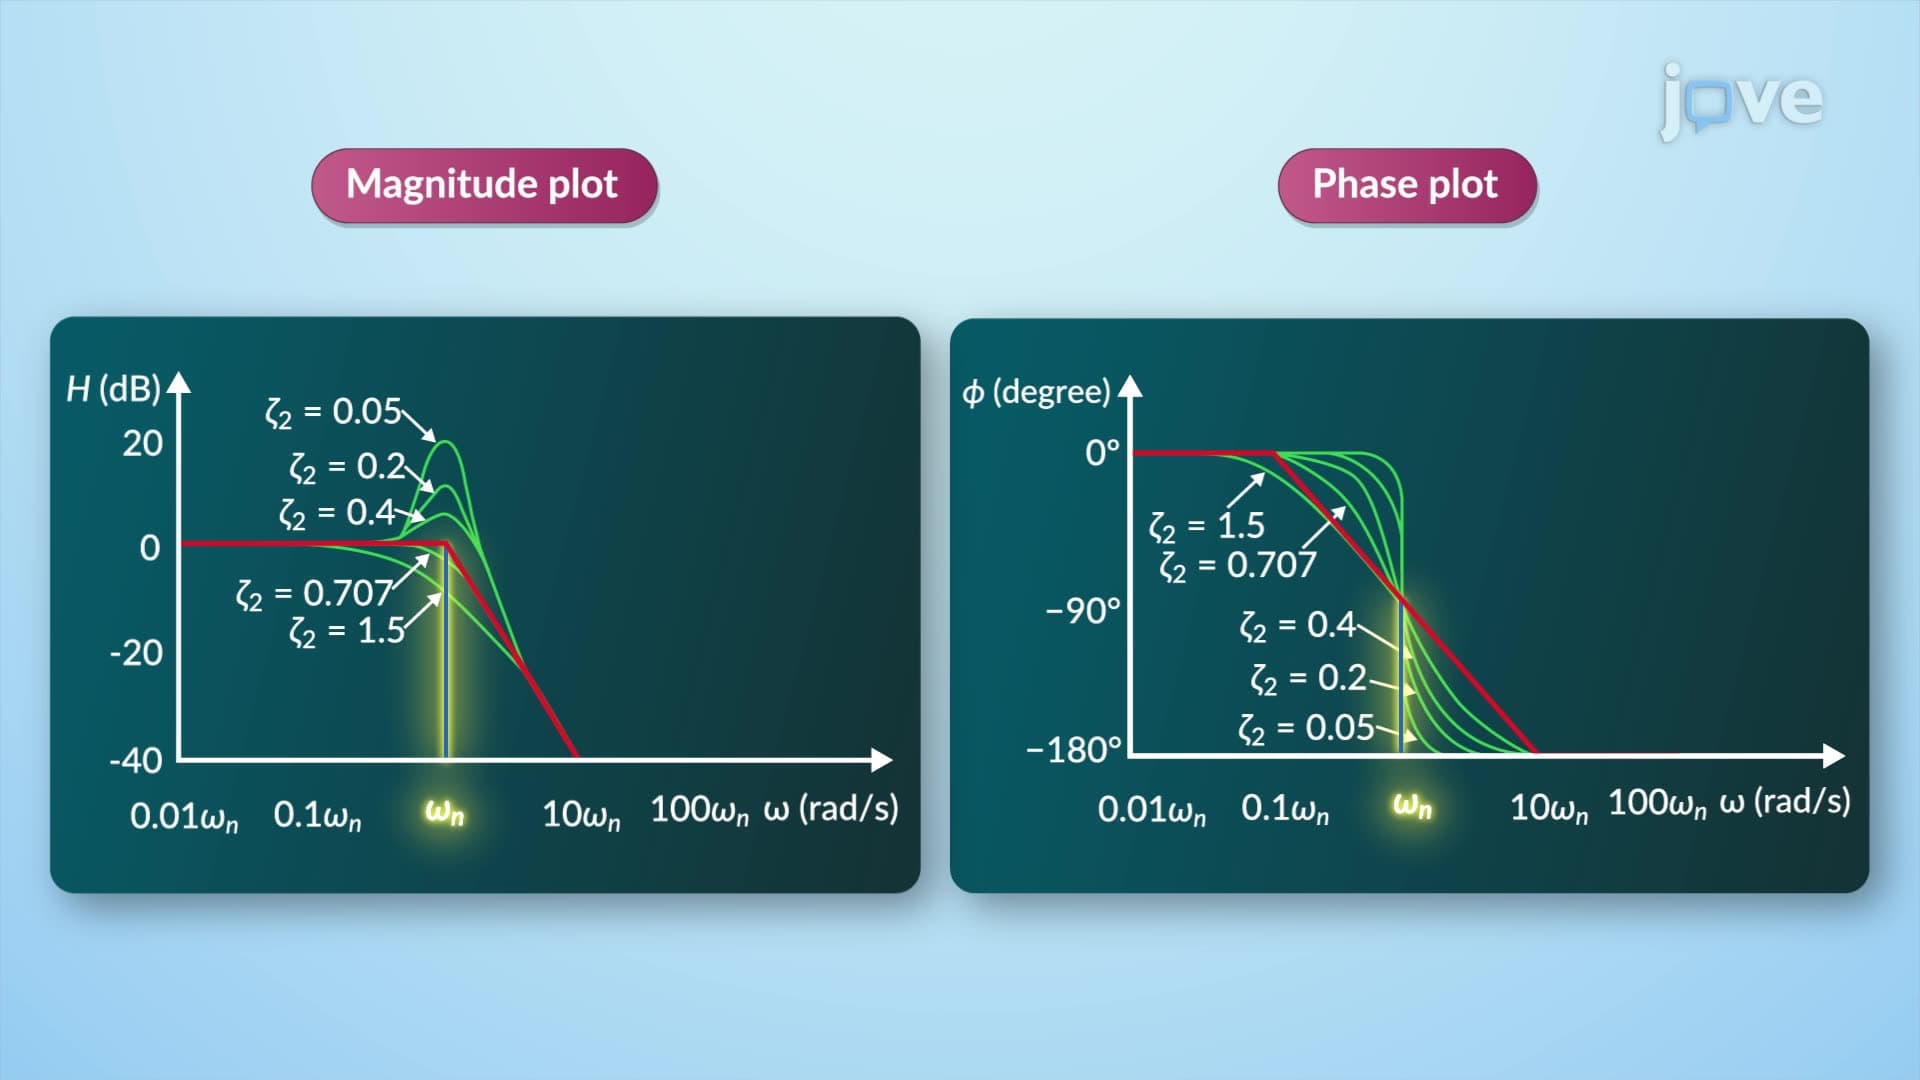
Transfer function and Bode Plots-II
 01:23
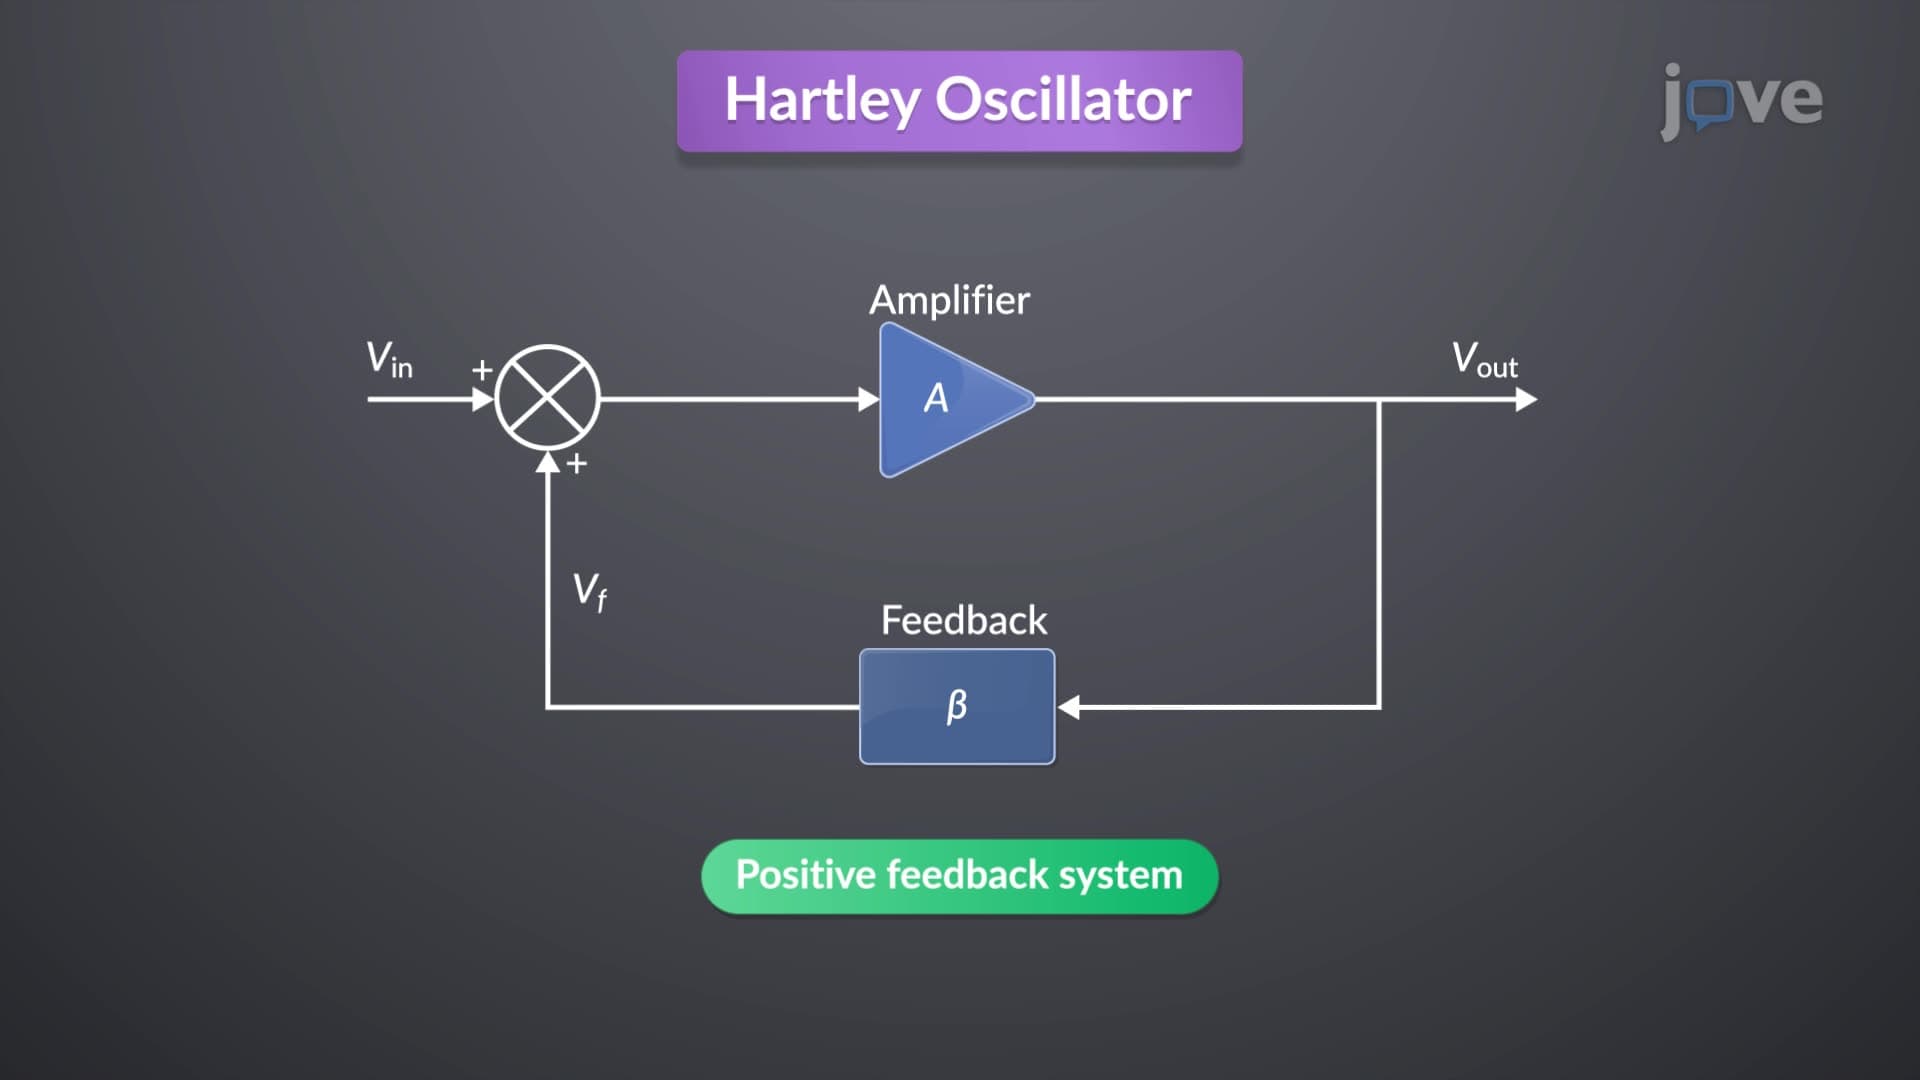
Root Loci for Positive-Feedback Systems
The construction rules for the root locus in positive feedback systems are similar to those in...
 01:19
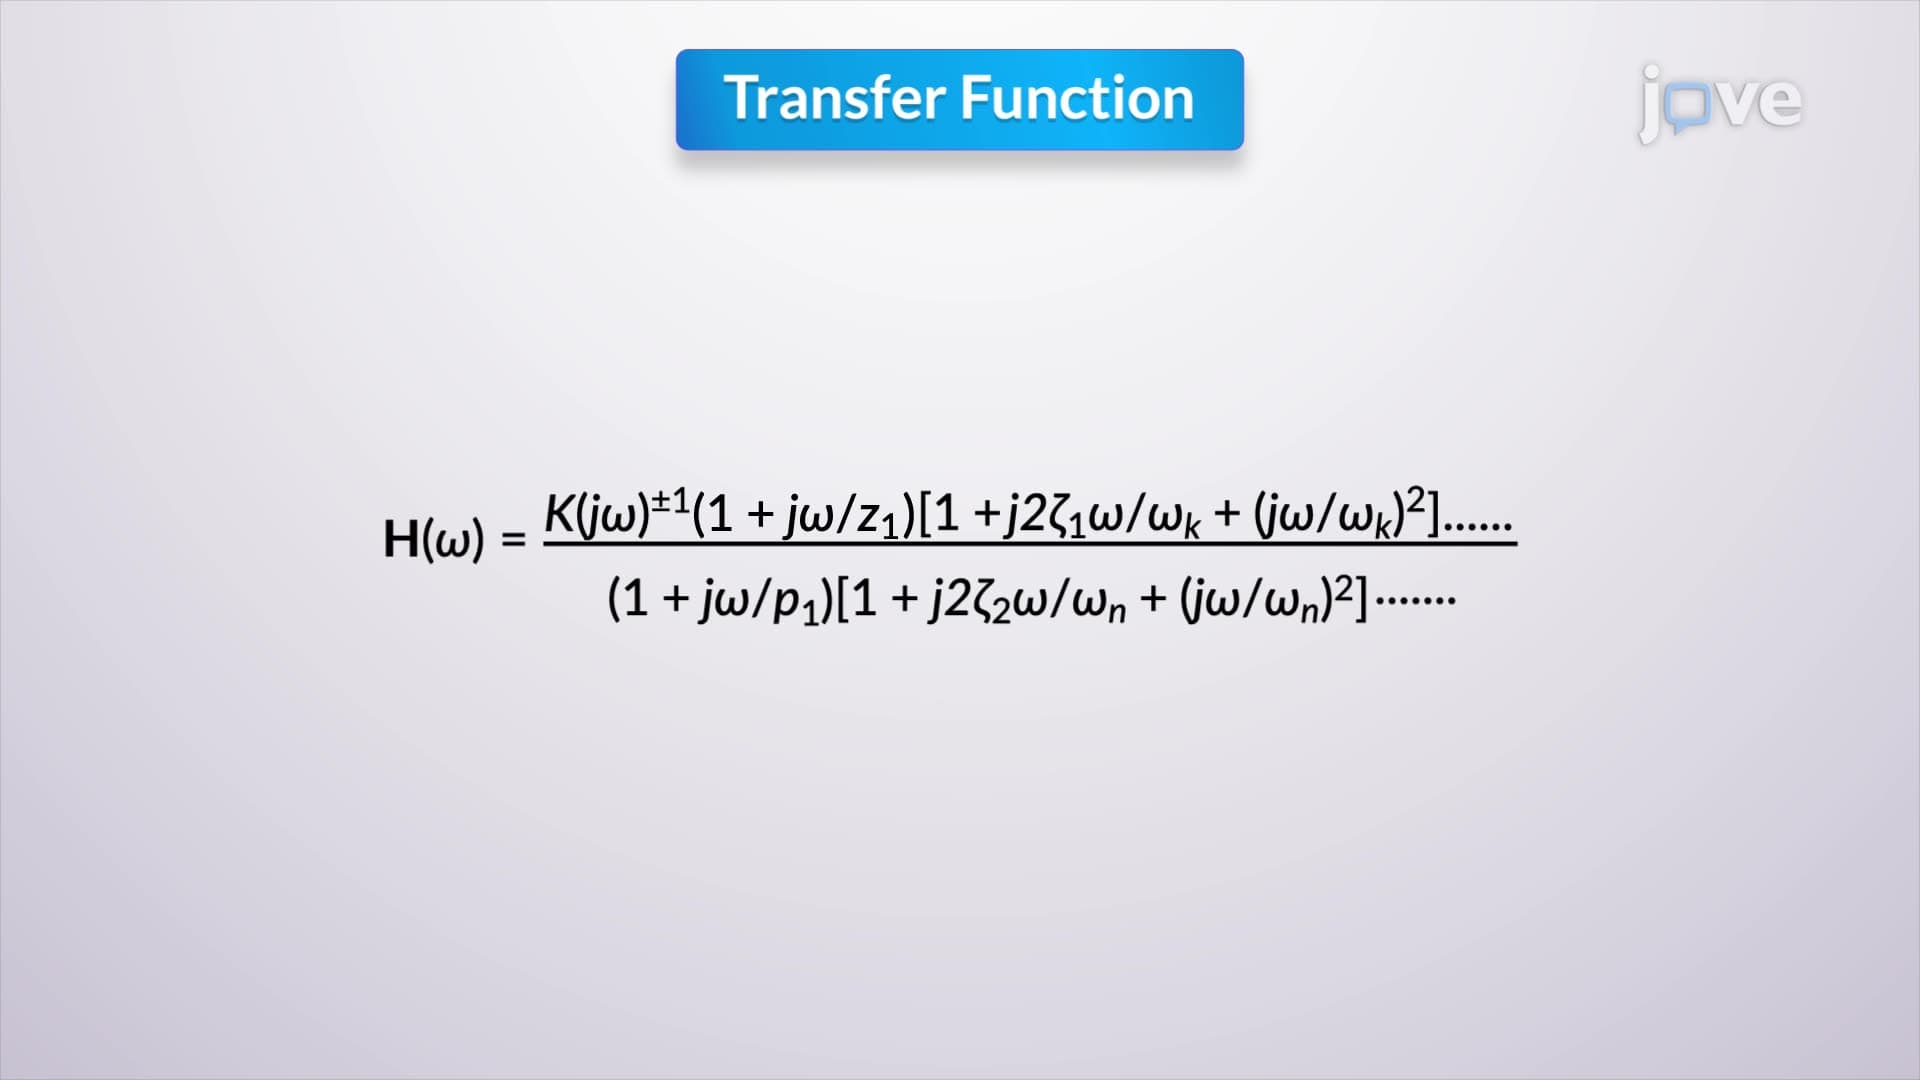
Transfer function and Bode Plots-I