Related Experiment Video
Updated: Jan 15, 2026
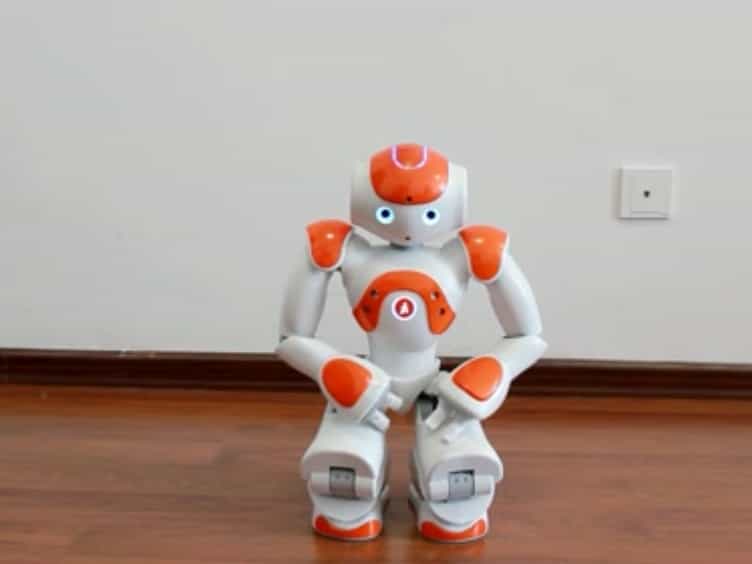

SSVEP-based Experimental Procedure for Brain-Robot Interaction with Humanoid Robots
Published on: November 24, 2015
Error-related potentials in EEG signals: feature-based detection for human-robot interaction
Alessandra Fava1, Valeria Villani2, Lorenzo Sabattini2
1Department of Sciences and Methods of Engineering, University of Modena and Reggio Emilia, 42122, Reggio Emilia, Italy. alessandra.fava@unimore.it.

Abstract:
This study explores how to improve the detection of Error-Related Potentials (ErrPs), namely brain signals generated when a person perceives an unexpected action performed by an interacting agent. ErrPs are promising for improving interactions between humans and robots because they offer a way for robots to understand the user's needs and expectations without explicit input. The proposed method aims at characterizing ErrP signals using a wide set of features extracted from electroencephalography (EEG) data, collected from subjects performing different tasks. This feature-based method results more accurate and efficient than traditional approaches, especially when applied to multiple users, or across different experimental setups. This work paves the way to feature-based ErrP detection to enhance human-robot interaction in dynamic environments.
More Related Videos
 08:26
Event-related Potentials During Target-response Tasks to Study Cognitive Processes of Upper Limb Use in Children with Unilateral Cerebral Palsy
Published on: January 11, 2016
 05:48
Author Spotlight: Investigating the Impact of Emotional Prosodies on Voice Recognition and Perception
Published on: August 9, 2024