Related Experiment Video
Updated: Jan 15, 2026

A Structured Rehabilitation Protocol for Improved Multifunctional Prosthetic Control: A Case Study
Published on: November 6, 2015
Innovative inverse kinematics algorithm for 6-DOF robotic manipulators with offset wrists
Cong Zhang1,2, Yu Cao1,2, Peng Sun3,4
1College of Mechanical Engineering, Zhejiang University of Technology, Hangzhou, 310023, China.

Abstract:
This paper presents a novel numerical algorithm for inverse kinematics (IK) in robotic arms with offset wrists to address the challenges in IK solutions caused by biased parameters. Initially, the problem is simplified by categorizing robotic arms into two standard types and applying rotation or translation transformations to the terminal link. This approach is used for a robotic arm with a biased wrist, allowing for the acquisition of joint angles that approximate the desired solution. Subsequently, the initial Hessian matrix is corrected by incorporating the Jacobian matrix and regularization terms. Furthermore, the step size of the scaled memoryless augmented Broyden-Fletcher-Goldfarb-Shanno (SMABFGS) algorithm is dynamically adjusted to avoid convergence to local optima by integrating a momentum-based gradient descent (GD) method. The joint angles are iteratively refined to facilitate the convergence of the robotic arm's end effector toward the desired pose. Finally, the algorithm's accuracy in solving discrete end-effector poses is validated through a simulation experiment of IK with randomly sampled end poses. Additionally, a trajectory-tracking experiment is conducted on a physical robotic arm with an offset wrist to demonstrate its effectiveness and real-time performance in practical robotic operations.

Related Concept Videos
 01:15
Kinematic Equations: Problem Solving
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
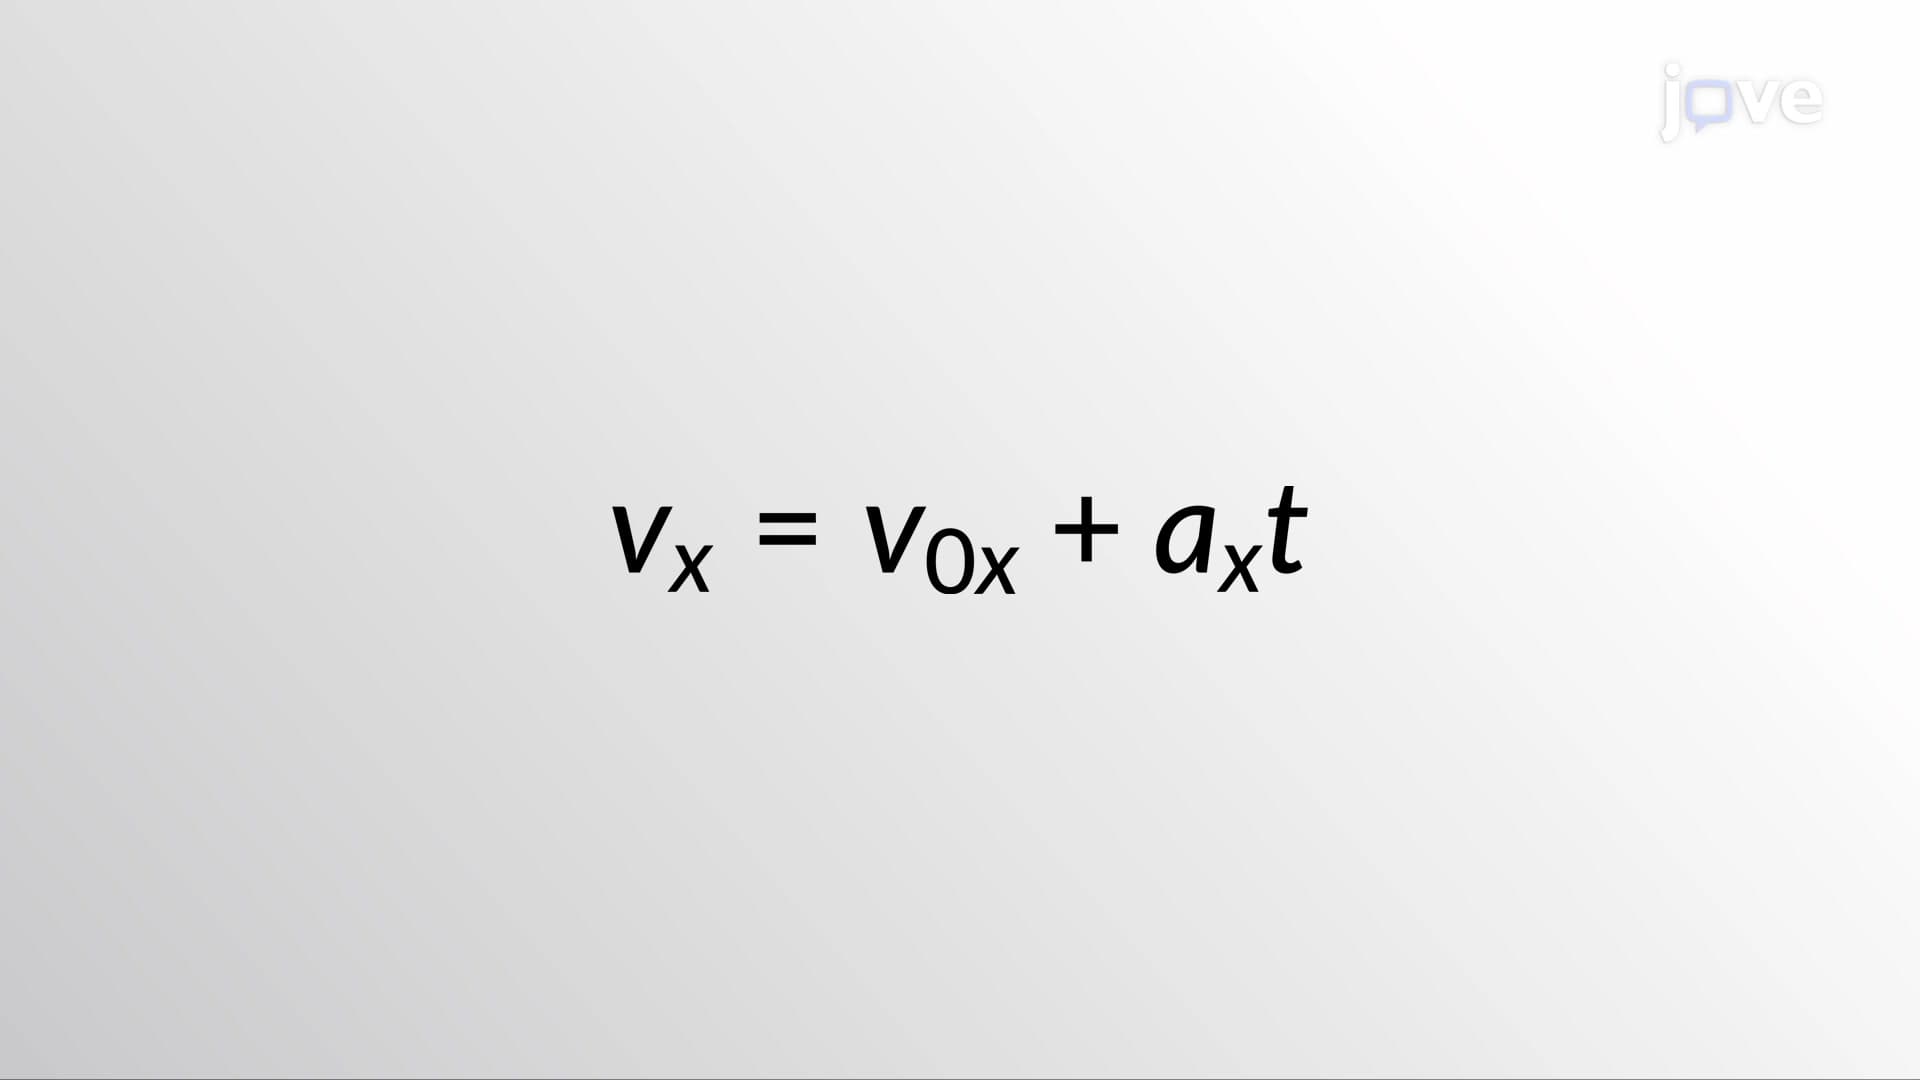 01:26
Kinematic Equations - I
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...