Related Experiment Video
Updated: Aug 7, 2026
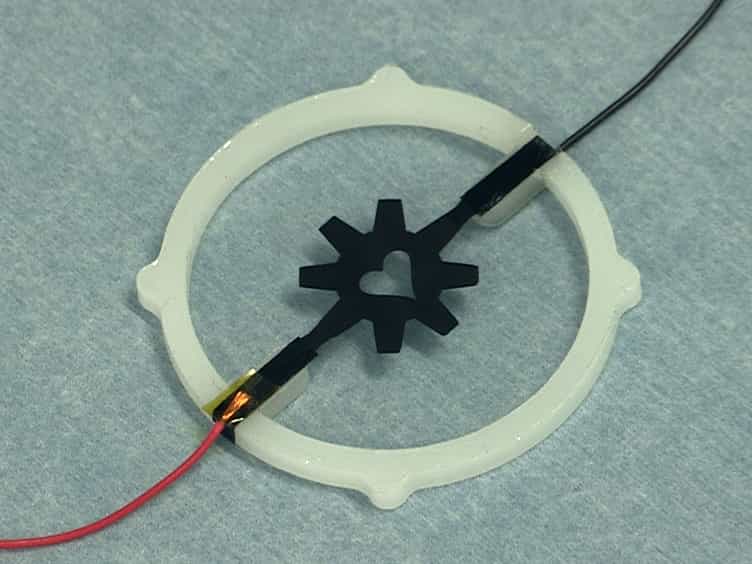

Fabrication Process of Silicone-based Dielectric Elastomer Actuators
Published on: February 1, 2016
Multi-Stimulus Soft Actuators from Aerosol Jet Printed MXene-Cellulose Composite
Brian Cole1, Yilin Zhao1, Anna Bethke2
1Department of Electrical & Computer Engineering, Duke University, Durham, North Carolina 27708, United States.

Abstract:
The evolution of next-generation flexible, stretchable, and conformal microrobotics hinges significantly on advances in fabrication methods. There is a need to enhance the scalability of actuator feature dimensions and to increase the design versatility. This study demonstrates the additive manufacturing of soft multi-stimulus thermomechanical actuators based on a composite of transition metal carbide (TMC, MXene) and cellulose nanofiber (CNF) nanomaterials using aerosol jet printing (AJP) for scalable/customizable actuation. Aqueous MXene-CNF films with tunable electrothermal and photothermal properties were printed onto polycarbonate (PC) membranes for wired and/or wireless operation, having full reversibility with induced heating below 120 °C. Printed devices as small as 5 mm2 and 2.5 mm2 yielded sharp curvatures of 0.92 cm-1 and 0.87 cm-1, respectively. By printing MXene-CNF to select regions on both sides of the substrate, complex actuation modes were realized with directional, reversible control. This work highlights the promise of AJP-fabricated MXene-CNF systems for soft robotics applications.