Related Experiment Video
Updated: Jan 12, 2026
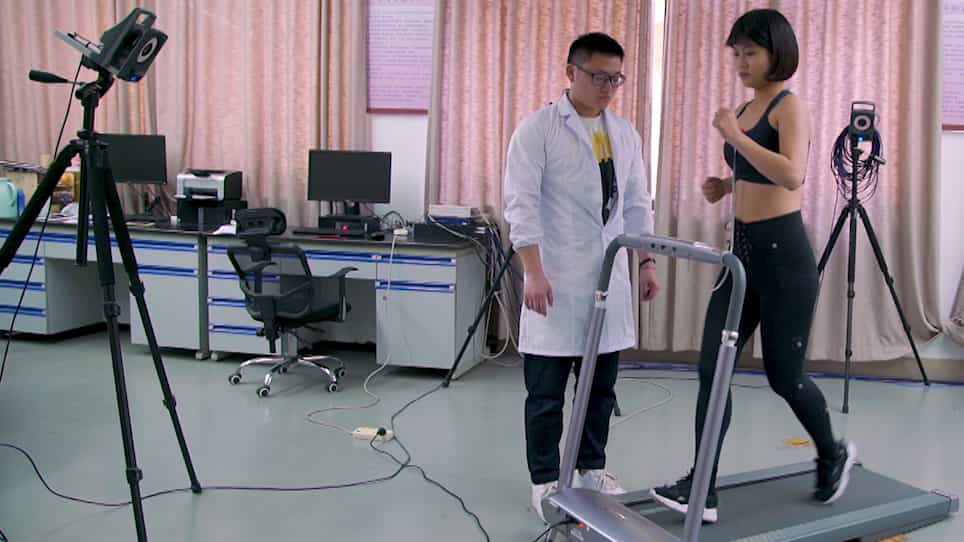

Comparative Analysis of Lower Limb Kinematics between the Initial and Terminal Phase of 5km Treadmill Running
Published on: July 17, 2020
Runners with lower dynamic stability exhibit better running economy
Carlo von Diecken1,2, Marlene Riedl3,4, Steffen Willwacher5
1Department of Engineering and Industrial Design, Magdeburg-Stendal University of Applied Sciences, 39114, Magdeburg, Germany. carlo.vondiecken@hs-offenburg.de.

Abstract:
Maintaining dynamic stability during running incurs an energetic cost that does not contribute to forward propulsion. Despite this, dynamic stability has received little attention as a potential factor influencing running economy. To understand the relationship between dynamic stability and running economy, nineteen trained runners were tested on a treadmill across three individualized speeds. Whole-body dynamic stability was quantified via a single maximum Lyapunov exponent (MLE) computed from a 21D state-space embedding, which incorporated 3D angular velocities from seven body segments (bilateral: shank, upper torso, forearm; unilateral: lower torso) and running economy was measured as cost of transport (COT) using metabolic gas-exchange data. Linear mixed-effects models were used to assess the relationship between MLE and COT as well as the effects of running speed on MLE. MLE was negatively associated with COT (p = 0.049), while running speed had no significant effect on MLE (p > 0.579). This study is the first to demonstrate that the MLE calculated from a multivariate state-space is negatively associated with COT, indicating that runners with lower dynamic stability exhibit better running economy. Further, MLE was not affected by running speed, indicating that this measure of whole-body dynamic stability can be robustly assessed at a range of running speeds. These results may hint at a previously unexplored avenue to improve running economy through alteration of dynamic stability characteristics.
More Related Videos
Related Concept Videos
 02:20
Dynamic Equilibrium
 01:28
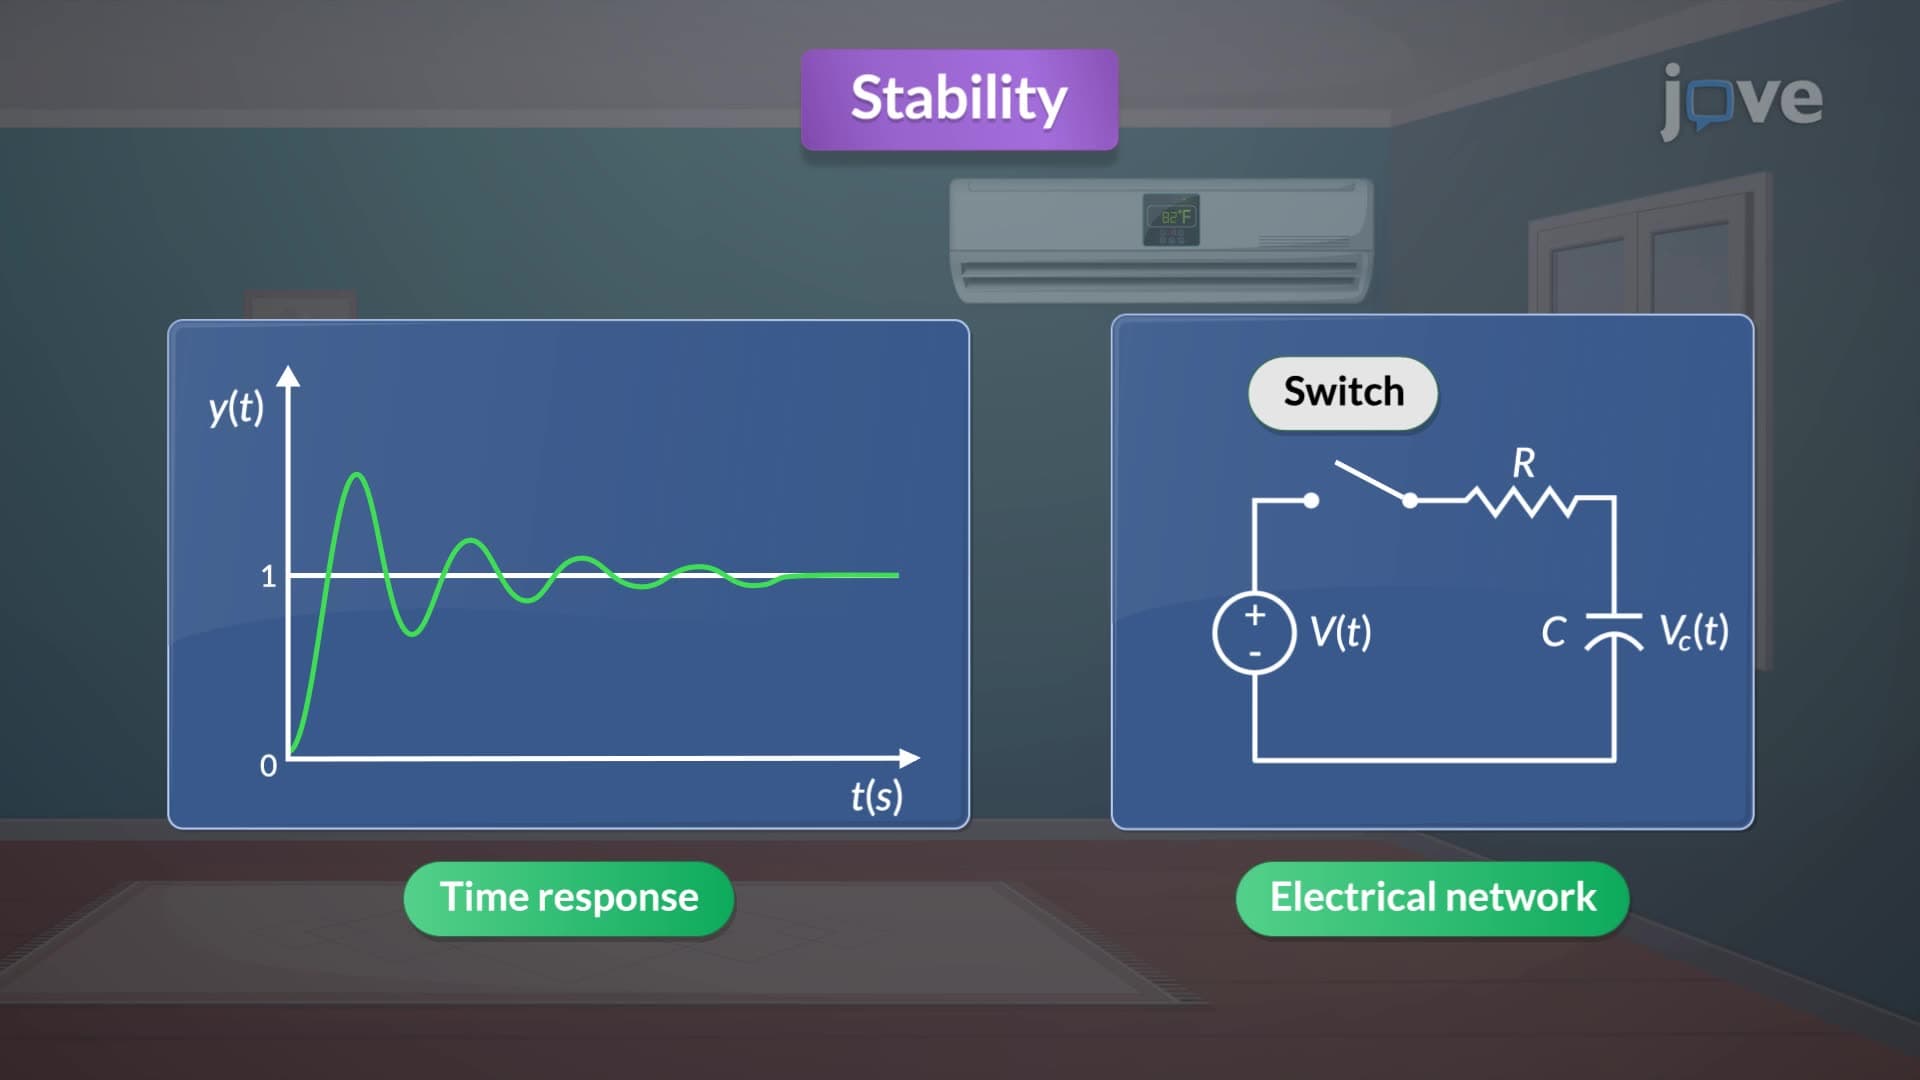
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:12
Run Charts
 01:25
Interpreting Run Charts
 01:21
Rolling Resistance
For instance, imagine a hard cylinder rolling on a comparatively soft surface. The cylinder's weight compresses the surface beneath it. As the cylinder moves, the material in front of it slows down due to...
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...