Related Experiment Video
Updated: Aug 9, 2026
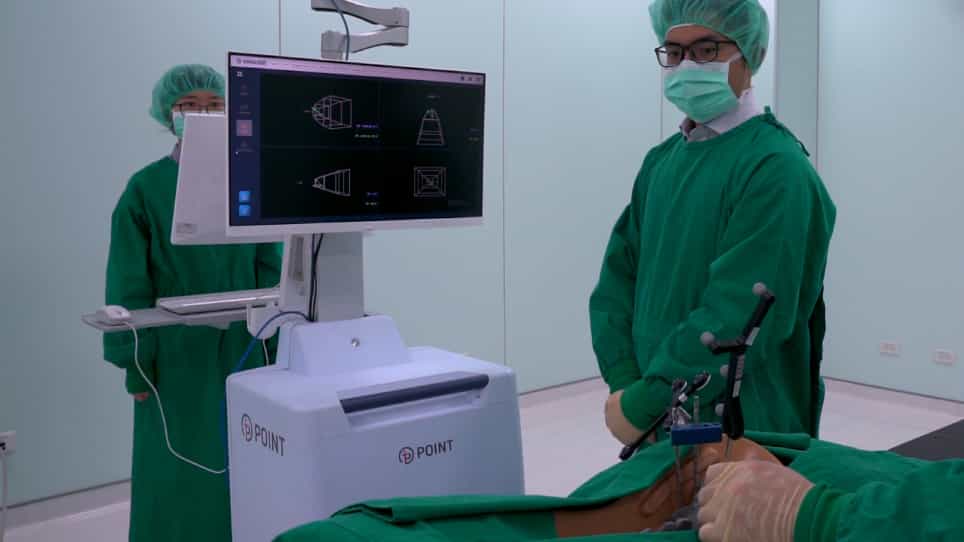
A Spine Robotic-Assisted Navigation System for Pedicle Screw Placement
Published on: May 11, 2020
Robot-Assisted Cervical Pedicle Screw Placement: Case Series and Technical Description
Hayley A Granberg1, Kareem Khalifeh2, Timothy Y Kim2
1Rocky Vista University College of Osteopathic Medicine, Parker, CO, USA.

Brief Problem:
Robot-assisted (RA) techniques with pedicle implant placement have demonstrated improved accuracy and safety in thoracolumbar surgery, but their application in the cervical spine is less described. Although multiple robotic systems are currently approved for spinal fusion procedures, most studies focus on thoracolumbar instrumentation. As a result, cervical RA procedures remain underdiscussed regarding safety and efficacy.
Innovation:
A total of 8 patients (4 women [50%]) with a mean age of 63.1 years (range 49-75), in whom 50 cervical pedicle screws were placed, were identified. Preoperative diagnoses included degenerative (n = 2), tumor (n = 2), trauma (n = 2), and deformity (n = 2). The 50 pedicle screws were distributed at C1 (8 screws), C2 (8), C3 (6), C4 (6), C5 (6), C6 (8), and C7 (8). There was 1 inferior grade B breach on a C7 screw without clinical sequelae that was repositioned for a 98% total screw accuracy.
Clinical Relevance:
RA cervical pedicle screw placement appears to be a safe and effective adjunct in complex cervical spine surgery. The proposed stepwise workflow is reproducible and adaptable and includes several specific recommendations: the use of a Mayfield Halo, intraoperative computed tomography for registration, lower drill rates per minute, and additional cannulas. Further studies need to validate these findings in larger cohorts and evaluate long-term patient outcomes.

Related Concept Videos
 02:50
Spindle Assembly
In most cells, centrosomes are the primary microtubule nucleation centers. In the centrosome-mediated pathway, the G2-prophase transition triggers centrosome maturation and increased microtubule nucleation. Progressive nucleation results in a microtubule array...
 01:19
Machines
A free-body diagram of the...
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
 01:30
Machines: Problem Solving II
 01:16
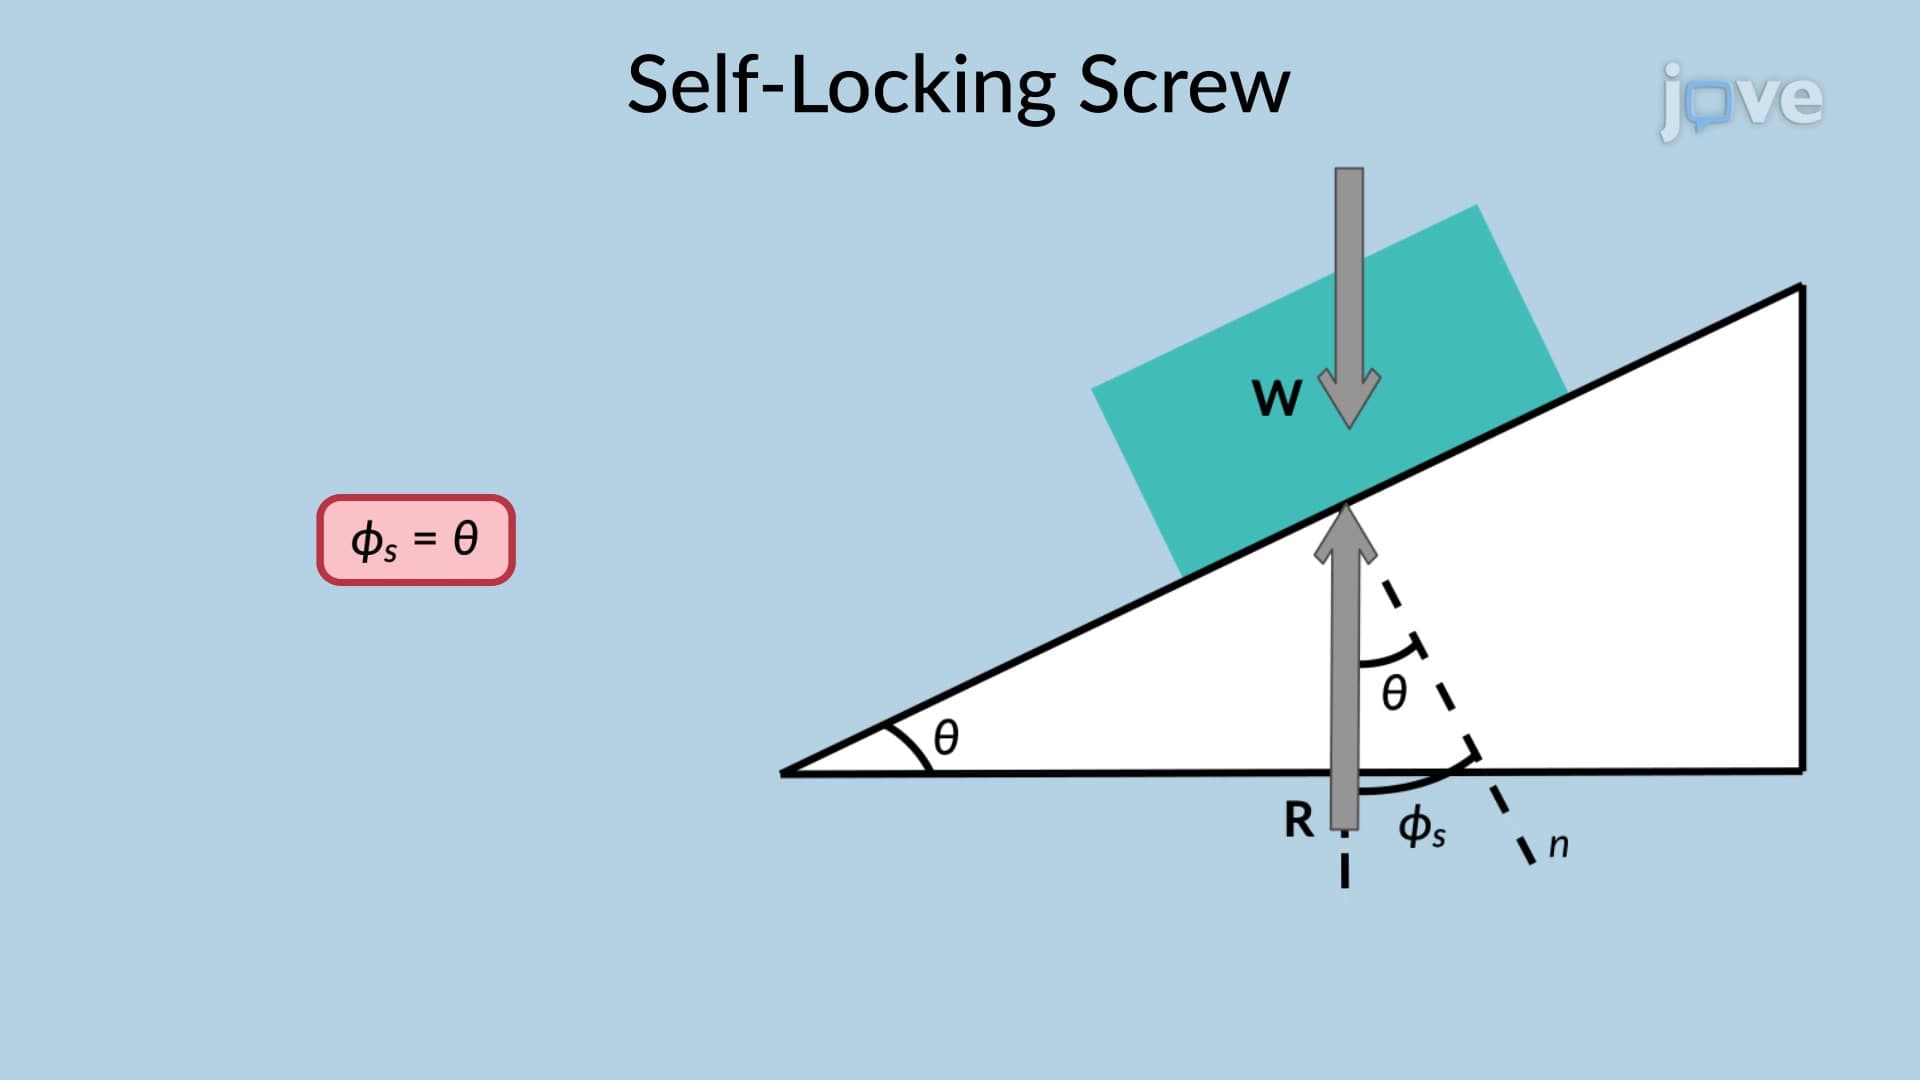
Self-Locking Screw
A square-threaded screw jack carrying a load is considered self-locking if the screw retains its position even after the moment applied to it is removed.
 01:21
Screw: Problem Solving
To evaluate the...