Related Experiment Video
Updated: Jan 12, 2026


Closed-loop Neuro-robotic Experiments to Test Computational Properties of Neuronal Networks
Published on: March 2, 2015
Inverse Reinforcement Learning for Disturbed Networked Nonlinear Systems With Data Dropouts

Abstract:
This article develops inverse reinforcement learning (IRL) control algorithms for nonlinear networked control systems (NCSs) to mimic trajectories of a target system governed by an unknown optimal cost function, despite the presence of random data dropouts and external disturbances. Data dropouts occur during: 1) reception of target trajectory data by the controller; 2) reception of state feedback data by the controller; and 3) reception of control input data by the actuator. By organically integrating $H_{\infty } $ control to account for disturbances and dropout-induced uncertainty, a model-based IRL algorithm is first developed. Building on this, a neural-network-based data-driven IRL algorithm is developed to infer the cost function and optimal control policy using available data while reducing dependence on system models. The proposed methods enable effective trajectory imitation under partial model knowledge, data dropouts, and disturbances, as demonstrated through simulation studies.
Related Concept Videos
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:10
Propagation of Uncertainty from Systematic Error
 00:59
Propagation of Uncertainty from Random Error
 01:13
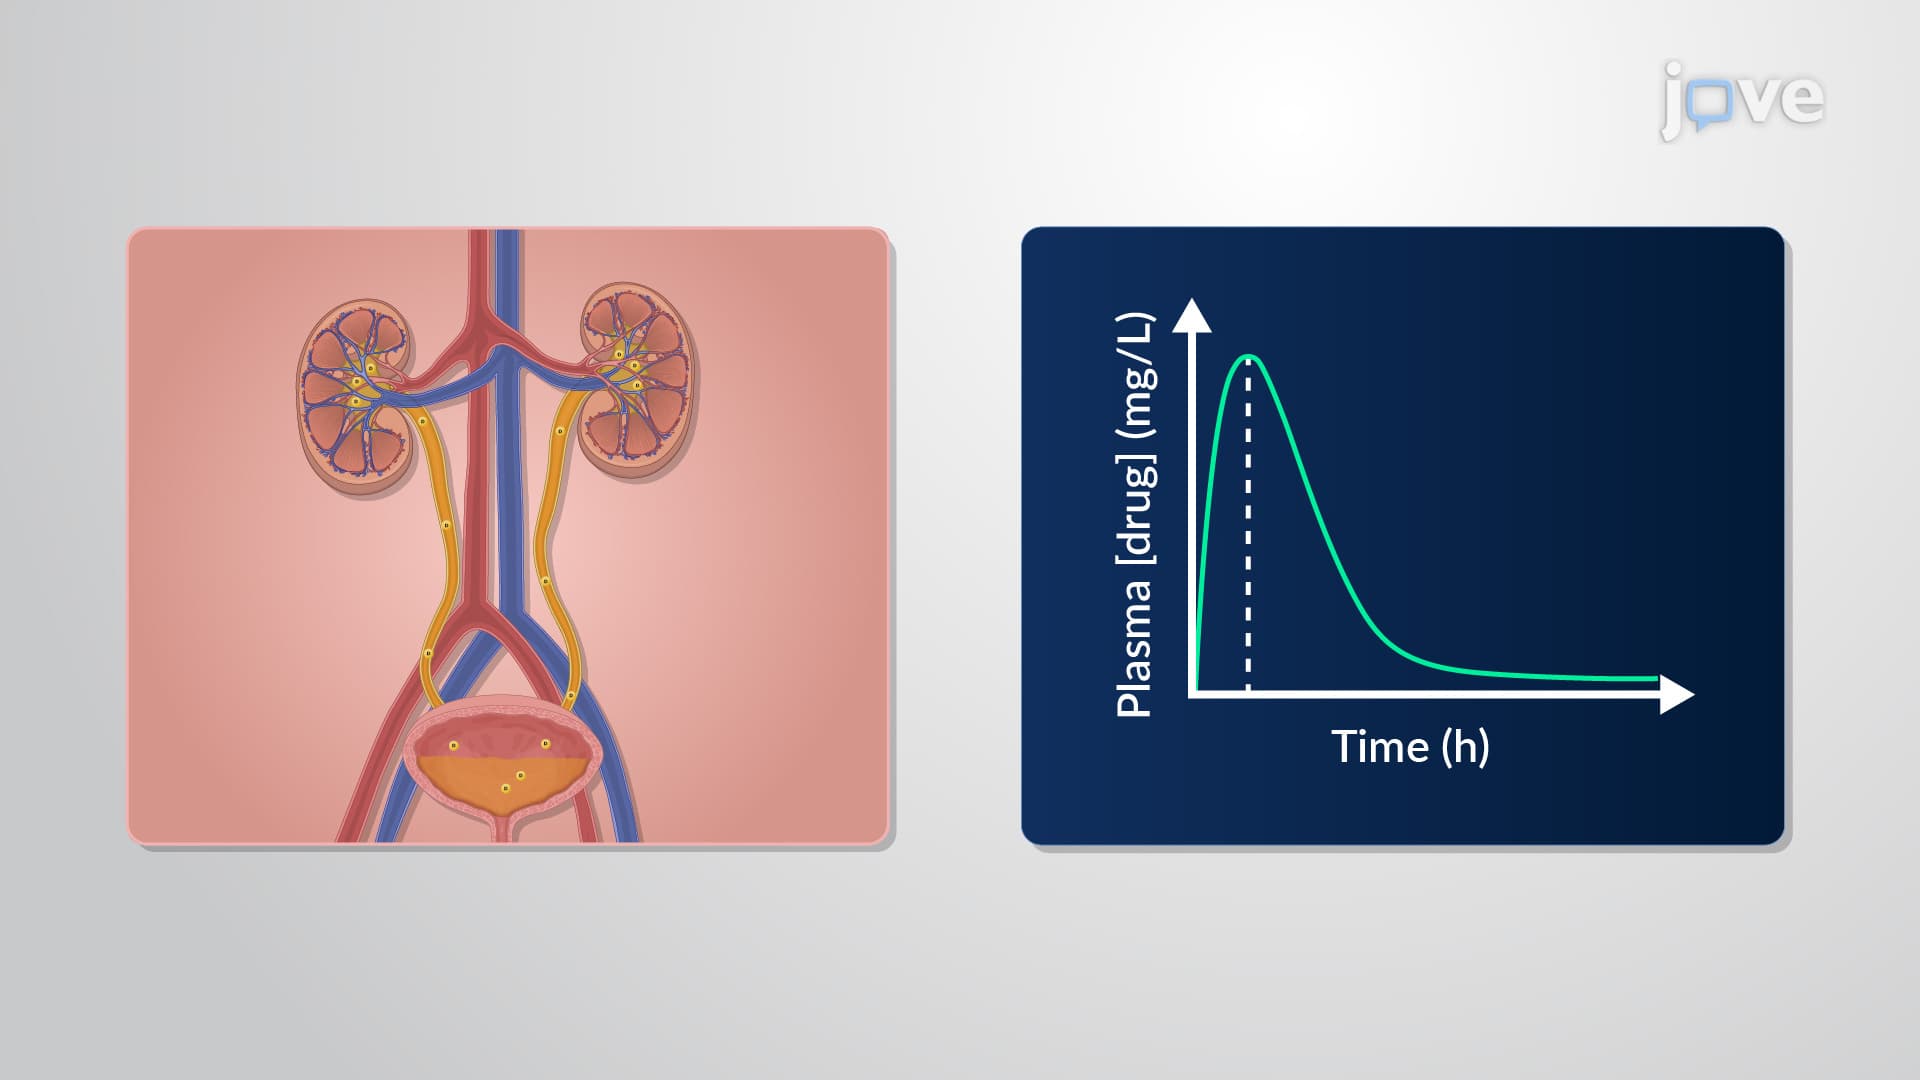
Parameters Affecting Nonlinear Elimination: Zero-Order Input, First-Order Absorption and Two-Compartment Model
When a drug is administered through a constant intravenous infusion and eliminated via nonlinear pharmacokinetics, it follows zero-order input. For example, oral drugs undergo first-order absorption upon administration and are eliminated through nonlinear pharmacokinetics.
In the case of subcutaneously administered drugs,...
 01:14
Avoidance Learning and Learned Helplessness
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...