Related Experiment Video
Updated: Jan 10, 2026

WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Zero-sum game-based dynamic self-triggered sliding mode control for unknown nonlinear systems with asymmetric input
Ning Xu1, Tengda Wang2, Ben Niu3
1College of Information Science and Technology, Bohai University, Jinzhou 121013, Liaoning, China.

Abstract:
This article addresses a zero-sum game-based dynamic self-triggered sliding mode control problem for continuous-time unknown nonlinear systems with asymmetric input constraints using the adaptive dynamic programming method. First, a novel nonquadratic value function incorporating sliding mode variables is formulated to systematically convert the H∞ constrained control problem into an unconstrained zero-sum game problem. A data-driven method employing recurrent neural networks subsequently reconstructs the unknown system dynamics. Building upon this foundation, a novel dynamic self-triggered mechanism is designed, where triggering instants are adaptively determined through predictive computation involving current state information and time-decaying dynamic thresholds. To resolve the derived Hamilton-Jacobi-Isaacs equation, a streamlined single-critic neural architecture is proposed, eliminating the conventional actor-network dependency while preserving approximation accuracy. Through rigorous Lyapunov-based analysis, all closed-loop signals are theoretically guaranteed to achieve uniform ultimate boundedness. The designed control strategy is conclusively validated through comprehensive simulation studies implemented on a robotic arm system and a microgrid system, demonstrating excellent dynamic response characteristics.
More Related Videos
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 08:35
Interactive and Visualized Online Experimentation System for Engineering Education and Research
Published on: November 24, 2021
Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:18
Second Order systems II
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:20
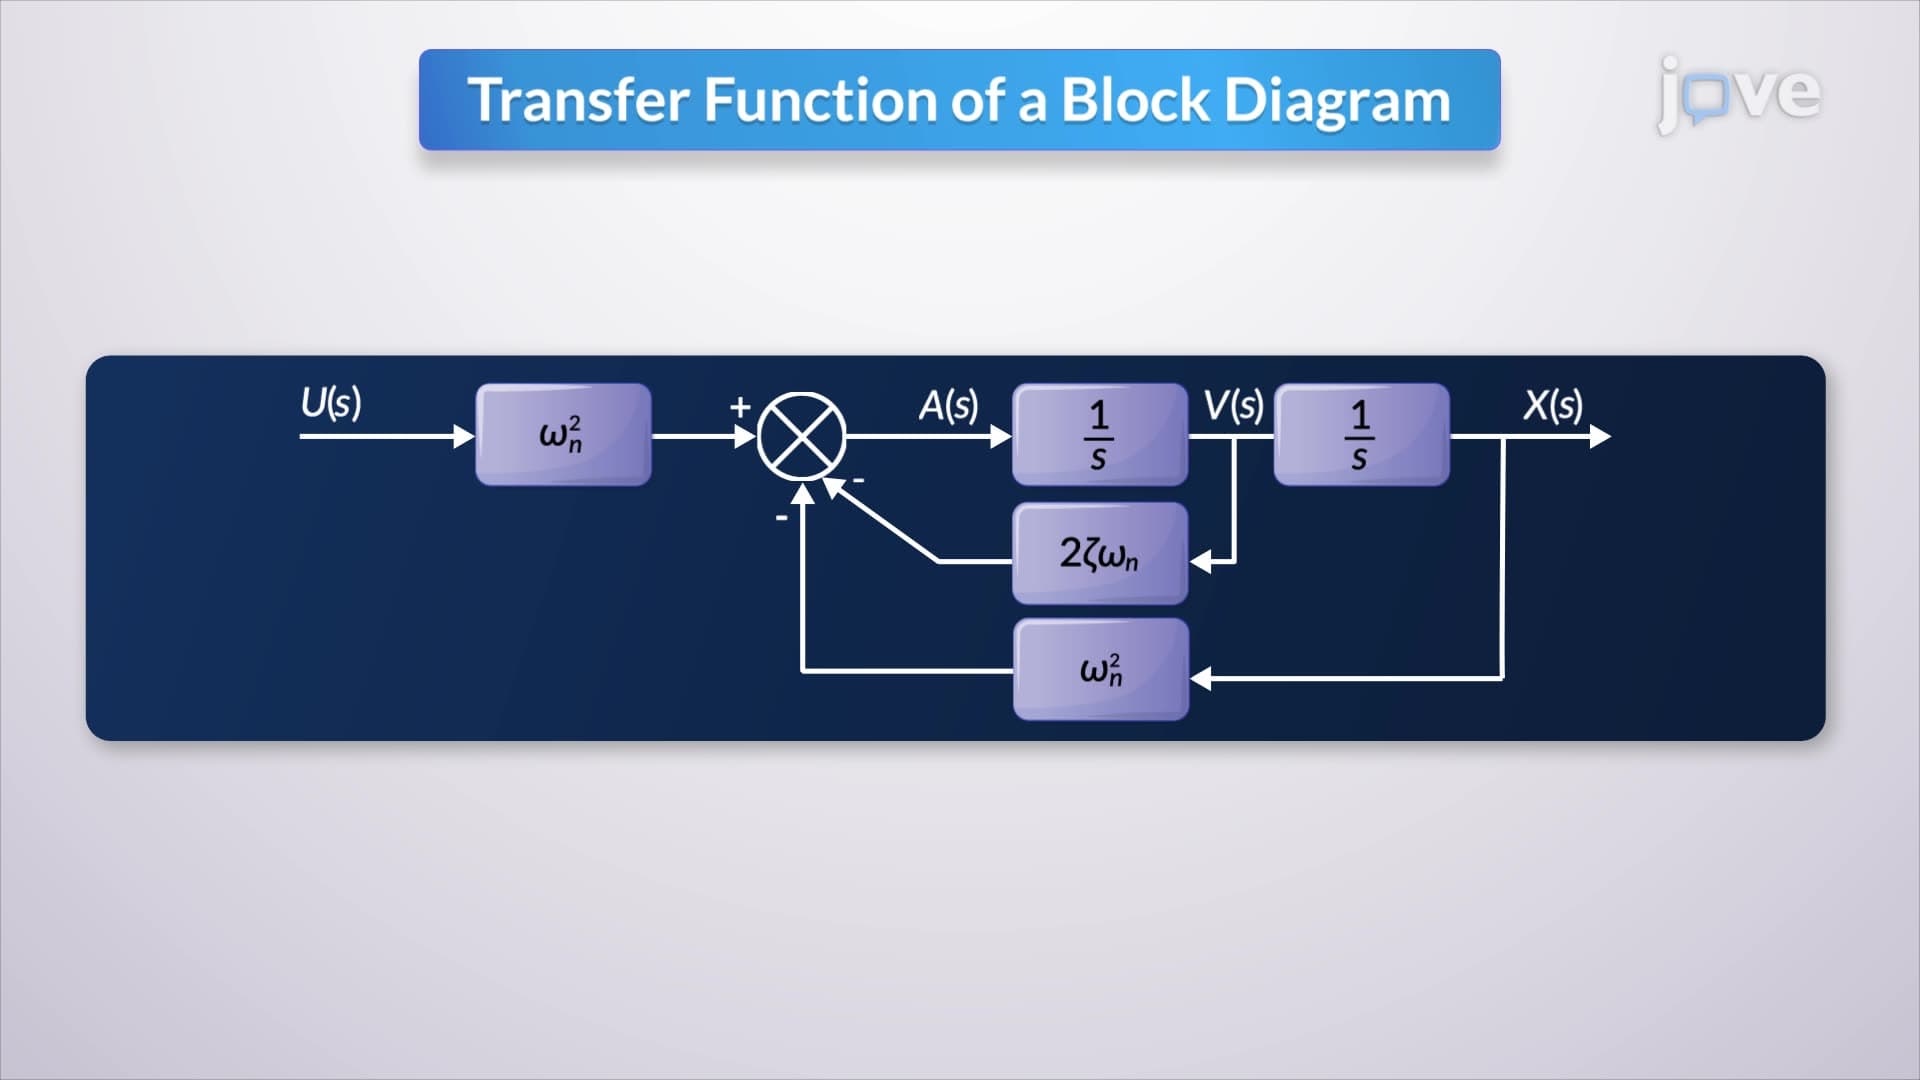
Relation between Mathematical Equations and Block Diagrams
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...