Related Experiment Video
Updated: May 3, 2026
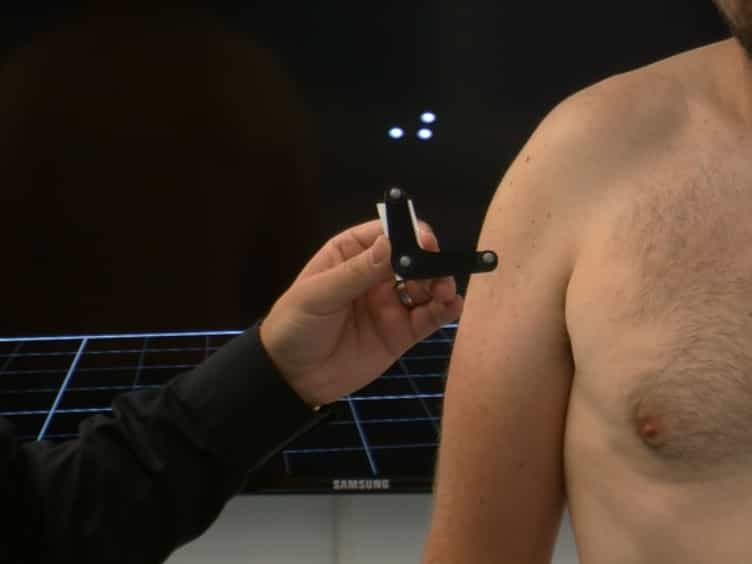

Measurement of Dynamic Scapular Kinematics Using an Acromion Marker Cluster to Minimize Skin Movement Artifact
Published on: February 10, 2015
The method of reflection-based marker detection and identification to ensure accurate AGV docking
Piotr Biernacki1, Adam Ziebinski2
1Institute of Theoretical and Applied Informatics, Polish Academy of Sciences, 44-100, Gliwice, Poland. pbiernacki@iitis.pl.

Abstract:
Accurate localization is essential for Automated Guided Vehicles (AGVs) to ensure reliable motion planning and precise execution of docking tasks. A key challenge lies in robust environmental perception for industrial applications. This paper introduces a novel reflection-based marker detection and identification method that relies solely on two-dimensional Light Detection and Ranging (2D LiDAR) technology. The proposed docking method and 2D marker design enable the AGV to accurately estimate the marker's distance and orientation, reliably identify it, and determine the docking point. Experimental validation on a heavy industrial AGV demonstrated that the docking method achieves accuracy of up to 1 cm in position and below 0.05 degree in YAW orientation. As a result, the AGV achieved docking precision at an assembly station with a standard deviation below 2 cm in X and Y axes and YAW orientation below 1.8 degree.

Related Concept Videos
 03:31
Labeling DNA Probes
Radioisotopes, fluorophores, or small molecule binding partners like biotin or digoxigenin, are the most widely used reporter tags for labeling DNA probes. These labels can be attached to the probe DNA molecule via...
 01:19
Gas Chromatography: Types of Detectors-II